74 Principles of Flight Vehicle Design
Introduction
The design of an aerospace flight vehicle,[1] like that of any complex engineering system, is often misconstrued as the direct application of analytical methods to identify an objectively “best” configuration that satisfies a prescribed set of requirements. In practice, analysis and design serve fundamentally different purposes. Analysis seeks to predict the behavior of a given configuration under stated assumptions. Design, by contrast, is concerned with determining what configuration should be built in the first place, subject to the laws of physics, customer requirements and operational objectives, technological feasibility, and imposed constraints. As illustrated in Figure 1, an aerospace flight vehicle is a tightly coupled system whose subsystems must function coherently and efficiently across the entire flight envelope, with sufficient margins to accommodate uncertainty, environmental variability, and off-design operation.

Many of the most consequential decisions in the design of a new flight vehicle are made at a stage when its shape is not yet fully defined, design models and computational tools may only be tentatively validated, and performance estimates remain provisional. At this stage, a successful design outcome depends less on the predictive fidelity of analytical models than on sound engineering judgment and experience, particularly in identifying the dominant physical effects, understanding cross-disciplinary coupling among subsystems, and recognizing those decisions that may irreversibly constrain the remaining configuration space. In some cases, the design risk may be sufficiently high to justify building and flying a sub-scale demonstrator, as shown in Figure 2, which can provide flight data to support final design decisions and mitigate risk as the program progresses toward a full-scale flight vehicle.

This chapter of the eBook is not intended to prescribe a step-by-step “how-to” methodology for designing an aircraft or spacecraft. Rather, it describes the general stages of the design process and illustrates principles that experienced engineers may use to guide vehicle-level design decisions in an inherently unforgiving field, where failures can be catastrophic. These principles govern a concept’s feasibility, robustness, and risk long before detailed sizing, optimization, or high-fidelity analysis becomes possible. Accordingly, the emphasis is on the design process itself, rather than merely restating the methods and equations developed in earlier chapters of the eBook. It is also important to understand why some design errors can be corrected while others irreversibly compromise a design’s success. Nevertheless, reintroducing some essential equations helps solidify aspects of the design process. An awareness of historical “lessons learned” is also essential for engineers because, despite the fidelity of modern analytical and computational tools, every new generation remains susceptible to repeating past mistakes and is not infallible.
Today, many engineers in the established aerospace industry will participate in only one major aircraft or spacecraft development program throughout their careers. In contrast, earlier generations in the 1950s through the 1980s often experienced multiple full program cycles, from preliminary design through certification and entry into service. Reduced exposure to complete design lifecycles can make it more difficult to develop experience and intuition about how early design decisions propagate into cost growth, performance shortfalls, certification challenges, and operational limitations that may not emerge for many years. As development timelines lengthen and new programs become increasingly complex, expensive, and risk-averse, the opportunity to learn from repeated large-scale design iterations has diminished, making the systematic transmission of design lessons and failure modes increasingly important.
The rapid growth of the eVTOL (Figure 3) and small-UAS sectors may partly offset the loss of large-scale program experience by allowing new engineers to participate in several complete design cycles over relatively short development timelines. Repeated exposure to configuration decisions, certification constraints, flight-test results, failures, and operational limitations can accelerate the development of sound engineering judgment. However, many companies do not recognize that rapid prototyping and repeated flight testing, by themselves, do not produce this judgment. The benefit is realized only when programs use disciplined systems engineering, realistic performance and weight margins, independent technical review, and rigorous verification and validation. When development is driven mainly by software-centric tuning, compressed schedules, optimistic projections, and ad hoc flight testing, fundamental design errors and misconceptions merely recur at a faster rate. With effective oversight by experienced engineers, eVTOL and UAS programs can provide valuable training for developing engineers. Without such oversight, they may instead reinforce poor engineering practices.

Learning Objectives
- Distinguish between design and analysis, and explain why analytical capability alone does not guarantee a viable aerospace system.
- Explain why early design decisions most strongly constrain feasibility, rather than remaining parameters that can be freely adjusted later in the design process.
- Identify common design failure modes, including weight growth, overly optimistic assumptions about system integration, and reliance on late-stage corrective fixes.
- Describe the coupling among major subsystems (aerodynamics, propulsion, structures, controls, etc.) that limits independent optimization.
- Recognize the fundamental design constraints imposed on aircraft and spacecraft by their operational roles and propulsion systems.
- Explain why the development of aerospace systems incurs inherently high costs and risks.
Defining the Design Process
The design of an aerospace flight vehicle begins not with equations or analytical tools, but with choices, and very difficult ones in most cases. These choices must be made when the vehicle’s configuration and geometry are still incomplete, predicted aerodynamic and structural loads are only approximate, and most analytical models can be applied only in their most basic forms to obtain rapid results. Therefore, the design process is more of an exercise in decision-making under conditions of substantial uncertainty, particularly for novel flight-vehicle configurations that may depart from historical precedent.
The use of analytical models remains essential in the early stages of design, provided they are employed expeditiously to reveal dominant first-order effects and to delineate physically feasible regions of the configuration space. Premature reliance on high-fidelity, time-consuming methods such as the finite element method (FEM) or computational fluid dynamics (CFD) is usually counterproductive, as early design concepts lack the geometric and structural definition needed to yield meaningful results. Even generating a grid for a new concept can take many weeks. Although the visual output of such tools can carry a strong “wow factor,” as shown in Figure 4, applying them too early in the design process often fosters a false sense of confidence in their viability. The growing availability of AI-driven tools has further reinforced this problem by encouraging the misconception that almost any conceptual configuration one can dream of can be made to fly and perform its intended mission.[2]

The most effective approach to flight vehicle design begins by identifying a small set of key parameters that govern the vehicle’s ability to meet most or all of the requirements. For airplanes, parameters such as gross weight, payload weight, wing loading, power-to-weight or thrust-to-weight ratio, and aerodynamic drag determine baseline performance levels long before details of airfoil shape, control laws, or structural layout become relevant. For spacecraft, analogous roles are played by total mass, propellant mass fraction, and thermal constraints. Therefore, progress toward a viable conceptual design depends on recognizing which parameters fundamentally dominate the design process, while resisting the temptation to prematurely incorporate secondary effects.
Use of AI tools
The growing use of automated tools, including AI-based analysis and optimization, does not change the fundamental nature of flight-vehicle design. Such tools can accelerate calculations and efficiently explore large parameter spaces, but they do not determine feasibility, nor do they absolve designers of responsibility for their decisions. Used uncritically, they can amplify poor assumptions, conceal violated constraints, and lend unwarranted authority to flawed results. As with any powerful tool, AI is valuable only when guided by sound physical judgment, experience, and disciplined design reasoning.
Analytical Models
An equally important aspect of the design process is a good understanding of the validity and limitations of the analytical methods and models being employed. All models rest on assumptions that inevitably limit their applicability. In practice, models are not discarded simply because their assumptions are only partially satisfied. Instead, they are applied judiciously and with an appreciation of their limitations. As illustrated by the design hierarchy in Figure 5, the early stages of design are dominated by requirements, a small set of primary design parameters, and first-order modeling and feasibility assessments.

At these levels, many simplified models are remarkably robust and provide reliable guidance when used for their intended purpose. For example, lifting-line wing theory, vortex lattice methods, or panel methods yield excellent results for many subsonic aircraft configurations when evaluating overall aerodynamic loading, induced drag, trim, and stability trends. High-fidelity tools such as CFD are introduced later in the process, once configuration-level decisions and detailed variables have already been established, and are used primarily to validate and refine earlier choices rather than to determine the basic configuration. At this stage, the design team’s central responsibility is to draw on their experience and use sound engineering judgment. Failure to do so, whether through inexperience or misuse of models, almost invariably leads to poor design outcomes and compromised flight capabilities.
Flight Simulation
Today, flight simulators (Figure 6) belong on the modeling side of the design process, not on the verification side. The increasing availability of high-fidelity flight simulators and real-time, pilot-in-the-loop environments has also changed how design decisions are explored, particularly for handling qualities, piloting workload, and operational procedures. In the conceptual and preliminary design phases, simulators are most valuable for revealing qualitative sensitivities, control-authority issues, mode coupling, and human-machine interaction effects that are difficult to infer from static analyses alone.

However, like any other modeling capability, a flight simulator reflects the assumptions embedded in its aerodynamic, propulsion, sensor, and control representations. Consequently, simulators should be used to inform design judgments and expose potential problems early, not to verify performance or compensate for unresolved configuration-level deficiencies. Their primary role in design is exploratory and diagnostic rather than predictive.
Optimization
Optimization plays a limited and often misunderstood role in the aerospace design process. In its formal mathematical sense, an optimization problem may be posed as the minimization (or maximization) of an objective function  , defined over a vector of design variables
 . Gradients or sensitivities
 are then used to guide the design toward an improved configuration. In practice, such methods are most effective once a viable configuration has already been identified. Mathematical optimization and sensitivity analysis can assist in refining geometric parameters, improving performance metrics, or converging on a design within prescribed constraints. They can also help balance competing requirements such as range, payload, field performance, and cruise efficiency. But caution is always required, and experience is needed to use them effectively and to understand their limitations.
Robust design emphasizes solutions that remain acceptable under uncertainties present in requirements, operating conditions, modeling assumptions, manufacturing variability, and in-service degradation. In contrast to point optimization, which seeks the best performance for a narrowly defined set of assumptions, a robust design deliberately accepts a small reduction in peak performance in exchange for reduced sensitivity to uncertain inputs and unforeseeable changes; see Figure 7. In aerospace systems, this situation typically manifests as modest performance margins, conservative structural and thermal limits, and configurations that accommodate weight growth, subsystem variation, and mission evolution without requiring a fundamental redesign.

Experience shows that the distinction between a robust design and a point design is not merely philosophical. The most successful flight vehicles are rarely true point designs because actual weights, atmospheric conditions, manufacturing tolerances, component performance, and mission requirements inevitably differ from their nominal values. A design optimized too narrowly may lose much of its advantage when these conditions change and may have little capacity to accommodate later increases in payload, equipment, structural weight, or mission scope. For most aerospace systems, a modest sacrifice in peak efficiency is worthwhile when it provides lower sensitivity to uncertainty, adequate margins, and useful growth capability. True point-design goals are appropriate only when requirements are narrow, stable, and tightly constrained, which is the exception rather than the norm.
System Integration
In practice, many of the most difficult design problems arise not within individual disciplines per se, but at their interfaces. Examples include propulsion-airframe integration, structural-aerodynamic coupling and aeroelasticity, thermal-power interactions in spacecraft and electric aircraft, and control-structure coupling in highly integrated flight control systems. Single-discipline analyses will rarely, if ever, reveal these interactions, which unfortunately often emerge only later in the design process when the subsystems are integrated and evaluated together.
From a design-process perspective, effective system integration depends as much on organizational and information flow as on technical modeling. Clear interface definitions, configuration control, and continuous cross-disciplinary communication are essential to prevent local optimizations from degrading the vehicle’s overall performance. Experience shows that the late discovery of integration problems is a primary driver of cost overruns, schedule delays, and redesigns in aerospace programs. Project managers typically recognize these issues and must be very proactive in keeping the design team on task.
Rutan Voyager as a point design
The Rutan Voyager, which completed the first nonstop, non-refueled circumnavigation of the Earth in 1986, provides a rare and instructive example of a true point design. The airplane was optimized almost exclusively to satisfy a single, tightly constrained requirement, which was to maximize range for a specific mission profile. To achieve this objective, nearly every aspect of the design was pushed to the extremes. The fuel fraction exceeded 70% of the takeoff weight, leaving minimal structural and operational margin. Structural strength, flutter margins, landing loads, and handling qualities were reduced to the absolute minimum acceptable levels required to complete the flight. There was no tolerance for weight growth, mission variation, or prolonged service use.  In this sense, Voyager is precisely the exceptional case in which a point design is appropriate because the requirements were extremely narrow, the mission was unique, and no robustness or multi-mission capability was required. By contrast, most operational aircraft are deliberately designed away from such optima to preserve margins for future growth, accommodate uncertainty, ensure acceptable performance across a wide operating envelope, and anticipate future mission or operational requirements.
Design Team
The design process for an aerospace system is inherently multidisciplinary and is carried out by a team rather than by individuals. While organizational structures vary by company and program type, most design teams are organized around core technical disciplines, with coordination through a Chief Designer or Chief Engineer, who is responsible for the vehicle’s overall technical coherence, as shown in Figure 8. This role requires extensive experience and strong technical authority, including making difficult decisions, resolving cross-discipline conflicts, and ensuring early design commitments remain physically consistent as the design evolves. While informed by expert input from each discipline, the Chief Engineer or Chief Designer is accountable for all aspects of the vehicle and ultimately bears responsibility for its success or failure.

Supporting this role are the discipline leads, typically responsible for aerodynamics, structures, aeroelasticity, propulsion, stability and controls, acoustics, avionics, systems and integration, and weights. Each discipline develops its own analyses and offers recommendations within its area of expertise, but the Chief Engineer will ensure that no discipline operates independently of the others. Many of the most consequential design decisions will inevitably arise at the interfaces between disciplines, where competing constraints must be identified, evaluated, and reconciled at the upper levels of the design process. Often, these decisions are difficult and may involve some degree of technical conflict among the discipline leads. Another role of the Chief Engineer is to bring stability and closure to these conflicts, thereby advancing the design.
During the conceptual design phase, the team is intentionally kept small, ideally composed of experienced individuals who can cover multiple disciplines, and communication is more informal, rapid, and iterative. As the design progresses through the preliminary and final stages, the team grows in size and becomes increasingly specialized, interfaces are formalized, and responsibility is progressively delegated. As the design freedom progressively diminishes, clarity of authority, accountability, and decision-making become increasingly important.
A central design principle is that authority does not derive solely from analysis. The various discipline experts will provide essential technical insight, but the final decisions must be made by the design leads and the Chief Engineer, who use their knowledge and experience to weigh competing effects, uncertainties, risks, and available margins. Successful professional teams will encourage technical disagreement early, when changes remain feasible, and enforce convergence later, when commitments must be honored and subsequent changes will become difficult and costly, if not impossible.
In educational design projects, such as the AIAA Design, Build, and Fly (DBF) competition, teams are often small, and individuals may assume multiple roles. Such projects allow students to experience the tightly coupled nature of aerospace systems, to confront real trade-offs across disciplines, and to appreciate that effective design requires judgment and integration, not merely technical excellence in the classroom. Sustained success for a DBF team depends on continuity of expertise from year to year, which does not happen automatically and must be maintained through deliberate mentoring and institutional memory.

Design Requirements
The process of designing a flight vehicle never begins with a blank sheet of paper, but with a set of requirements. These requirements are, more often than not, formalized in a Request for Proposals (RFP) issued by a potential customer, which defines the mission, operating environment, performance targets, schedule, and cost constraints for the proposed flight vehicle. The RFP specifies what the flight vehicle is intended to do, but not how it should be designed. Nonetheless, the RFP usually defines the boundaries of the feasible configuration space before any specific configuration is proposed.
The requirements for the flight vehicle may be issued simultaneously by various customers, most commonly civil operators such as airlines and military organizations. Civil requirements typically emphasize range and payload, operational economics, reliability, regulatory compliance, and life-cycle cost. Military requirements, by contrast, are driven by mission effectiveness and may prioritize flight speed, maneuverability, survivability, and multi-mission capability over efficiency or cost. Despite these differences, both civil and military requirements are subject to the same physical and engineering constraints, although system-integration constraints may, and generally do, differ.
Operational flight requirements are inherently coupled; i.e., the required range, takeoff and landing distances, climb performance, ceiling, survivability, cost, and regulatory compliance cannot be specified independently, and improvements in one area almost always incur penalties elsewhere; such is the nature of the aircraft design. Early design is concerned less with satisfying individual requirements than with judging their mutual compatibility and relative priority. Therefore, conceptual design serves as a feasibility filter between stated requirements and physical reality. Early RFPs may include optimistic or internally inconsistent targets, and the engineering team must resolve these conflicts before making major commitments. In civil aviation, this assessment must explicitly account for the need to meet FAA and/or EASA airworthiness certification requirements, which impose rigorous, binding constraints on the configuration, design margins, and system architecture that cannot be accommodated retroactively.
Once interpreted, the requirements must then focus the space of feasible design choices and will guide early commitments. Characteristics such as configuration, general layout, weight, wing loading, and propulsion system are natural responses to requirements that are constrained by physics. Throughout the design process, the requirements serve as a reference, not a checklist. Successful designs meet them with margin and robustness. Designs that satisfy these constraints only marginally rarely survive, either during proposal evaluation or in subsequent development. Configurations that enter flight testing with little or no performance, weight, or margin reserve are seldom competitive and carry a disproportionate risk of late redesign, schedule slip, or outright program failure.
Early Design Commitments
While the term aircraft encompasses a wide range of flight vehicles, it is useful to focus on airplanes when illustrating the design process. The design of an airplane does not proceed through the gradual refinement of a fully flexible initial configuration. Instead, it advances through a limited number of early iterations that rapidly define and constrain the feasible configuration space. Once certain design commitments are made, they may be difficult or impossible to reverse without substantially revising or abandoning the concept. Understanding these commitments and their consequences is essential to successful design.
A defining feature of the early design stages is that important decisions must be made while geometric details remain in flux and analytical predictions are still tentative. The design team cannot rely on precise performance predictions at this stage, but must instead use physical scaling, prior experience, and an understanding of the dominant effects. Design failures at this stage are often caused less by small errors in analytical predictions than by incorrect configuration-level assumptions or early sizing commitments. Poor choices propagate throughout the airplane as a system and may not be recoverable through later refinement or optimization. The emphasis must be on configuration feasibility and robustness rather than on meeting exact performance levels per se.
Several considerations dominate airplane design in its earliest stages, including weight, wing loading, power-to-weight or thrust-to-weight ratio, drag, cost, and manufacturability. Of these considerations, weight is especially important because weight growth produces the reinforcing feedback loops shown in Figure 9. The key parameters are:
- Weight, which governs aerodynamic, structural, and propulsion requirements, is a primary source of design failure when systematically underestimated or allowed to grow without adequate control.
- Wing loading, which strongly influences stall speed, takeoff and landing performance, maneuverability, gust response, and the balance between low- and high-speed aerodynamic performance.
- Power-to-weight or thrust-to-weight ratio, which establishes the energy margins available for climb, takeoff, and maneuvering and determines whether the airplane can operate successfully under off-design conditions.
- Drag, which sets the continuous energy cost of flight and reflects the cumulative aerodynamic consequences of the selected configuration and its detailed execution.
- Cost, which must be treated as a first-order design variable and evaluated over the complete life cycle of the airplane.
- Manufacturability, which enters the design through part count, geometric complexity, material selection, tolerances, tooling, assembly processes, and production rate.

These considerations recur repeatedly when prior airplane designs are examined across different eras, missions, and technologies. An increase in empty weight can require additional structural capacity, greater lift, more propulsion power or thrust, and additional fuel. These changes can then lead to further weight increases, creating positive feedback loops that amplify relatively small errors in early sizing. The resulting growth in empty weight generally increases acquisition and operating costs, making weight control a dominant determinant of both technical and economic feasibility.
Despite major advances in airframe materials, propulsion systems, manufacturing methods, and avionics, successful airplanes continue to occupy a restricted region of the feasible configuration space, often referred to as the design box, as shown in Figure 10. This convergence reflects enduring physical constraints and operational requirements that become apparent early in the design process, well before detailed aerodynamic shaping or structural optimization begins. In Figure 9, cost appears as a consequence of the physical weight-growth loop rather than as one of its internal physical variables. In the broader design process, however, cost also depends on production rate, tooling, material selection, system complexity, certification burden, maintenance requirements, and life-cycle support.
There is often a compelling reason to remain within established configuration families because change pursued primarily for novelty generally carries additional risk. Selecting a configuration outside the established design box because it is visually distinctive or expected to attract attention can expose a program to substantial technical and commercial uncertainty. A departure from conventional practice is justified only when it provides a clear and defensible aerodynamic, structural, operational, manufacturing, or economic advantage.

Lessons Learned #1 – Piper PA-32R Lance
The Piper Lance provides a useful example of a configuration change whose expected benefits did not outweigh its operational disadvantages. Piper adopted a T-tail for the Lance II and Turbo Lance II, placing the stabilator outside much of the propeller slipstream and wing downwash. The arrangement was intended to reduce noise, vibration, and trim changes with power and flap settings while also distinguishing the revised airplanes from their predecessors. However, reduced stabilator effectiveness at low airspeeds led to less favorable takeoff and landing characteristics, and Piper returned to a conventional tail on subsequent Saratoga models. The example illustrates that a visibly distinctive configuration must still provide a clear and durable aerodynamic, operational, or economic advantage.
Lesson learned: A departure from an established configuration should be adopted only when its measurable technical or operational benefits clearly outweigh the penalties and risks it introduces.
More generally, configurations selected primarily for product differentiation tend to be less robust when their novelty is not supported by a significant technical benefit. Established manufacturers usually remain within configuration families proven for the intended mission, such as conventional monoplane wings, familiar propulsion arrangements, and conventional empennage configurations. Viable alternatives may exist outside these families, but they generally introduce greater uncertainty in aerodynamic behavior, structural design, manufacturing, certification, and operation.
Established manufacturers must also account for certification precedent, production infrastructure, supply-chain maturity, maintenance practices, and long-term supportability. These considerations strongly favor incremental evolution over disruptive configuration changes. Departures from proven arrangements may require new certification interpretations, manufacturing processes, tooling, maintenance procedures, and operational assumptions, introducing schedule and cost risks that may be disproportionate to the prospective performance gains. Remaining inside the design box is rarely evidence of limited imagination, but a rational response to physical, regulatory, manufacturing, operational, and commercial constraints.
Weights
Predicting the weight of a new aircraft design is inherently difficult, and historical aircraft programs show that unanticipated weight growth is one of the most common causes of design failure or performance shortfall. Early conceptual designs almost universally underestimate the empty weight because the weights of structural, systems, and installation components may be unknown or incompletely accounted for. As the design matures, component weights can be refined, but additional requirements accumulate, and weight growth propagates through drag estimates and propulsion sizing. The result is often a cascade of performance penalties, including reduced payload and/or range and diminished operational flexibility.
A useful way to reason about the weight of an airplane during early design is to decompose the gross takeoff weight into its primary weight components, i.e.,
(1) 
Equivalently, in nondimensional form in terms of weight fractions, then
(2) 
This basic decomposition highlights the fundamental trade-offs among structural and systems design, payload capability, and mission fuel. In the case of an electric aircraft, the fuel fraction is replaced by an energy-storage weight fraction, usually dominated by the battery weight, recognizing that a battery’s specific energy, i.e., stored energy per unit mass, is significantly lower than that of a fossil fuel such as AVGAS or JET-A. Unlike fuel, however, the battery mass is not consumed during the mission, so the aircraft’s weight remains nearly constant during flight and contributes to lower range.
In design, the empty-weight fraction,  , is both the least certain and the most susceptible to unanticipated growth. For this reason, it is often useful to further decompose the empty weight into major subcomponents, i.e.,
(3) 
so that, in fractional form, then
(4) 
This second-level decomposition helps localize uncertainty and identify the design elements that are most likely to drive weight growth during the development phase.
In conceptual design, the empty-weight fraction is commonly estimated using empirical correlations based on historical data from similar airplane configurations, as shown in Figure 11. The data used to establish these correlations are compiled from publicly available manufacturer specifications and certification documents, i.e., maximum takeoff weight and published empty or operating empty weight, for representative production aircraft. Therefore, the resulting correlations represent statistical trends in realized aircraft designs rather than physics-based structural models and are intended solely to provide rapid, internally consistent weight closure during early conceptual studies.

Figure 11 shows that, within a given class of airplanes, the relationship between empty weight and gross takeoff weight can be accurately represented by a simple power-law regression. For practical use in sizing loops and constraint studies, this regression is most conveniently expressed in fractional form as the empty-weight fraction, i.e.,
(5) 
where  ,
 , and
 are empirical regression constants. For the numerical values listed in the table below,
 must be expressed in pounds, has units of
 , and has units of lb. The coefficients must be converted or refitted if another system of units is used. The exponent
 reflects the sublinear scaling of structural and systems weight with size. The term
 accounts for additional fixed or weakly scaling weight contributions that may be configuration- or mission-specific. For many civil aircraft, the term is small and may be neglected in early studies.
| Aircraft class | () |
|
(lb) |
Typical |
|---|---|---|---|---|
| Light general aviation airplanes | 0.90–1.05 | 0.95–0.98 | 0–300 | 0.55–0.65 |
| Transport airplanes (turboprop and turbofan) | 0.85–0.95 | 0.92–0.96 | 0–2,000 | 0.45–0.55 |
| Uncrewed aircraft (UAVs) | 0.95–1.10 | 0.96–1.00 | 0–100 | 0.60–0.75 |
These correlations must only be applied within the class of aircraft from which they were derived. As the design matures, initial estimates must be replaced by actual component weights and/or other detailed weight models. History shows that airplane designs that projected unusually low empty-weight fractions early in development, compared with historical trends, rarely survive to production without substantial redesign or significant performance compromises. Such optimistic projections may arise from overly ambitious material assumptions, overly optimistic integration expectations, or marketing-driven claims made before the engineering design has fully matured.
Lessons Learned #2 – Overly optimistic performance projections of the MD-11
The McDonnell Douglas MD-11 is frequently cited as an example of the consequences of overly optimistic performance projections. Aggressive claims regarding range, payload, and fuel burn were not realized in operational service, forcing costly aerodynamic modifications, weight-reduction programs, and engine upgrades after certification. These unplanned changes increased the development cost, delayed market entry, and weakened the aircraft’s commercial competitiveness. In extreme cases like this, misjudgments can undermine an entire product line and directly contribute to the financial distress or failure of an airframe manufacturer. McDonnell Douglas’s subsequent financial struggles prevented further development of the MD-11 before the company was acquired by Boeing in 1997. The unified company decided to terminate the MD-11 program after fulfilling outstanding orders. Nevertheless, the MD-11 ultimately achieved a long and successful service life, especially as a freighter, demonstrating that technical shortfalls do not necessarily preclude operational longevity.
Wing Loading
Wing loading is defined as the aircraft weight divided by the reference wing planform area, i.e.,
(6) 
Historical data based on maximum gross weight show that wing-loading values have remained remarkably consistent within established aircraft classes. Light general aviation airplanes and trainers, commercial transports, fighters, and gliders or sailplanes each occupy distinct and persistent ranges despite substantial differences in size, materials, propulsion, and technology. Representative values are summarized in Table 1. This consistency reflects the central role of wing loading in determining stall speed, takeoff and landing distances, maneuver and gust response, and low-speed controllability.
| Aircraft class | Typical wing loading,  |
Typical design implications |
|---|---|---|
| Gliders and sailplanes | 5–12 lb/ft 25–60 kg/m |
Low stall speed, efficient soaring, and strong sensitivity to gusts and atmospheric turbulence |
| Light GA airplanes and trainers | 10–25 lb/ft 50–120 kg/m |
Moderate stall speeds, short-field capability, benign handling, and acceptable gust response |
| Fighters | 50–120 lb/ft 245–585 kg/m |
High flight speeds and compact wings, with greater takeoff, landing, and maneuvering demands |
| Commercial transport airplanes | 90–150 lb/ft 440–730 kg/m |
Efficient high-speed cruise, with high-lift systems required to control takeoff and landing speeds |
The ranges overlap because wing loading alone does not determine airplane performance. Airfoil characteristics, high-lift systems, available thrust or power, aspect ratio, structural limits, and mission requirements also influence the final design. Nevertheless, the persistence of these ranges shows that each aircraft class occupies a relatively narrow design region governed by its operational requirements.
Caution is needed when applying historical design trends to drones. The rapid proliferation of drones has made the term drone a very broad descriptor rather than a single aircraft class. It now encompasses many configurations with fundamentally different physics and constraints, including multirotors, fixed-wing UAVs, VTOL hybrids, ducted-fan vehicles, and other unconventional concepts, operating across a wide range of Reynolds numbers, payload fractions, endurance requirements, and mission regimes. Consequently, historical data may be limited, uneven, or strongly biased toward particular applications. They may not collapse into universal design trends unless the vehicle class and operational context are first defined. Historical comparisons can still be useful, but only when used within well-defined categories.
One significant aspect of wing loading is evident at the stall condition. Using the condition that lift equals weight, i.e.,  , then
(7) 
where  is the true stall airspeed,
 is the air density in which the airplane is flying, and
 is the maximum wing lift coefficient. It follows directly that
(8) 
Therefore, a higher wing loading directly leads to a higher stall speed and (often) degraded low-speed flight performance.
High-lift devices and/or alternative airfoil selection or wing design may shift these limits by increasing the value of , but they do not eliminate the underlying choice of wing loading. Aircraft intended for short-runway operation often adopt relatively low wing loading or powerful high-lift systems to control takeoff and landing speeds. Carrier aircraft may retain comparatively high wing loading, with their low-speed requirements addressed through high-lift systems, propulsion capability, approach-control characteristics, catapult assistance, and arrested recovery. Aircraft optimized for high-speed cruise or dash performance also tend to operate at higher wing loading, with corresponding low-speed penalties.
Wing loading also influences an aircraft’s response to atmospheric gusts. In the linearized small-disturbance approximation, a vertical gust of velocity  produces an incremental change in the angle of attack of
(9) 
which is valid for small disturbances under the quasi-steady approximation, where  is the airspeed. The corresponding incremental lift is
(10) 
where  is the lift-curve slope of the wing, and the resulting incremental vertical acceleration is
(11) 
This expression shows explicitly that, for a given gust velocity and flight speed, the incremental vertical acceleration varies inversely with the wing loading, . A higher wing loading reduces gust-induced accelerations and improves ride quality (i.e., the sensitivity of the airplane’s response to gusts and turbulence), at the cost of a higher stall speed and degraded low-speed and runway-length performance.
Power-to-Weight & Thrust-to-Weight Ratios
Propulsion capability in preliminary aircraft design is characterized by the thrust-to-weight and power-to-weight ratios, which measure available propulsion relative to the aircraft’s weight. The thrust-to-weight ratio is defined as
(12) 
and is the appropriate metric for jet-powered aircraft. For propeller-driven and electric aircraft, it is often more convenient in constraint analysis to use the power-to-weight ratio, i.e.,
(13) 
These quantities normalize the installed propulsion capability by aircraft weight, but they do not, by themselves, provide the excess-thrust or excess-power margin. The corresponding margins depend on the propulsion available relative to the aerodynamic requirement, i.e.,  for excess thrust and
 for excess power. In airplane constraint analysis,
 is best referred to as the power-to-weight ratio. However, in helicopter and rotorcraft practice, the term power loading is commonly used for the inverse quantity,
 , or equivalently
 in hover, with units such as lb hp
 , N kW, or kg kW.
In steady, level, unaccelerated flight, the required thrust must equal the drag, i.e.,  . The useful propulsive power required is
(14) 
For a propeller-driven airplane, the corresponding shaft power required is
(15) 
where  is the propulsive efficiency.
These relationships define only the minimum propulsion needed to maintain level flight. The achievable climb rate, acceleration capability, runway lengths, service ceiling, and maneuver margin are determined by the values of  or relative to these minimum requirements. Because the aerodynamic drag depends on the aircraft’s weight, wing loading, and aerodynamic efficiency, propulsion sizing is indirectly coupled to the aircraft’s aerodynamic and geometric design.
Historical data show that both thrust-to-weight and power-to-weight ratios cluster strongly by aircraft class and mission role. For propeller-driven airplanes, as shown in Figure 12, a clear separation is observed between single-engine general aviation airplanes and higher-performance twin-engine and commercial airplanes such as turboprop airliners. Higher wing loading values are generally accompanied by higher installed power per unit weight to preserve take-off, climb, and obstacle-clearance performance, leading to a systematic upward and rightward shift toward higher wing loadings and higher power-to-weight ratios.
 versus wing loading for propeller-driven airplanes, illustrating the separation between single- and twin-engine aircraft.
For jet airplanes, the data shown in Figure 13 indicate that airliners occupy a relatively narrow band of thrust-to-weight ratio over a tight range of wing loading. This clustering reflects the dominant influence of balanced field length and multi-segment climb requirements, which are broadly similar across most transport aircraft types and successive generations. Military fighter aircraft, by contrast, lie in a distinctly higher thrust-to-weight region and exhibit substantially greater scatter. In this case, their sizing is driven primarily by specific mission requirements for acceleration, climb, sustained maneuvering, and excess power, rather than by take-off and certification constraints. Survivability requirements, including battle-damage tolerance or ballistic protection where mission-appropriate, can also become important design constraints for some military aircraft, increasing empty weight and limiting performance capabilities.
 versus wing loading for jet airplanes, with a distinction between airliners and military fighters.
An aircraft with excessive drag or weight must consume a larger fraction of its available thrust or power merely to sustain steady flight, thereby leaving little margin to achieve other aspects of performance. Increasing the propulsion capability to compensate introduces penalties in engine and installation weight, cooling requirements, structural weight, fuel flow, and installation drag. These penalties tend to increase the overall power required, with corresponding impacts on cost and operational efficiency.
Conversely, an aircraft with lower drag and an appropriately selected wing loading will require less thrust or power to satisfy steady-state flight requirements. It can meet its mission objectives with smaller propulsion margins. For this reason, thrust-to-weight and power-to-weight ratios should be viewed primarily as outcomes of clear aerodynamic and weight-control decisions, rather than as variables to be arbitrarily increased to recover performance that may have been lost earlier in the design process.
Constraint Analysis
The foregoing concepts can be formalized through a constraint analysis, which converts performance requirements into bounds on allowable design choices. Requirements such as stall speed, climb rate, cruise speed, maximum speed, maneuver capability, takeoff distance, and landing distance are expressed as minimum thrust-to-weight ratio or minimum power-to-weight ratio as functions of wing loading and the applicable flight conditions. Plotting these constraints together identifies the combinations of wing loading and propulsion capability that are physically feasible, allowing simultaneous assessment of propulsion sizing and aerodynamic design early in the design process.
In a typical constraint diagram, such as the example shown in Figure 14, wing loading is plotted on the abscissa and either the power-to-weight ratio or the thrust-to-weight ratio is plotted on the ordinate. Each performance requirement appears as a line or curve on this plot. For a given wing loading, each constraint indicates the minimum propulsion capability required to satisfy that requirement. The region of the diagram that lies on the acceptable side of all curves simultaneously represents the feasible configuration space. A practical design point is normally selected within this feasible region with appropriate margins from the limiting constraints. When is used as the ordinate, lower values correspond to less installed power per unit weight. Therefore, the desirable design point generally satisfies all requirements with adequate margin while avoiding unnecessary installed power and excessive wing loading.

Steady, Level-Flight Constraint
The – constraint diagram is straightforward in principle, but its importance is frequently underestimated. The primary relationship is the steady, level-flight power requirement, which establishes the baseline installed power required to sustain flight at a specified design airspeed. For steady, level flight, the useful propulsive power required is  , so the corresponding shaft power is
 . The drag may be written in the usual parabolic form as
(16) 
where  is the aspect ratio of the wing and
 is Oswald’s efficiency factor for the airplane as a whole. Dividing this expression by weight and expressing the result in terms of wing loading gives
(17) 
This relationship is a U-shaped function of wing loading, although only part of the curve is usually required on a constraint diagram. It defines the minimum power-to-weight ratio required for sustained, level flight at the selected airspeed and serves as the basis for many of the other constraints.
Stall-Speed Constraint
A stall-speed requirement imposes a direct upper bound on allowable wing loading. From the vertical force equilibrium at stall, i.e.,
(18) 
where  is the stall speed. Therefore,
(19) 
This constraint appears as a vertical line on the constraint diagram and limits the maximum permissible wing loading. Increasing shifts the stall boundary to a higher value of , thereby permitting a smaller wing area for the same weight and stall-speed requirement.
Cruise-Speed & Maximum-Speed Constraints
A cruise-speed or maximum-speed requirement specifies that the aircraft must be capable of steady, level flight at a prescribed airspeed. For a given flight condition, the required power-to-weight ratio is obtained from the drag polar, i.e.,
(20) 
This constraint is generally a function of wing loading. It may be approximated as a horizontal line only if a representative value of  is prescribed independently of , in which case
(21) 
is a simplified estimate rather than the complete constraint relationship.
Climb-Rate Constraint
A climb-rate requirement introduces an excess-power constraint, meaning that more power is required than for level flight at the same weight, airspeed, and density altitude. For a specified rate of climb  , the required shaft power for a propeller-driven airplane is
(22) 
which may be written in normalized form as
(23) 
where
(24) 
Because the excess-power term is independent of wing loading, the climb constraint parallels the steady, level-flight power-to-weight curve and lies above it.
Generalized Performance Constraint
The cruise and climb constraints are special cases of a more general relationship based on the airplane’s specific excess power. The rate of change of specific energy may be written as
(25) 
where  is the specific excess power,
 is the rate of climb, and
 is the acceleration along the flight path. This equation shows that excess propulsive power may be used to climb, accelerate, or perform some combination of both.
For a load factor
(26) 
the lift coefficient is
(27) 
where
(28) 
Using the parabolic drag polar
(29) 
where
(30) 
the drag-to-weight ratio becomes
(31) 
Substitution into the specific-excess-power relationship gives the generalized thrust constraint as
(32) 
For a propeller-driven airplane, the corresponding shaft-power constraint is
(33) 
This equation provides a common basis for constructing cruise, climb, acceleration, and maneuvering constraints. Each specific constraint is obtained by prescribing the applicable load factor, climb rate, acceleration, airspeed, altitude, and atmospheric conditions.
The airspeed used to construct each constraint must correspond to the performance requirement being evaluated. The cruise constraint should be evaluated at the specified normal cruise speed, rather than at the maximum-range or maximum-speed condition, while a climb constraint should normally be evaluated at the speed that gives the required or maximum rate of climb. Maneuvering, takeoff, and landing constraints likewise require their own applicable speeds and configurations. Using a single assumed airspeed across all constraints can yield a mathematically consistent yet physically misleading design space.
Maneuvering Constraint
A maneuvering requirement may determine the required thrust-to-weight or power-to-weight ratio. In a sustained, level turn, the airplane maintains constant altitude and airspeed, so  and
(34) 
The required thrust-to-weight ratio is then
(35) 
For a propeller-driven airplane, the corresponding shaft-power requirement is
(36) 
The induced-drag contribution increases with the square of the load factor,  . Consequently, sustained maneuvering can impose a stringent propulsion-sizing requirement, particularly for military aircraft and other aircraft that must maintain high turn rates. Increasing the specified load factor shifts the maneuver constraint upward and may make it a limiting constraint in the design.
Takeoff & Landing Constraints
Takeoff and landing requirements may also be represented on the constraint diagram using the equations developed in the takeoff and landing performance chapter. A prescribed takeoff distance imposes a minimum thrust-to-weight or power-to-weight ratio for each selected value of wing loading. Because the liftoff speed increases with wing loading, an airplane with a higher value of generally requires more installed thrust or power to satisfy the same runway-length requirement.
The takeoff constraint can be generated by selecting a range of values and numerically solving the ground-run equation to find the minimum or that yields the prescribed liftoff distance. This approach allows thrust or power variation, propulsive efficiency, rolling resistance, aerodynamic drag, runway condition, density altitude, and wind to be included without relying on a single empirical takeoff parameter.
A landing-distance requirement generally imposes an upper bound on wing loading because touchdown speed increases approximately with the square root of . The landing constraint can be obtained by solving the landing-distance equation for the maximum allowable given the specified landing weight, maximum lift coefficient, runway conditions, atmospheric conditions, and available braking capability. It normally appears as an approximately vertical boundary on the constraint diagram, similar to the stall-speed constraint.
Takeoff and landing constraints must be evaluated using the applicable aircraft configurations and weights. The takeoff constraint uses the takeoff flap setting, takeoff weight, and available takeoff power or thrust, whereas the landing constraint uses the landing weight, landing configuration, touchdown speed, and braking assumptions.
Reference Conditions
The individual constraints on a constraint diagram may apply at different aircraft weights, altitudes, airspeeds, and propulsion-system operating conditions. For example, a cruise constraint may be evaluated at a reduced aircraft weight and at altitude, whereas takeoff and initial-climb constraints are usually evaluated near the gross takeoff weight and at a lower altitude. The resulting values of or must be converted to a common reference basis before the curves are placed on the same diagram.
Let
(37) 
represent the ratio of the aircraft weight at the specified flight condition to the takeoff weight for the particular mission or operating condition being analyzed. This takeoff weight,  , may be less than the gross takeoff weight, . For a jet airplane, let
(38) 
represent the ratio of the available thrust at the specified flight condition to the reference sea-level thrust. The corresponding constraint expressed on a sea-level-thrust and takeoff-weight basis is
(39) 
For a propeller-driven airplane, let
(40) 
represent the ratio of available shaft power at the specified condition to the reference sea-level shaft power. The normalized power constraint is then
(41) 
These normalization factors account for changes in aircraft weight and propulsion capability between the reference condition and the condition at which the performance requirement is specified. Without this conversion, constraint curves evaluated under different flight conditions cannot be consistently compared on a common diagram.
Propulsive Efficiency & Mission Effects
Propulsive efficiency influences aircraft sizing through two distinct pathways: power sizing via constraint analysis and energy or fuel requirements via mission analysis. In the constraint diagram, reduced drag or increased propulsive efficiency lowers the shaft power required to satisfy cruise, climb, maneuvering, and many takeoff requirements. This outcome shifts the corresponding constraint curves downward, reducing the required power-to-weight ratio and potentially enabling a smaller, lighter propulsion system. The influence of is less direct because it primarily shifts the stall, takeoff, and landing constraints rather than reducing the cruise power requirement directly.
In the mission analysis, propulsive efficiency relates useful propulsive power to the shaft power supplied by the propulsion system. Fuel or electrical energy consumption is then determined separately from the engine, motor, or battery characteristics. For steady cruise flight, the required shaft power may be expressed as
(42) 
which shows that, for a given flight condition, the required shaft power is inversely proportional to the propulsive efficiency and the airplane’s lift-to-drag ratio, .
For shaft-power propulsion systems, such as piston-propeller and turboprop airplanes, the fuel flow is approximately proportional to the brake power. Improvements in propulsive efficiency reduce the fuel consumption required for a given mission profile. For electrically powered aircraft, the same relationship applies, with shaft power related to electrical power through the efficiencies of the motor, controller, drivetrain, and propeller. Consequently, improvements in propulsive efficiency affect both the installed power requirement and the mission energy requirement.
Active Constraints & Design Margins
The constraints that immediately bound the feasible region at the selected design point are called the active constraints. These constraints directly determine the required wing loading, thrust-to-weight ratio, or power-to-weight ratio. Other requirements are inactive constraints because they are automatically satisfied once the active constraints have been met.
For example, the stall-speed boundary and climb requirement may determine the selected design point, while the cruise and takeoff requirements remain sufficiently far inside the feasible region that they do not control the sizing. However, the identity of the active constraints is not fixed. Changes in aspect ratio, zero-lift drag coefficient, maximum lift coefficient, propulsive efficiency, runway length, maneuver load factor, aircraft weight, or atmospheric conditions may move the curves and change which requirements govern the design.
A viable design point should be selected with a margin relative to the active constraints rather than exactly at their limiting intersection. For propeller-driven or electric aircraft, the propulsion margin may be written as
(43) 
where  is the fractional power margin. For jet aircraft, the corresponding thrust margin is
(44) 
where  is the fractional thrust margin. Similarly, a margin in wing loading may be introduced by selecting
(45) 
relative to a stall-speed, landing-distance, or other wing-loading limit.
These margins account for modeling uncertainty, performance degradation, weight growth, manufacturing variation, and off-nominal operating conditions. A design that lies exactly on a constraint has no performance margin. A margin of 5-10% may be adequate for many conventional design concepts, although greater margins may be necessary for unconventional configurations or immature technologies.
Effects of Altitude & Atmospheric Conditions
Constraint diagrams are valid only for the aircraft weights, propulsion conditions, and atmospheric conditions under which they are constructed. Reduced air density at altitude alters aerodynamic forces and may degrade propulsion capability, climb performance, service ceiling, takeoff performance, and maneuverability. Consequently, a design point selected under mean sea-level standard conditions may become infeasible at the intended operating altitude.
Constraint and mission analyses should be evaluated under the actual conditions specified by the requirements. Conservative hot-and-high conditions may also be used to identify the most demanding combination of reduced air density, increased true airspeed, and reduced propulsion capability. All constraints must then be normalized to the same reference weight and propulsion rating before being compared on a common diagram.
Jet-Aircraft Constraint Analysis
For jet-powered aircraft, the constraint analysis is formulated analogously, but the thrust-to-weight ratio replaces the power-to-weight ratio as the primary propulsion-sizing variable. In steady, level flight,  , and the corresponding relationship is
(46) 
This relationship establishes the minimum thrust required for sustained cruise at the selected flight condition. Climb, acceleration, maneuvering, takeoff, and other requirements impose additional constraints using the same generalized performance relationship.
VTOL & Powered-Lift Constraints
For VTOL or hybrid VTOL aircraft configurations, the hover or vertical-lift requirement introduces an additional constraint not primarily governed by wing loading. Hover performance depends on disk loading, meaning the thrust carried by the rotors or lifting propulsors per unit of effective disk area. For a fixed disk loading, the hover power-to-weight requirement is independent of wing loading and appears as a horizontal bound on a – constraint diagram.
In many VTOL designs, the hover requirement lies above the cruise and climb constraints and becomes the dominant driver of installed power. Vertical flight with lifting rotors generally requires more power than wing-borne forward flight driven by a thrusting propeller. Wing loading continues to determine stall speed, transition speed, gust response, and airplane-mode performance, whereas disk loading determines hover power, downwash, and vertical-lift efficiency. Consequently, powered-lift aircraft require complementary constraint analyses in terms of both – and power-to-weight versus disk loading, as discussed later in the powered-lift and VTOL design principles section.
Drag
Unlike weight or wing loading, aerodynamic drag cannot be estimated with acceptable accuracy in the early design stage. Instead, its value arises from detailed configurational choices that determine the vehicle’s aerodynamic efficiency, including the fuselage shape and fineness ratio, wing aspect ratio (), wing thickness, wing placement (high or low), landing gear arrangement, and propulsion integration. Consequently, the drag must be determined indirectly, often by a component drag synthesis. For complex configurations, wind-tunnel testing on a scaled model may be required, with aerodynamic similarity in mind, i.e., matching the Mach and Reynolds numbers. However, in practice, matching both similarity parameters may not be possible. For low-speed airplanes, matching the Reynolds number is usually more important than matching the Mach number. However, as flight Mach number increases into the compressibility-sensitive range, typically above about  to 0.4 depending on the configuration and lift coefficient, Mach number similarity becomes increasingly important. For transonic and supersonic airplanes, Mach number similarity is essential.
Historical data show that aircraft with similar sizes and missions tend to have parasitic drag coefficients, i.e., values of  , that cluster within certain ranges. Designs that deviate from these norms due to poor integration, exposed components, or compact yet aerodynamically compromised layouts will generally incur drag penalties that directly translate into increased thrust and power requirements. Such penalties are difficult to mitigate without substantial geometric and structural redesign. Drag penalties introduced early tend to persist throughout the design process and can have severe consequences for fuel consumption and mission capability.
For steady flight, the drag force is expressed conventionally as
(47) 
where is the true airspeed and is the density of the air in which the airplane is flying. The drag coefficient can be decomposed as
(48) 
where  is the induced drag that is directly correlated with lift generation.
In the early stages of the design, the induced drag of the main wing can be estimated with reasonable confidence because it depends primarily on the wing lift coefficient  , aspect ratio , and span efficiency parameter
 . For the main wing alone, this estimate may be written as
(49) 
where the value of can be estimated using lifting-line or lifting-surface theory, at least for subsonic airplanes. This wing-only form should not be confused with the airplane-level induced-drag approximation  , where is Oswald’s efficiency factor and its value includes additional effects from the complete configuration.
Other lifting components, such as the empennage, may contribute to the induced drag, but their effects are generally small and can be neglected in the preliminary design. By contrast, the zero-lift drag coefficient is sensitive to the configuration details and integration quality.
For design purposes, it is useful to further decompose into its principal physical components, i.e.,
(50) 
as further explained in the table below.
| Component | Symbol | Primary drivers | Typical treatment in early design | Design sensitivity | Approximate fraction of |
|---|---|---|---|---|---|
| Skin-friction drag |  |
Wetted area, Reynolds number, surface finish | Estimated from wetted-area build-up using component skin-friction coefficients | Moderate (geometry and surface quality) | 40–60% |
| Form (pressure) drag |  |
Body fineness ratio, local thickness, pressure recovery, separation tendency | Included through form factors applied to the skin-friction contribution | High (strongly affected by shaping and local geometry) | 10–20% |
| Interference drag |  |
Component junctions (wing-fuselage, tail-fuselage, pylons, nacelles) | Estimated using empirical corrections or lumped installation penalties | High (driven by integration and layout) | 5–10% |
| Excrescence drag |  |
Antennas, gaps, fasteners, inlets, access panels, exposed gear | Added as an empirical increment based on experience | Very high (driven by detail design discipline) | 5–15% |
- The skin-friction drag component arises from shear stresses acting over the outer “wetted” surfaces of the aircraft and may be written as
(51)

where
 is the local skin-friction coefficient, and is the resulting aircraft-level skin-friction drag coefficient. This term is also influenced by the local Reynolds number and surface finish (i.e., smooth or rough).
- Form (pressure) drag accounts for losses associated with boundary-layer growth and flow separation in bluff or poorly streamlined components. In some drag-build-up methods, it is represented separately as , while in others it is incorporated through form factors applied to the component skin-friction contributions.
- Interference drag arises at the junctions between components, such as wing-fuselage, tail-fuselage, and pylon-nacelle intersections, where interacting boundary layers and pressure fields increase losses beyond those of isolated components.
- Excrescence drag includes contributions from protuberances and discontinuities such as antennas, fasteners, panel gaps, access doors, cooling inlets, and exposed landing gear. Although individually small, these contributions can collectively represent a significant fraction of if not carefully controlled. Careful accounting for these effects is required for accurate drag predictions.
Each design team and each organization typically has its own processes for estimating drag components and drag buildup, which may use proprietary data from wind-tunnel measurements, flight-test results, and internal configuration studies.
Historical Parameter Values
The historical record shows that the quantities above reflect early, often implicit commitments that determine whether a proposed concept is feasible. Successful design teams recognize these commitments for what they are and use historical precedent as a reality check on physical plausibility. In this sense, historical data do not pose a barrier to innovation but rather serve as a reality check. While specific numerical values evolve as technologies mature, and while technology maturity is often described using technology readiness levels (TRLs), the relative ordering and clustering of key design parameters remain largely unchanged.
Designs that fall outside established historical envelopes require exceptional technical justification and, if pursued, inherently carry elevated development risk. That risk can be reduced through appropriately scaled wind-tunnel testing, when such testing is available and affordable within the program budget. CFD can provide valuable qualitative guidance on flow features and likely problem areas. Still, the absolute drag prediction accuracy of CFD, particularly for complete configurations and installed propulsion effects, remains limited for use as a primary risk-reduction tool.
| Aircraft Class | Wing Loading, (lb/ft²) |
Propulsion Sizing Metric or |
Zero-Lift Drag, |
|---|---|---|---|
| Light trainers | 10–20 | 0.07–0.12 hp/lb | 0.025–0.035 |
| Transport aircraft | 80–150 | 0.25–0.35 () |
0.020–0.030 |
| High-performance fighters | 90–150 | 0.8–1.2 () |
0.020–0.030 |
| Gliders/sailplanes | 4–8 | N/A | 0.012–0.020 |
Flight Range
The flight range of an aircraft is a fundamental performance requirement because most design requirements expect it to fly from one location to another with the best possible fuel economy. In design, the achievable flight range follows directly from the configuration’s drag characteristics and the selected wing loading and power-to-weight or thrust-to-weight ratio. For steady, level cruise, and , so that the lift-to-drag ratio at the cruise condition may be written as
(52) 
where the contributing elements of the drag coefficient have been introduced previously. Using the definition of lift coefficient for an airplane, i.e.,
(53) 
it follows immediately that, for a given cruise speed and altitude, the lift coefficient is fixed by the selected wing loading . Consequently, the cruise value of is determined by the value of the drag polar evaluated at the lift coefficient imposed by the chosen wing loading. Therefore, wing loading directly affects the range problem by fixing the cruise operating point within the configuration’s aerodynamic characteristics.
For propeller-driven aircraft, the classical Bréguet range relation may be written as
(54) 
where  is the flight range, is the propulsive efficiency,
 is the brake power specific fuel consumption expressed as fuel weight flow per unit brake power, and
 and
 are the initial and final aircraft weights, respectively. For jet aircraft, then
(55) 
where is the cruise true airspeed and  is the thrust specific fuel consumption (TSFC). For an electric airplane, then
(56) 
where  is the usable onboard electrical energy,
 is the aircraft’s weight during cruise, and
 is the overall efficiency from stored electrical energy to useful propulsive work. Although these three latter expressions differ in form, in all cases the aerodynamic contribution to range from the airframe design is reflected in the achievable lift-to-drag ratio.
For propeller and electric aircraft, the required installed power-to-weight ratio is
(57) 
so that the selected value of must be sufficient to sustain the cruise drag corresponding to the selected wing loading and cruise lift-to-drag ratio. A higher drag level or a lower cruise increases the required power-to-weight ratio and simultaneously reduces the attainable flight range. For jet aircraft, then
(58) 
so that the thrust-to-weight ratio selected during sizing is directly tied to the same cruise drag level that determines range.
Therefore, from a design standpoint, wing loading and propulsion sizing are coupled through the cruise lift-to-drag ratio achievable by the configuration at its design operating point. The wing loading fixes the cruise lift coefficient and so the attainable , while the power-to-weight ratio for propeller and electric aircraft, or the thrust-to-weight ratio for jet aircraft, determines whether that operating point can be sustained at the chosen cruise speed. Improving range requires shifting the cruise operating point to lower drag while simultaneously preserving practical wing loading and propulsion sizing. Increasing the aspect ratio or reducing profile drag generally improves aerodynamic efficiency and range, but the net design benefit must also account for any associated changes in structural weight, wing loading, propulsion sizing, and the resulting cruise operating point.
Technology Readiness Levels (TRLs)
From a design perspective, Technology Readiness Levels (TRLs) provide a standardized measure of a technology’s maturity and suitability for use in an operational aircraft or spacecraft. The established scale spans nine levels, from TRL 1, where only basic physical principles or concepts have been identified, to TRL 9, where the technology has been demonstrated in operational service (see Figure 15). In conceptual and preliminary design, TRLs serve primarily as risk indicators. Low-TRL technologies carry substantial uncertainty in performance, mass, reliability, certification effort, and cost, whereas high-TRL technologies are generally more predictable. Designs that rely on low-TRL technologies must include additional technical and schedule margin or accept an elevated risk of failing to meet their intended requirements.

Within defense acquisition programs, TRLs are strongly emphasized because technology maturity is one of the few major risk drivers that can be assessed early and independently of detailed design. Historical program reviews consistently show that cost growth and schedule delay are strongly correlated with the introduction of immature technologies at system integration. TRLs serve as both a management control and a technical metric, helping to discipline configuration selection and prevent optimistic assumptions about performance, weight, or producibility from becoming embedded in configurations that are difficult to change once development is underway. For long-lived military systems, however, technology maturity should be viewed as configuration- and time-dependent, rather than a fixed property measured at a single point in the program.
Manufacturing as a Design Constraint
Manufacturing considerations impose fundamental constraints on aerospace design before detailed drawings or production tooling are in place. A configuration that is aerodynamically efficient or structurally elegant may still be impractical or prohibitively expensive to manufacture. For this reason, manufacturability must be treated as a first-order design consideration rather than a downstream implementation issue.
Manufacturing constraints enter the design process through parts count, airframe and system complexity, material selection, tolerances, and assembly sequences. Each added part, tight tolerance, or complex geometry will increase production time, tooling costs, the inspection burden for quality control, and the risk of defects. These effects scale directly with production quantity and will persist throughout the program’s life.
The economic impact of manufacturing complexity can be summarized with a simple unit-cost decomposition, i.e.,
(59) 
Design choices that increase part count or assembly difficulty primarily increase labor and quality costs, which often dominate material costs in aerospace production. Rotorcraft, for example, generally have higher costs because they have many rotating parts that are subject to high structural loads. Unlike performance penalties, these costs cannot be mitigated through operational adjustments once the design is frozen.
Manufacturing considerations will also constrain allowable structural concepts. Highly optimized structures with minimal margins are often sensitive to small variations in material properties or manufacturing quality. To ensure repeatability, inspectability, and certification compliance, designers may accept additional structural weight to accommodate these factors. Consequently, the lightest theoretical structure is rarely the lightest producible structure.
Material choice strongly influences this design trade-off. The use of traditional aluminum alloys generally allows simpler fabrication, clearly defined load paths, easier inspection, and greater damage tolerance, often at the expense of slightly increased structural weight. Composite structures, such as those used extensively on the Airbus A350 and Boeing 787 (Figure 16), can provide significant structural-weight savings when their anisotropic properties and manufacturing processes are used effectively. The achievable saving is configuration- and component-dependent and may be reduced by joints, impact and damage-tolerance requirements, lightning protection, inspection provisions, and manufacturing constraints. Composite structures are also sensitive to manufacturing quality. Material ply placement errors, curing defects, voids, and subsurface damage can compromise the structural integrity and remain difficult to detect. Well-publicized quality-control issues on modern composite airframes underscore that these risks are not merely anecdotal. Consequently, material selection reflects manufacturing control, inspection capability, and certification realities as much as it reflects structural efficiency.

For aircraft produced in large numbers, manufacturing efficiency strongly influences the program’s overall success. A design that is marginally heavier or less aerodynamically efficient but simpler to manufacture may be preferable to a technically superior configuration that requires complex tooling, extensive manual labor, or low production rates. Once tooling concepts, material systems, and assembly strategies are selected, the design becomes increasingly resistant to change, and late performance-driven modifications often introduce disproportionate manufacturing disruptions and cost growth. For these reasons, experienced design teams evaluate manufacturability concurrently with aerodynamic, structural, and propulsion considerations. In aerospace systems, a design that cannot be produced reliably, repeatedly, and economically is not viable, regardless of its predicted performance.
Decision Milestones
The design of aircraft and spacecraft does not proceed as a continuous, unconstrained refinement from idea to finished vehicle. Instead, it unfolds in a sequence of phases in which design freedom steadily decreases while commitment and cost increase. Although the exact terminology varies across organizations, the aerospace design process is commonly described as comprising conceptual, preliminary, and final design phases, with formal reviews marking transitions between them. The process can be visualized using a design triangle, as shown in Figure 17.

The importance of this staged process lies in recognizing that early decisions will always dominate the outcomes. The design principles discussed in this chapter are most influential at the beginning of the process, when the configuration is still flexible and errors are still recoverable. As the design matures, analysis becomes more detailed and precise, but the opportunity to change fundamental commitments diminishes rapidly.
Conceptual Design
Conceptual design is concerned with feasibility in the most literal sense, i.e., whether a proposed vehicle can exist at all within known physical, technological, and operational limits. At this stage, the design team must determine whether any configuration that meets the mission requirements can work, rather than attempting to predict performance accurately. The geometry is intentionally incomplete, subsystem definitions are approximate, and analytical models are deliberately low-order. The objective is to identify dominant effects, scaling trends, and obvious incompatibilities, rather than to seek out physical details with high numerical precision.
Historical data, scaling arguments, and order-of-magnitude estimates all play a central role in conceptual design. These approaches enable rapid assessment of weight, wing loading, propulsion class, and overall configuration without committing to a detailed flight-vehicle geometry. They are used to establish physical bounds, i.e., what must be true for the concept to be viable, and what combinations of requirements or design choices are immediately disqualifying. Thinking “out of the box” has great value in aerospace design, but only when the box is correctly identified. At the conceptual stage, the design box comprises the physical constraints, certification limits, and integration realities that determine feasibility. The design team’s goal is to challenge conventional assumptions while respecting non-negotiable ones, without ignoring the limitations imposed by the box.
Decision matrices, polling methods, and tools may be used during conceptual design, usually with great effectiveness, but only in a supporting role. They can help structure discussion, expose competing priorities, and document trade-offs among options that are already physically plausible. But they do not determine feasibility. No type of decision matrix can compensate for selecting an unrealistic wing loading, an insufficient propulsion margin, or an infeasible mass fraction. Physical principles and theoretical limitations determine which concepts belong in the matrix, and the matrix only facilitates comparisons among them.
The table below illustrates how operational needs for a small survey drone can be translated into measurable engineering characteristics during the conceptual design phase. Customer needs are listed in order of importance, while the corresponding design parameters are quantities the design team can size, analyze, and trade off. The numerical entries indicate the strength of the relationship between each need and each parameter, making explicit where design effort is most strongly rewarded. Equally important, the table helps highlight coupling between requirements. Parameters that strongly influence multiple needs, such as endurance, wind tolerance, and launch-and-recovery footprint, emerge as dominant drivers of the configuration.
| Customer Need | Priority | Endurance (min) |
Range (km) |
Payload (kg) |
Wind (m/s) |
Noise (dBA) |
Launch/ Recovery Area (m2) | Cost ($) |
Mean Time to Repair (min) |
|---|---|---|---|---|---|---|---|---|---|
| Mission coverage per sortie | 5 | 9 | 9 | 3 | 3 | 1 | 1 | 1 | 1 |
| Confined-area launch & recovery | 5 | 3 | 1 | 3 | 3 | 1 | 9 | 1 | 3 |
| Image / mapping stability | 4 | 1 | 1 | 3 | 9 | 1 | 1 | 1 | 1 |
| Low acoustic signature | 3 | 1 | 1 | 1 | 1 | 9 | 1 | 3 | 1 |
| Rapid transport & deployment | 4 | 1 | 1 | 1 | 1 | 1 | 9 | 1 | 3 |
| Low procurement & operating cost | 4 | 1 | 1 | 1 | 1 | 1 | 1 | 9 | 3 |
| Easy field maintenance | 3 | 1 | 1 | 1 | 1 | 1 | 1 | 3 | 9 |
It is during conceptual design that the most consequential commitments are made, often implicitly. Choices regarding flight vehicle class, mission role, approximate weight, wing loading or equivalent lifting characteristics, number and type of engines, and basic integration concept establish the performance regime in which the aircraft or spacecraft will operate. Although these choices are often described as provisional, experience shows that they are rarely reversed without abandoning the concept entirely. Designs that fail at this stage do so not because of analytical errors, but because the implied commitments are incompatible with the mission requirements. History speaks for itself.
Sometimes a spiral design process is used, which is best understood as an integral part of the conceptual design process rather than a separate development strategy. During the conceptual design, broad configuration choices will establish the feasible configuration space, but many assumptions remain uncertain. Spiral iteration occurs as these assumptions are revisited through progressively more detailed analyses, trade studies, and limited testing to reduce uncertainty before commitments are finalized. This iteration step strengthens early decisions by exposing the dominant sensitivities and inconsistencies, while any changes remain quick and inexpensive. Once the design transitions out of the conceptual phase, the opportunity for meaningful spiral refinement diminishes rapidly, and continued iteration tends to increase engineering effort and cost rather than improve the design.
The conceptual design process typically concludes with a formal review, called a Conceptual Selection Review (CSR), that brings all parties to the table, including management. The purpose of this review is to decide whether the concept is physically plausible, internally consistent, and worthy of further development. Approval at this stage represents a deliberate commitment to narrowing the configuration space, not confirmation that the design is ready to proceed to the next phase.
Design Task: Conceptual sizing of a small electric fixed-wing UAV
Consider a small fixed-wing electric UAV intended for routine aerial imaging. The mission is to carry a stabilized camera payload and perform a one-hour flight at moderate cruise speed. A workable set of top-level requirements is a payload mass of  = 1.0 kg, a total flight time of
 = 60 min, a cruise speed of
 = 20 m/s (about 45 mph), and a requirement to land with 20% of the usable battery energy remaining. A conventional high-aspect-ratio fixed-wing configuration with a single pusher propeller is selected as the baseline. This choice is driven by simplicity and by the strong coupling between endurance and aerodynamic efficiency for this class of mission.
A first-cut mass budget is constructed immediately because weight drives power and energy requirements. Representative day-one estimates are a payload of 1.0 kg, avionics and servos of 0.4 kg, airframe structure of 1.2 kg, and propulsion hardware of 0.5 kg. Excluding the battery, the non-battery mass is  1.0 + 0.4 + 1.2 + 0.5 = 3.1 kg. An energy model relates the required battery energy to cruise power and flight time, i.e.,

where  is the shaft power required in cruise, is the overall powertrain efficiency from battery to shaft power, and
 is the usable fraction of battery energy after accounting for reserve. With a 20% reserve, = 0.80. For a small, efficient UAV in this weight class, a reasonable first estimate is
 180 W and
 0.70. For a one-hour mission, = 1 hr, giving

Assuming a representative battery specific energy of  240 Wh/kg, the battery mass is

The corresponding first closed estimate of takeoff mass is

A quick consistency check on the still-air distance covered during the specified one-hour mission gives

This suggests that a 30 km operational mission is plausible, accounting for climb, maneuvering, wind, and the required energy reserve.
Now consider a common design failure mode. If small airframe modifications and mass additions are made after the initial concept is formed and the non-battery mass increases by only 0.6 kg, then  and
 kg. Because the cruise power increases with weight and drag, suppose the required cruise power now rises from 180 W to 220 W. The required battery energy then becomes

and the corresponding battery mass becomes

The revised takeoff mass is then

A seemingly modest increase in non-battery mass has required a substantial increase in battery mass, raising the takeoff mass from 4.44 kg to 5.34 kg. This higher weight, in turn, tends to drive the required power upward again, producing the familiar weight-growth feedback loop. Design outcome notes:
- Flight time directly drives battery mass, and battery mass can be a large fraction of takeoff mass.
- Small increases in non-battery mass propagate into higher power and energy requirements through a reinforcing weight-growth feedback loop. Depending on the scaling of power, battery mass, and structure, the sizing iteration may converge to a heavier design or may fail to close.
- Early configuration, cruise speed, and mass-budget assumptions expose weight-growth sensitivity long before high-fidelity analysis is needed.
Preliminary Design
Preliminary design translates the conceptual vision into a coherent and internally consistent configuration. At this stage, the aircraft or spacecraft ceases to be a vision or idea and instead becomes a specific physical arrangement. The external geometry is now fixed to first-order size and shape, initial 3-view CAD drawings with overall dimensions are prepared as shown in Figure 18, major subsystems are sized, and simplifying assumptions acceptable in conceptual design are progressively removed. The effects previously absorbed into margins, particularly installation and interaction effects, must now be addressed explicitly, thereby increasing design effort and incurring costs.

A defining feature of the preliminary design process is the need for interdisciplinary coupling. To this end, aerodynamic loads drive structural weight, structural layout constrains aerodynamic shaping, and propulsion installation affects drag, stability, thermal environment, and noise. Finally, the control authority depends on both geometry and propulsion state. Weight (and balance) estimates are refined; stability and control characteristics are evaluated with sufficient fidelity to size the empennage; and trim and control margins are exposed. Installation effects, especially those associated with propulsion, can no longer be ignored; they often introduce penalties that can propagate throughout the design process.
What is brainstorming, and how does it influence design?
Brainstorming can play a useful, but narrowly defined, role in the transition from conceptual to preliminary design. Its purpose is to broaden the set of plausible approaches before major commitments become costly, not to generate solutions unconstrained by physics. The outcome should be a small set of credible alternatives, configuration refinements, integration strategies, or changed assumptions that can be subjected immediately to physical reasoning and first-order analysis. Brainstorming is not the same as a discussion over a cup of coffee in the break room and must be conducted in a rigorously defined environment to be effective.
By this stage, any design freedom will have narrowed substantially. The central issue is no longer whether the concept is feasible in principle, but whether the defined configuration can satisfy all performance and other requirements simultaneously while maintaining acceptable margins. Changes to fundamental commitments, such as wing loading, propulsion placement, or basic configuration or sizing, remain possible but will become increasingly disruptive and costly, requiring cascading changes across multiple disciplines and subsystems. Therefore, preliminary design becomes the point at which the major disciplinary analyses and configuration constraints must converge.
It is also the stage at which many designs will encounter serious difficulties in justifying advancement. Assumptions that initially appeared reasonable in isolation may prove incompatible once interdisciplinary coupling, margins, and off-design conditions are considered. Problems uncovered at this point are rarely subtle and typically involve insufficient flight control authority, unacceptable weight growth, excessive drag, or inadequate propulsion margins. Preliminary design identifies where the main risks are concentrated and which assumptions would have the greatest consequences if they prove invalid.
The preliminary design process culminates in a Preliminary Design Review (PDR), during which the configuration is assessed for technical viability and sufficient maturity to warrant detailed development. However, passing a PDR does not imply that the design is complete. It only means that its fundamental configuration is sound, or at least as sound as the engineers can determine based on analysis and experience. Designs that fail at the PDR stage almost always do so because of decisions made during conceptual design, not because of shortcomings in later levels of analysis.
Lessons Learned #3 – de Havilland Comet
The de Havilland Comet entered service with unprecedented flight performance but a limited understanding of metal fatigue behavior in pressurized aluminum fuselages. Structural details such as punched rivet holes and thin skins were acceptable from a static strength standpoint. Still, they proved vulnerable to repeated pressurization cycles, which generated fatigue cracks in the aluminum skin. Although the aircraft met its initial weight and performance targets, an insufficient durability margin for the operational environment led to catastrophic in-flight structural failures, resulting in grounding until the much-improved Comet 4 appeared some years later.
Lesson learned: The Comet failures reshaped structural design practice by exposing the critical role of fatigue and damage tolerance under repeated operational loading. Design margins are necessary responses to uncertainty in loads, environments, and usage, and must be evaluated against realistic operational spectra.
Propulsion System Selection & Integration
Propulsion selection is an early configuration decision that determines the class of energy-conversion system to be used and, in doing so, constrains the entire vehicle layout. It is not a sizing exercise, nor is it a choice among specific engines. The objective at this stage is to identify which propulsion class is physically compatible with the mission requirements and operating regime. Propellers, turbofans, turbojets, electric propulsors, rockets, and hybrid systems exhibit fundamentally different efficiency characteristics, mass fractions, installation requirements, and feasible operating envelopes. Propellers favor low to moderate flight speeds, turbofans and turbojets favor higher speeds, and rockets and non-airbreathing engines operate independently of the atmosphere. These differences in performance and efficiency are dictated by fundamental momentum and energy considerations and cannot be recovered later through optimization or refinement.
Effective propulsion selection (see Figure 19) relies on matching propulsion characteristics to mission demands rather than maximizing nominal efficiency in isolation. At this stage, order-of-magnitude analyses, historical precedent, and simple scaling arguments are sufficient to eliminate unsuitable propulsion classes and to identify a small set of viable candidates. Detailed cycle analysis and high-fidelity aerodynamic modeling are only meaningful after the propulsion class and basic configuration have been established. Once a propulsion class has been selected, the dominant design problem becomes integrating the propulsion system with the airframe. Propulsor placement, inlet and exhaust geometry, and installation layout rapidly fix external geometry, internal volume allocation, structural configuration, and even the operational concept. These choices are among the least reversible in early airplane design, so the design team faces a considerable burden to perform due diligence.
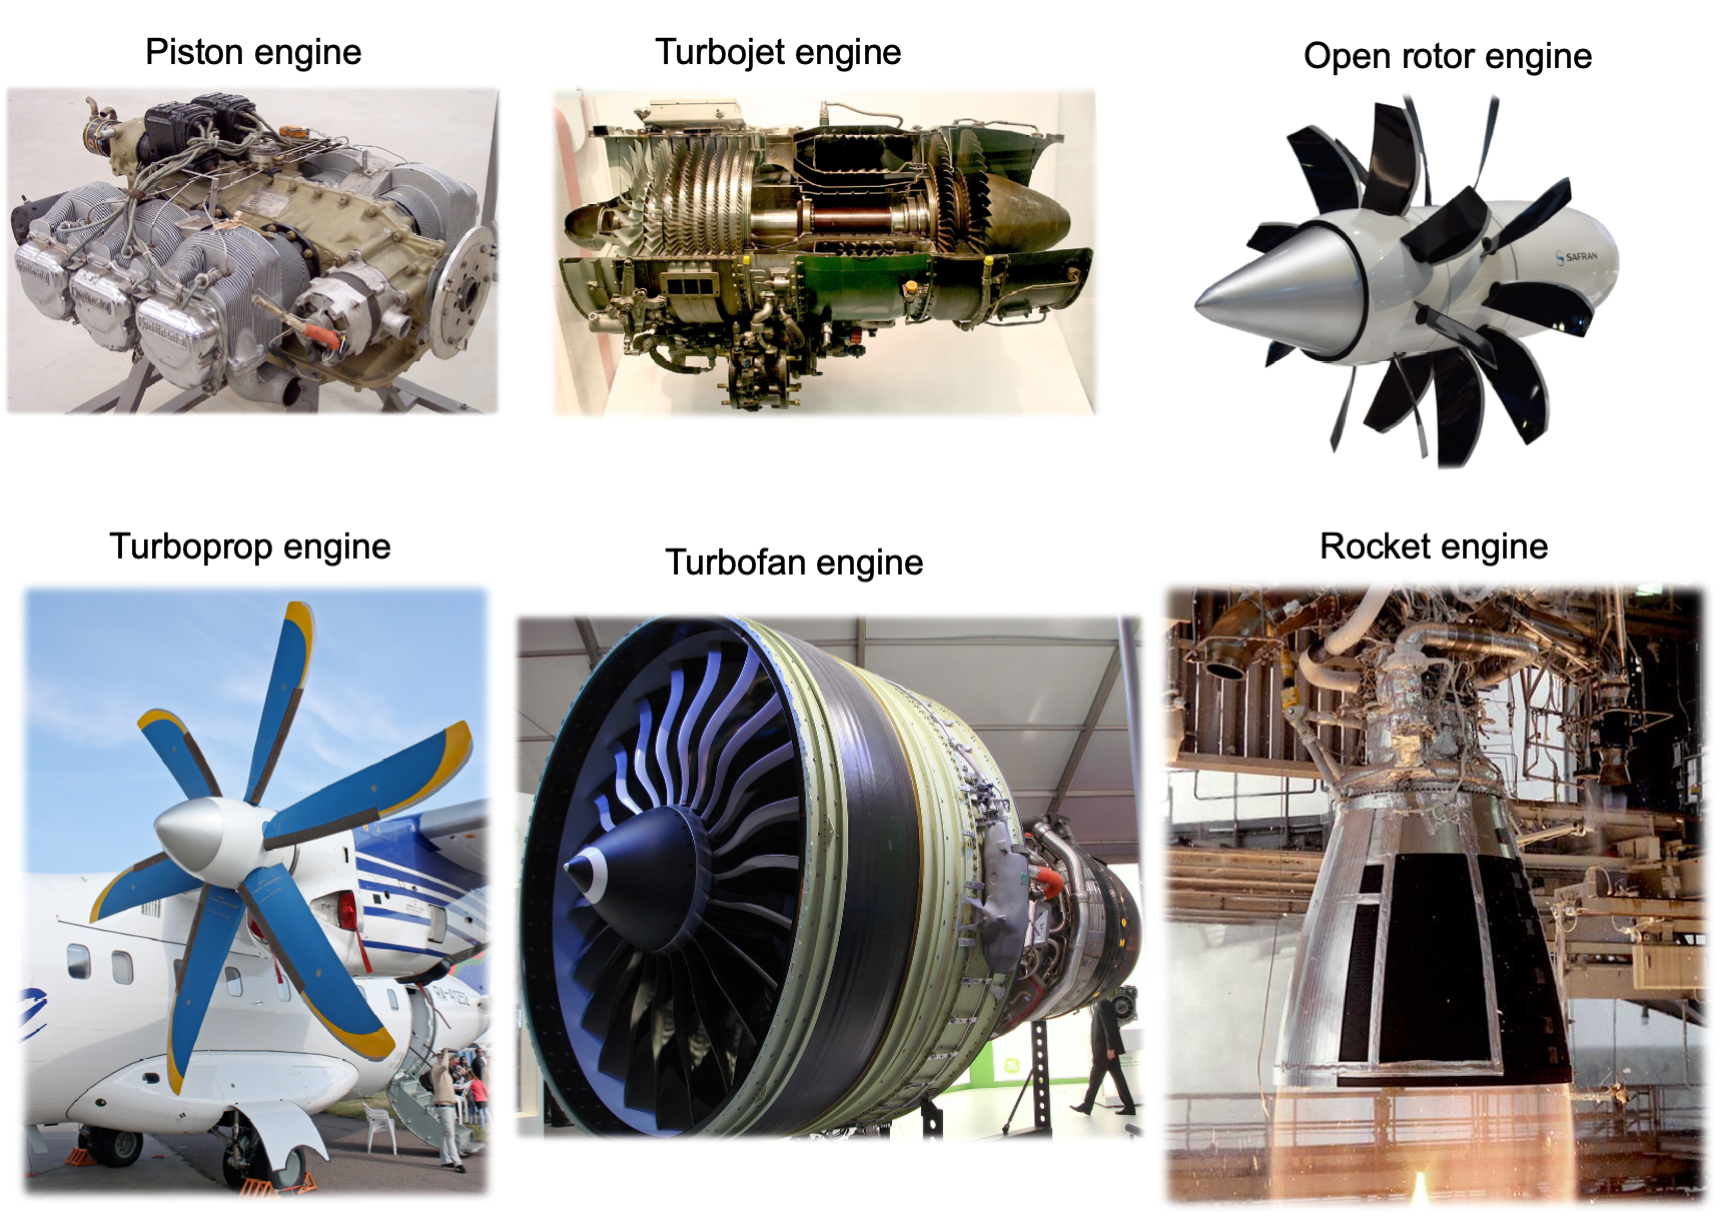
A central distinction is between the uninstalled and installed powerplant performance. Propulsion systems are normally characterized under idealized inlet and exhaust conditions. When installed on an aircraft, the propulsor must operate in distorted, angle-of-attack-dependent flow, in proximity to solid boundaries, and with strong interaction between inlet and exhaust streams and the surrounding airframe; see Figure 20. The resulting installation losses and flow-field interactions can substantially alter thrust, power, efficiency, and stability margins. Installation effects are first-order consequences of configuration choices, not secondary corrections.

Propulsion-airframe integration also introduces strong couplings among the propulsion state, aerodynamics, and stability and control characteristics. Changes in thrust or power will modify local flow fields, lift distributions, pitching moments, and control effectiveness, particularly at low airspeeds and high power settings. In this sense, the propulsion system becomes a fully active component of the flight vehicle, not just a passive source of thrust.
For propeller-driven aircraft, the dominant interaction mechanism is the propeller’s slipstream, as shown in Figure 21. The accelerated downstream flow modifies the local dynamic pressure over portions of the wing and tail. A useful first-order estimate of the resulting lift increment over the immersed area is
(60) 
where  is the free-stream velocity,
 is the mean axial velocity in the slipstream at the lifting surface,
 is the effective area immersed in the slipstream, and
 is an effective lift coefficient for that immersed portion of the lifting surface. Because this velocity increase is highly non-uniform, the propeller installation also modifies the spanwise and chordwise loading on the wing, thereby affecting induced drag, structural bending moments, and control-surface effectiveness. These effects cannot be inferred from isolated propeller performance.

In modern propeller-driven and turboprop aircraft, powerplant integration must be treated as a coupled aerodynamic and aeroacoustic problem. Unsteady interactions between the propeller wake, the fuselage, and other lifting surfaces can dominate both tonal and broadband noise and can strongly influence local aerodynamic loadings. Turboprops are also often perceived as noisier than jet aircraft, at least based on passenger assessments, so mitigating aeroacoustic effects is a high-priority design objective. At the same time, the high propulsive efficiency and excellent short-field performance of turboprop aircraft make them operationally attractive and likely to continue playing a major role at many regional airports.
Approaches to propulsion integration also introduce power- or thrust-dependent pitching moments and associated trim changes. For example, a tractor or pusher propeller may produce a power-dependent pitching moment through its thrust-line offset, slipstream effects on the wing and tail, and changes in local downwash and dynamic pressure. The direction and magnitude of this tendency cannot be inferred from the tractor or pusher arrangement alone; they depend on the complete propulsion-airframe geometry, center-of-gravity location, power setting, and flight condition. Jet-powered configurations exhibit analogous coupling through inlet distortion, pressure recovery variation, and exhaust interaction with nearby surfaces, particularly at high angles of attack. From a design standpoint, these propulsion-dependent effects cannot be corrected easily after a design freeze. Control-surface sizing, tail volume, and structural margins must be established with these couplings explicitly in mind. Attempts to resolve propulsion-induced deficiencies in trim, stability, or controllability late in the design process typically add weight, increase drag, and increase system complexity, and often increase certification risk, especially under low-speed and engine-failure operating conditions.
Lessons Learned #4 – Boeing 737 MAX
A recent example of the consequences of inadequate propulsion-airframe integration is the Boeing 737 MAX. The introduction of larger, higher-bypass engines, driven by efficiency, emissions, and fleet commonality requirements, necessitated changes in engine placement relative to the wing and fuselage. These changes altered the aircraft’s aerodynamic characteristics, particularly the pitching-moment behavior at high angles of attack, creating new couplings between propulsion, aerodynamics, and flight controls that did not exist in earlier variants. Rather than being fully resolved through redesign, these integration effects were mitigated through control-system augmentation using a system known as MCAS. The resulting system-level complexity and reliance on software to compensate for an underlying configuration incompatibility illustrate how late-stage accommodation of propulsion-airframe interactions can introduce new risks. Beyond the technical deficiencies, subsequent investigations by the FAA and NTSB concluded that elements within Boeing engaged in ethical misconduct by failing to fully disclose material information about MCAS functionality and system authority to regulators and operators during certification.

Lesson learned: Late-stage accommodation of propulsion-airframe incompatibilities through control-system augmentation can obscure configuration-induced hazards and shift risk into software logic and operational procedures. Unless the modified system is treated as effectively new and subjected to full safety reassessment, such an approach departs not only from conservative aerospace design practice but also from the ethical obligation to place safety above schedule, cost, and competitive pressures.
Noise & Noise Certification
Meeting civil aircraft noise requirements, as defined by the ICAO and implemented by authorities such as the FAA and EASA, must be treated as a configuration requirement. Certification is based on prescribed flight procedures and noise measurements made at fixed observer locations. The resulting metrics place strong weight on both tonal content and the spectral noise bands most relevant to human perception. Consequently, design choices that introduce strong discrete-frequency components or increase high-frequency broadband noise can incur disproportionate penalties, even when the aircraft’s underlying increase in acoustic power is modest. Aircraft designs that do not meet the applicable noise certification standards may not satisfy their certification basis and may not be eligible for approval for civil operation without redesign, operational limitations, or other approved noise-mitigation measures.
Noise Standards
The applicable aircraft-noise certification metric depends on the aircraft category and the governing standard. Effective perceived noise level (EPNL, expressed in EPNdB) is a principal metric for transport-category and turbojet-powered airplane certification, whereas other categories may use different procedures and metrics, such as A-weighted maximum noise levels for certain small propeller-driven and commuter-category airplanes. EPNL is a single-number measure of perceived noise level and includes explicit corrections for tone and noise duration. In the U.S., the FARs “Part 36 – Noise Standards: Aircraft Type and Airworthiness Certification” define the instrumentation and test procedures. For subsonic transports and turbojet-powered aircraft, microphones are placed at fixed reference locations along and adjacent to the runway to collectively measure noise relative to the prescribed flight procedures, as shown in Figure 22.
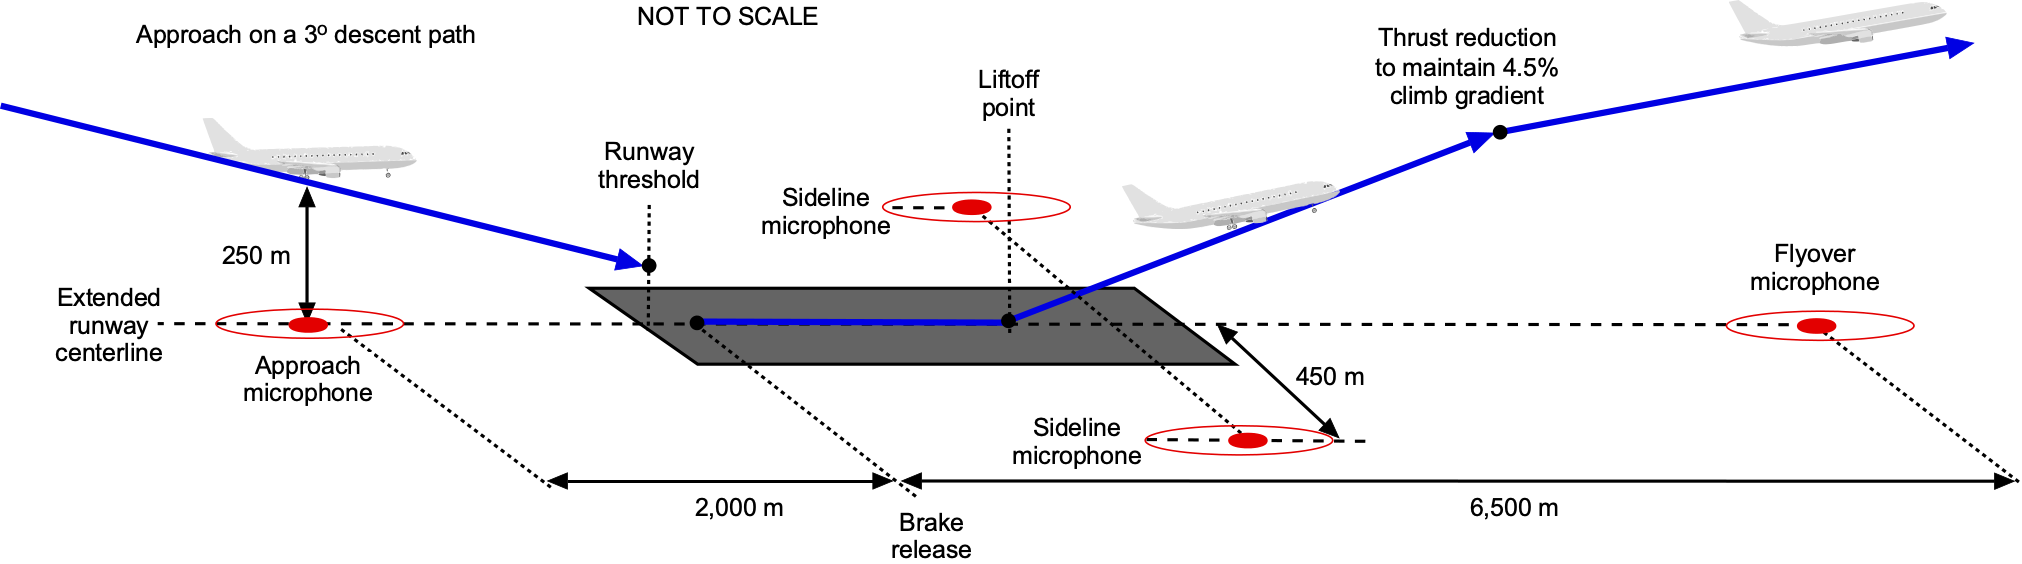
The configuration features that contribute to noise are those that increase the characteristic velocity associated with thrust production and turbulent loadings. High jet exhaust velocities and high propeller or rotor tip speeds amplify the dominant propulsion-noise mechanisms and erode certification margin. In practice, the certification metrics directly inform early decisions on bypass ratio, rotor and propeller diameters, allowable tip speed, and the number of propulsors required to achieve the design thrust. A further major contributor is propulsor-airframe interaction, where inflow distortion, wake impingement, and close-blade passage near fixed structures introduce periodic loading and strong tonal components that are heavily weighted in certification metrics. For pusher and distributed-propulsion layouts, this interaction noise often dominates the measured levels.
Assessing Noise in Design
As propulsion noise is reduced to meet increasingly stringent certification limits, airframe noise sources become increasingly important. Landing gear, high-lift devices, and externally mounted payloads, antennas, and sensors generate a separated, highly turbulent flow that radiates broadband noise. Because certification measurements are obtained during both high-thrust takeoff and low-thrust approach conditions, these airframe contributions can determine compliance with certification standards. The design process must include an explicit feedback loop in which candidate layouts are screened at the prescribed certification operating conditions using simple noise-risk indicators and revised early if the available margin is inadequate. Layouts showing unfavorable trends in these indicators are modified or discarded before higher-fidelity acoustic analysis is performed. High-fidelity aeroacoustic tools are then reserved for a small number of short-listed configurations to verify the certification margin.
For a turboprop airliner, the principal indicators listed in the table below are based on quantities that can be estimated during preliminary design. These include the propeller tip Mach number, disk loading, and blade loading. Additional indicators address tonal prominence, inflow distortion at the propeller plane, propulsor-airframe interaction, and airframe noise in the approach configuration. Each indicator is evaluated under certification-relevant takeoff, sideline, and approach operating conditions, and the resulting scores are used to screen candidate layouts for noise-certification risk.
For the propeller-related indicators, useful preliminary quantities are the propeller tip Mach number, the disk loading, and a thrust-coefficient-based blade-loading proxy, i.e.,
(61) 
where  is thrust,
 is the propeller disk area,
 is the propeller diameter,
 is the rotational speed in revolutions per second, is the free-stream air density, is the flight speed, and
 is the free-stream speed of sound. These quantities are not, by themselves, a noise prediction, but they provide useful indicators of the likelihood of high tonal noise, limited certification margin, and sensitivity to installation effects.
| Indicator | What is evaluated in preliminary design | Score = 1 (Low) | Score = 3 (Moderate) | Score = 5 (High) |
|---|---|---|---|---|
| Tip Mach number | Propeller tip speed relative to the local speed of sound, evaluated at takeoff, sideline, and approach | Less than 0.75 | 0.75 to 0.80 | Greater than 0.80 |
| Disk loading | Thrust per unit propeller disk area at takeoff power | Low | Medium | High |
| Blade loading | Thrust coefficient or equivalent blade-loading proxy at takeoff power | Low | Medium | High |
| Tonal prominence risk | RPM scheduling and likelihood of strong periodic aerodynamic loading | Stable RPM, weak tones expected | Some periodic loading | RPM modulation or strong tones likely |
| Installation inflow distortion risk | Propeller plane location relative to wing or fuselage boundary layers and wake fields | Clean inflow | Moderate non-uniformity | Strong non-uniformity expected |
| Propulsor-airframe interaction risk | Minimum clearances and whether the propeller wake impinges on wing, strut, or fuselage | Clear | Some interaction | Close clearance or direct wake impingement |
| Airframe noise in approach configuration | Landing gear, high-lift settings, and exposed external items during approach | Low exposure | Moderate exposure | High exposure |
The scoring system is intended only as a preliminary screening tool. It does not replace certification testing or detailed acoustic prediction, but it helps identify layouts that are likely to require additional design margin or mitigation. The values 1, 3, and 5 in the preceding table should be interpreted as anchor points on a five-point scale, so intermediate scores such as 2 and 4 may be assigned when the risk falls between the listed descriptions. In the example scoring shown in the table below, Concept B consistently has a higher noise-certification risk because its smaller propeller diameter requires higher rotational speed and greater blade loading at the certification operating points. These changes increase the likelihood of strong tonal content and reduce the available certification margin. Concept A, with a larger propeller diameter and lower rotational speed, carries a lower risk of propulsion-related noise, leaving greater flexibility to manage installation and airframe noise contributions.
| Indicator | Concept A | Concept B |
|---|---|---|
| Tip Mach number | 2 | 4 |
| Disk loading | 2 | 4 |
| Blade loading | 2 | 4 |
| Tonal prominence risk | 2 | 4 |
| Installation inflow distortion risk | 2 | 2 |
| Propulsor-airframe interaction risk | 2 | 3 |
| Airframe noise in approach configuration | 3 | 3 |
Crashworthiness & Survivability
Crashworthiness and survivability determine whether an aircraft can realistically be certified, operated, and accepted into service, and early design decisions largely shape them. Crashworthiness concerns how impact energy is absorbed by the airframe and other components in a controlled manner, how heavy items such as batteries, fuel, payloads, passenger seats, and propulsion units are restrained, and how post-impact hazards are mitigated. Once the basic layout, landing-gear concept, propulsion installation, and internal arrangement are fixed, opportunities to improve crashworthiness are usually limited. In practical design terms, this reduces to providing usable stroke or crush distance, arranging load paths that promote progressive collapse, allowing non-essential components to separate in a controlled way, and keeping hazardous energy sources away from occupied or mission-critical volumes.
From a regulatory standpoint, crashworthiness is treated as a normal element of civil airworthiness approval, and guidance and certification material issued by the FAA and EASA address survivable impact conditions, occupant protection, restraint systems, and post-crash fire risk. Although the detailed requirements vary with aircraft category and certification basis, survivability is evaluated for the aircraft and its system installations, and poor layout choices can increase both certification and operational risk. To support this process, the NASA Impact Dynamics Research Facility, shown in Figure 23, conducts full-scale, controlled aircraft crash tests in which complete aircraft are suspended and released onto prepared surfaces that simulate different terrain conditions. A joint NASA-FAA research program has used the facility to “crash” dozens of aircraft to develop practical crashworthiness and passenger-survivability technologies with minimal weight and cost penalties.

The same considerations apply, with different emphasis, to uncrewed aircraft and eVTOL configurations. Even in the absence of occupant-protection requirements, crash behavior strongly affects ground risk, fire and thermal-runaway hazards from onboard batteries, and the likelihood of recovering the vehicle after an accident. Battery placement and containment, separation between propulsion units and payload bays, and the sensitivity of impact behavior to external items such as pusher propellers, booms, and sensor installations are all determined during configuration definition. Treating crashworthiness explicitly at this stage is consistent with the broader design principle that early layout decisions dominate safety, certifiability, and overall program risk.
Final Design
The final design phase concerns the realization of the aircraft. By this stage, the overall layout has been fixed, and the task is to implement it in a form that can be built, certified, operated, and supported. Detailed structural sizing, systems integration, manufacturing planning, certification compliance, and operational reliability dominate the work. High-fidelity analysis and experimental validation, including wind-tunnel testing (Figure 24) and ground and flight testing, are used to verify aerodynamic performance, loads, stability, and control, and regulatory compliance. Their purpose is to confirm and refine an established design, not to revisit fundamental configuration choices. Most high-level design decisions are then effectively frozen, and even small changes tend to propagate widely through the aircraft and its development program.

In the final design phase, high-fidelity numerical analysis, including finite element analysis (FEA) and computational fluid dynamics (CFD), is used primarily for verification, refinement, and certification support. By this stage, FEM is applied to detailed stress, stiffness, fatigue, and load-path assessment (Figure 25), and CFD is used to confirm aerodynamic performance, loads, and local flow features. These tools reduce uncertainty and support compliance, but they do not replace or reopen the fundamental configuration and sizing decisions that were made earlier in the design process.
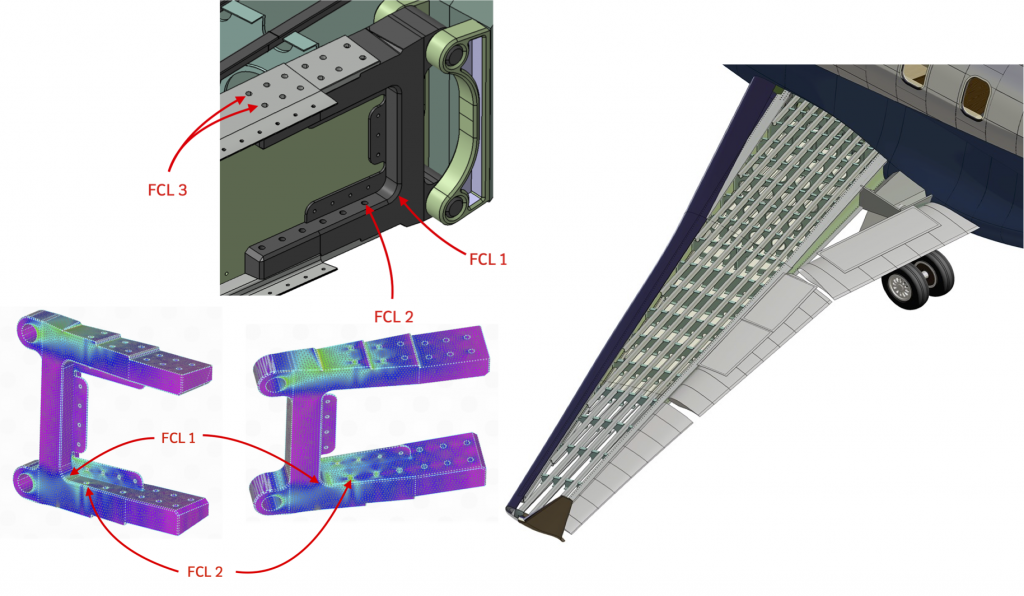
The final design concludes with a Critical Design Review (CDR), after which the design is considered sufficiently mature to proceed to fabrication, testing, and production. Experience shows that problems identified after this point are rarely corrected without substantial cost increases, schedule impacts, or performance compromises. Design reviews throughout the development process serve as decision gates. Each review is a clear commitment to move forward with a progressively constrained set of options. When used effectively, these reviews challenge assumptions, expose hidden coupling between subsystems, and verify that early design principles have not been eroded.
Following the final design and CDR, the program transitions from design to realization by manufacturing one or more prototypes or development aircraft. These aircraft are used to verify that the as-built configuration meets its predicted aerodynamic, structural, propulsion, and systems performance, and to demonstrate compliance with applicable certification and airworthiness requirements. Ground tests, wind-tunnel tests, and CFD (Figure 26) may continue in parallel to address local design changes, verify loads and flutter clearance, examine stall-onset characteristics along the wing, and help reduce the overall technical risk before first flight.

Flight Testing as Part of Design
The flight-test program provides the primary validation of aircraft performance, handling qualities, stability and control, structural behavior, propulsion integration, and system functionality. Although flight testing (Figure 27) often reveals deficiencies and implementation issues, it is not intended to recover fundamental configuration choices. At this stage, design freedom is limited, and most corrective actions consist of local geometric changes, control-law modifications, system tuning, and operational limitations. Experience shows that a successful flight-test program depends strongly on the quality of the preceding conceptual, preliminary, and final design phases. Flight testing serves primarily as a verification and risk-reduction activity, not as a substitute for sound early design decisions.

Following completion of flight testing, program activity shifts from technical discovery to regulatory compliance and operational readiness. The dominant effort becomes certification or airworthiness approval, manufacturing qualification, and establishment of operational and maintenance procedures. At this point, configuration changes are strongly constrained by the certification basis, tooling, and approved analyses and test evidence, so subsequent evolution is normally limited to tightly scoped block upgrades, service bulletins, and operational changes rather than to substantive airframe or propulsion reconfiguration.
A word of caution is warranted. Flight testing in the eVTOL and UAS sector is often conducted ad hoc, driven more by rapid iteration and schedule pressure than by structured test planning, instrumentation, and formal envelope expansion. While this approach can accelerate early prototyping, it frequently lacks the discipline required to systematically uncover failure modes, quantify margins, and validate underlying models. Consequently, important lessons that would normally emerge from a structured flight-test program are sometimes discovered only through operational incidents or late redesign.
Certificate of Airworthiness
Completion of the required development flight and ground tests supports approval of the aircraft’s type design, typically through the issuance of a type certificate. A Certificate of Airworthiness (C of A) is then issued for each individual aircraft after it has been shown to conform to the approved type design and to be in a condition for safe operation; see Figure 28. Each aircraft operating under a type-certificated airworthiness framework must hold its own C of A. When that certificate is issued by an aviation authority recognized under the ICAO framework, it provides the basis for international recognition of the aircraft’s airworthiness, although actual operation in another state’s airspace remains subject to the applicable operating rules, registration requirements, equipment requirements, and national permissions. The approved type design is supported by compliance evidence obtained through structured flight and ground testing, while the C of A for an individual aircraft is based on conformity to that design and its condition for safe operation.

The Inevitability of Cost
The common customer complaint that airplanes “cost too much” is understandable, but the cost of an airplane cannot be separated from the design choices that determine it. Cost is the cumulative outcome of performance requirements, certification standards, manufacturing methods, and production scale. Life-cycle cost encompasses the total economic burden from development and production through decades of operation, maintenance, support, and eventual retirement, rather than merely the purchase price. Most of that cost is effectively committed by early decisions involving weight allocation, system complexity, redundancy, maintainability, and certification strategy; see Figure 29. Cost follows from design decisions, not from downstream accounting alone, and configurations that accept modest performance penalties in exchange for simplicity, robustness, and margin often prove more economical over their operational life.

An enduring reality of aircraft development is that programs almost always cost more than initially expected. This outcome reflects the difficulty of holding early cost assumptions constant as technical risk decreases and designs mature. As performance shortfalls, certification findings, and integration problems are uncovered, compensating changes propagate across multiple subsystems, driving both near-term growth in development costs and longer-term operating cost penalties.
As a design matures, early simplifying assumptions give way to physical detail, requirements accumulate, technologies evolve, performance margins erode, and tooling and manufacturing processes are established. Supply chain disruptions, highlighted in recent years following the COVID-19 pandemic, further amplify these effects. Individually, each change is usually reasonable; collectively, however, they drive weight growth, redesign effort, additional testing, and an expanded certification burden. The result is increased capital expenditures (CAPEX), the upfront costs required to develop, certify, produce, and place an aircraft into service with a customer (see Figure 30).

For most airplanes, CAPEX represents only a fraction of the aircraft’s total economic cost. Operating expenditure (OPEX), the recurring cost of operating the aircraft over its service life, is typically the dominant component and is driven primarily by fuel consumption, maintenance and inspections, spare parts, training, insurance, and downtime. Structural complexity, system integration, accessibility, material selection, and propulsion installation directly affect reliability, maintainability, and operational availability. Designs that aggressively minimize weight or drag may inadvertently increase maintenance complexity or reduce tolerance for operational variability, thereby raising OPEX over time. Conversely, an aircraft that is slightly heavier or less aerodynamically efficient can be more economical if it is simpler, more robust, and so easier to operate and maintain.
From an engineering perspective, aircraft cost is best viewed as the sum of several coupled contributions over the aircraft’s life. At the highest level, the total life-cycle cost may be written as
(62) 
Each term depends directly on design decisions made early in the program. Technical novelty, integration complexity, test scope, and certification effort drive development cost. Production cost depends on part count, material systems, tolerances, tooling concepts, and manufacturing rate. Operational cost is dominated by energy consumption, maintenance burden, reliability, and availability. Support cost includes spares, training, documentation, and long-term sustainment.
For aircraft that operate repeatedly over long service lives, operational costs will inevitably dominate. In simplified form, this can be expressed as
(63) 
where fuel use, maintenance burden, and downtime are strongly influenced by aircraft weight, drag, system complexity, and accessibility. Insurance can represent a significant component of operating costs, reflecting not only hull value but also third-party liability and, for manufacturers and operators, product liability exposure.
Because each cost component is linked to specific design choices, cost cannot be optimized independently of the configuration. Reducing one contribution often increases another. A lighter structure may reduce fuel cost while increasing manufacturing and inspection costs. A simpler configuration may incur a modest drag penalty while substantially reducing production and maintenance costs. These trade-offs explain why aircraft that are not optimal in any single metric frequently prove to be the most economical over their operational life. In this sense, cost is an emergent property of the configuration itself, not an external constraint imposed after design. Effective design manages cost indirectly by controlling weight growth, configuration complexity, integration quality, and design margins.
Unanticipated weight growth is a common example. Although early weight estimates are necessarily uncertain, designs that fail to account for this uncertainty often underperform and ultimately fail to meet key requirements. Late-stage analysis seldom rescues such designs and usually serves only to quantify the shortfall. The purpose of a structured design process is not simply to increase analytical fidelity, but to discipline the recognition of when choices become irreversible and when engineering judgment matters more than numerical precision. Understanding how and when design commitments are made is essential for applying the principles discussed in this chapter. These principles guide early decisions while the consequences of error are still manageable.
Unit airframe cost does not follow a single trend with gross take-off weight or wing loading, unlike the empty-weight fraction. Instead, historical aircraft are distributed across distinct cost bands associated with broad configuration and operational classes, as illustrated in Figure 31. Although unit airframe cost[3] is driven primarily by system content, integration complexity, and production context, gross takeoff weight provides a practical, consistent top-level sizing variable for comparing historical aircraft costs.

For civil aircraft, light single-engine and light twin airplanes occupy the lowest unit-cost region, reflecting relatively simple systems, low certification burden, and modest avionics integration. Turboprop commuter and utility airplanes fall into a higher-cost band, driven primarily by more complex propulsion systems, pressurization, de-icing, and increased redundancy and certification requirements. Business and regional jets fall into a substantially higher-cost category because of higher system density, stricter cruise-performance requirements, and more extensive avionics and environmental-control systems.
Large commercial transport airplanes occupy the highest civil unit-cost region. Although their structural efficiency improves with size, absolute unit cost is dominated by system scale, redundancy, integration effort, production tooling, and certification and quality-assurance processes. Production rate and total program quantity exert a strong influence through learning-curve and manufacturing-maturity effects.
Military aircraft operate under a separate, higher-cost regime. Trainer and light-attack aircraft occupy the lower end of the military cost range, while modern multirole fighters and specialized combat aircraft lie at the high end. In these aircraft, unit cost is driven primarily by mission systems, sensors, survivability features, software content, and integration complexity, as well as low production volumes. Military transport aircraft generally lie between these extremes, combining large structural scale with complex mission and certification requirements.
Powered-Lift & VTOL Design Principles
Powered-lift and vertical takeoff and landing (VTOL) aircraft occupy an intermediate design space between conventional airplanes and rotorcraft. They must generate lift without forward speed during takeoff and landing, but they must also transition to efficient wing-borne flight for cruise. This dual requirement creates a fundamental design compromise. The aircraft must carry enough installed power and lifting-system area to hover, yet it must also have sufficiently low drag, acceptable wing loading, and efficient propulsion to cruise as an airplane. Consequently, a powered-lift VTOL design is governed not by a single operating condition but by the need to satisfy requirements for hover, transition, climb, cruise, control, and failure cases with a single integrated configuration.
Disk Loading & Effective Lift-System Loading
The most important distinction is between vertical-lift operation and wing-borne flight. In hover, the lifting system must support the entire aircraft weight, so  , where is the total vertical thrust and is the aircraft weight. The corresponding disk loading, or more generally, the effective lift-system loading, is
(64) 
where is the total effective area over which the vertical-lift system acts. For a single rotor,  . For multi-rotor aircraft, such as coaxial, tandem, tiltrotor, or distributed electric VTOL configurations, is usually taken as the sum of the effective rotor disk areas, at least as a first approximation. For ducted fans, lift fans, vectored-thrust systems, and other powered-lift arrangements, should be interpreted as the appropriate effective lifting area for preliminary momentum-theory scaling. Disk loading is commonly expressed in lb ft
 in U.S. customary units or N m in SI units. It is sometimes quoted in kg m, although this is strictly a mass-equivalent form rather than a force per unit area.
From momentum theory, the ideal induced velocity in hover is
(65) 
where  is the induced velocity in hover; equivalently,
 for the hover condition. The corresponding ideal induced hover power is
(66) 
Therefore, for , the ideal induced hover power per unit weight is
(67) 
This expression gives the ideal induced-power scaling; it is not a complete powered-lift performance model.
The actual shaft, fan, jet, or electrical power required in hover depends on the particular vertical-lift system, including propulsor efficiency, installation losses, airframe download, inflow distortion, mechanical or electrical losses, control margins, and failure-case requirements. Nevertheless, the scaling shows why disk loading, or more generally, effective lift-system loading, is a central parameter in VTOL design. Low disk loading reduces induced hover power, downwash velocity, and often noise, but it requires large rotors, propellers, fans, or other lifting systems. High disk loading allows a more compact aircraft, but it also increases hover power, downwash velocity, noise, and installed power requirements.
Power Loading & Power-to-Weight
A related parameter is the power loading. For hover, where , it may be written as
(68) 
Power loading is commonly expressed as lb hp, N kW, or sometimes kg kW. For an ideal rotor,
(69) 
so a high power loading corresponds to a low induced velocity and a low disk loading. This result provides an immediate design interpretation. Aircraft with low effective disk loading, such as conventional helicopters with large rotors, require relatively little power per unit weight in hover and so have high power loading. Tiltrotors and many compact VTOL aircraft generally have higher disk loadings because their rotors are smaller relative to aircraft weight, resulting in lower hover efficiency. Jet-lift concepts have very high effective disk loadings because the lifting flow is produced through small exit areas at high jet velocities, resulting in much higher hover power requirements. These trends are shown schematically in Figure 32, where power loading decreases rapidly as disk loading increases across different classes of vertical-lift aircraft.

In wing-borne cruise, the aircraft behaves more like a conventional airplane. The wing provides most of the lift, and the propulsion system supplies the thrust needed to overcome drag. For steady, level cruise, , and
(70) 
where is the propulsive efficiency. Therefore, the cruise requirement favors low drag, high aerodynamic efficiency, and efficient propulsors. A design that is optimized only for hover may have excessive drag or poor propulsive efficiency in cruise, whereas a design optimized only for airplane-mode performance may require excessive installed power for vertical flight. The fundamental challenge of powered-lift VTOL design is to reconcile these conflicting requirements.
VTOL Configurations
Several broad classes of powered-lift VTOL configurations are possible. In a tiltrotor or tiltwing aircraft, the same propulsors provide vertical lift in hover and propulsive thrust in forward flight. This approach can give good cruise efficiency because the rotors or propellers are not idle in airplane mode, but the tilting mechanism introduces weight, mechanical complexity, aeroelastic issues, and demanding transition dynamics. In a lift-plus-cruise configuration, separate lift rotors are used for hover while a separate propulsor provides cruise thrust. This approach simplifies the transition and allows each propulsion system to be specialized, but the lift rotors become dead weight and drag in cruise unless they are carefully stowed, folded, stopped, or otherwise integrated. In a vectored-thrust aircraft, lift and propulsion are provided by deflecting the thrust from fans, rotors, or jets. This approach can be compact, but it often incurs high disk loading and, correspondingly, high hover power.
The transition between hover and forward flight is often the most critical part of the design. During transition, the aircraft must shift lift generation from the rotors or powered-lift system to the wing while maintaining adequate control authority in pitch, roll, and yaw. At low forward speeds, the wing may not yet provide enough lift, so the aircraft remains power-limited. At higher forward speeds, the rotors, propellers, or lifting jets interact with the wing, fuselage, and tail, producing complex aerodynamic interference. The transition corridor must avoid stall, loss of control, excessive attitude changes, propulsor inflow distortion, and insufficient control margin. A VTOL aircraft that can hover and cruise successfully may still be unacceptable if its transition behavior is fragile or requires excessive control-system intervention.
Disk Loading & Wing Loading
Wing loading remains important, but its role differs from that in a conventional airplane. A lower wing loading reduces stall speed and makes the transition to wing-borne flight easier, but it requires a larger wing, which may increase structural weight and cruise drag. A higher wing loading improves compactness and may reduce wing drag at higher cruise speeds, but it increases transition speed, takeoff and landing sensitivity, and the power required during conversion. Therefore, powered-lift aircraft must be sized using both disk loading and wing loading, i.e.,
(71) 
The disk loading governs hover power and downwash, while the wing loading governs stall speed, transition speed, gust response, and airplane-mode performance.
Installed power is usually driven by hover or vertical climb rather than cruise. For this reason, many VTOL aircraft have far more installed power than is needed for steady wing-borne flight. This excess power may be useful for climbing and maneuvering, but it also increases propulsion-system weight, cooling requirements, electrical-system rating, structural loads, and cost. For electric VTOL aircraft, the problem is especially severe because the battery must supply very high power during hover and transition, while also storing enough energy for the mission. The distinction between power and energy is central, i.e., hover sets the power requirement, whereas range and endurance set the energy requirement.
The power margin in hover is also a safety-critical design parameter. A practical VTOL aircraft must provide margin for vertical climb, gusts, control moments, degraded propulsor performance, hot-and-high operation, battery voltage sag, engine lapse, and possible failures. The hover thrust margin may be expressed as
(72) 
where is the fractional thrust margin. However, increasing this margin increases the motor, engine, inverter, transmission, wiring, thermal management, and structural weight. The resulting weight growth then increases the required hover thrust and power, creating a strong feedback loop.
Lessons Learned #5 – Convair XFY-1 Pogo and Lockheed XFV-1
Tail-sitter VTOL airplanes, such as the Convair XFY-1 Pogo and Lockheed XFV-1, were touted as ideal for achieving vertical takeoff and high-speed flight without complex lift systems. They appeared promising at the conceptual level. However, when flown, they incurred severe operational penalties, including limited payload and range, poor controllability, high pilot workload, and impractical ground handling. Although the aerodynamics and propulsion were technically feasible, the configuration conflicted with numerous other constraints. These issues could not be corrected without abandoning the basic concept.
Lesson learned: Tail sitters demonstrated the design dichotomy that vertical takeoff and high-speed airplane performance lie at opposite ends of the spectrum. Configurations that attempt to satisfy both extremes simultaneously are often subject to numerous unintended consequences. In that case, no amount of detailed refinement can recover the design without abandoning the underlying concept.
Other Design Issues
Control authority in hover and transition must be considered from the beginning. Unlike a conventional airplane, which uses aerodynamic control surfaces operating in a freestream, a VTOL aircraft at low speed must generate control moments primarily through differential thrust, rotor cyclic control, thrust vectoring, blown surfaces, reaction controls, or some combination of these methods. The required roll, pitch, and yaw moments depend on the propulsor layout, moment arms, inertia, center-of-gravity range, wind disturbances, and failure cases. A layout that satisfies total thrust may still be unacceptable if the propulsors do not provide adequate control authority about all axes.
Failure tolerance is another major design driver. The loss of a motor, rotor, propeller, fan, engine, actuator, or power bus can create not only a loss of lift but also a large unbalanced moment. Multirotor and distributed-propulsion configurations may provide redundancy, but only if the remaining propulsors have sufficient thrust margin and moment authority. These conditions become more difficult when the propulsors are closely spaced, when the center of gravity shifts, or when yaw moments from rotor torque are significant. In many VTOL designs, the failure case rather than the nominal hover case determines the required maximum thrust of each propulsor.
Downwash and ground interaction are also important. The induced velocity in hover scales as
(73) 
so high disk loading produces high downwash velocities. Strong downwash can create ground erosion, brownout or whiteout, recirculation, foreign-object ingestion, personnel hazards, and unfavorable aerodynamic interactions with the airframe. These effects are especially important for aircraft intended to operate near people, vehicles, buildings, ships, or confined landing areas. For urban air mobility and small-UAS applications, downwash and noise may become design constraints that are as important as power and performance.
Noise is closely tied to disk loading, tip speed, blade loading, and propulsor installation. Lower tip speeds and lower blade loading generally help reduce rotor and propeller noise, but they may require larger rotors or more blade area. Distributed propulsion can reduce individual propulsor loading, but it can also introduce tonal interactions, installation effects, and complex acoustic directivity. Because community noise can limit where VTOL aircraft can operate, acoustic design cannot be left as a late-stage refinement.
The structural and mechanical consequences of powered-lift design are substantial. Tilt mechanisms, lift rotors, pylons, booms, ducts, transmissions, batteries, high-voltage wiring, and thermal-management systems add weight and complexity. These components must carry large, concentrated loads during hover, transition, gusts, landing, and failure. They must also satisfy fatigue, vibration, and aeroelastic requirements. A configuration that appears feasible based on a simple thrust or power calculation may become unattractive once structural and mechanical integration penalties are accounted for.
For these reasons, powered-lift VTOL design is best understood as a simultaneous problem in disk loading, wing loading, installed power, control authority, and integration. The key early choices include the lifting-system architecture, total disk area, wing area, installed power, energy storage, propulsor placement, transition strategy, and failure tolerance. These choices strongly constrain the remainder of the design. A powered-lift VTOL aircraft with excessive disk loading, insufficient transition margin, poor propulsor integration, inadequate failure tolerance, or unacceptable downwash and noise will usually require a fundamental redesign rather than minor refinement.
Lessons Learned #6 – Lockheed Martin F-35 Lightning II
The F-35 program illustrates how ambitious requirements can interact in destabilizing ways. The mandate to satisfy conventional takeoff, carrier, and short takeoff/vertical landing (STOVL) missions within a single airframe imposed severe geometric, structural, and propulsion constraints early in the design. In particular, the STOVL lift-fan system dictated fuselage volume, center-of-gravity limits, and structural layout, which in turn affected wing loading and weight growth across all variants. While each requirement was individually reasonable, their combination produced strong couplings that drove redesigns, delays, and cost escalation.

Lesson learned: Design requirements form a coupled system. Early design must identify which requirements dominate the configuration and which may need revision once their physical consequences are understood.
Rotorcraft Design Principles
Rotorcraft design introduces a different set of early design commitments from those of fixed-wing airplanes. Whereas airplane design is strongly governed by wing loading, drag, and cruise efficiency, helicopter and rotorcraft design is dominated by rotor disk loading, installed power, transmission weight, control authority, vibration, and fatigue. The rotor must provide lift, control moments, and, in many configurations, propulsive force, so aerodynamic, structural, dynamic, and mechanical design choices are tightly coupled from the outset. Consequently, a rotorcraft design cannot be understood simply as an airplane with rotating wings; it is a distinct class of flight vehicle in which hover performance, forward-flight efficiency, stability and control, and mechanical complexity must be reconciled simultaneously.
Disk Loading
As discussed in the preceding section, disk loading is one of the primary parameters governing vertical-lift performance. For a helicopter, the disk loading is usually written as
(74) 
where is the rotorcraft weight and is the total lifting rotor disk area. A low disk loading reduces the induced velocity, hover power, downwash velocity, and often noise, but it requires a larger rotor. A higher disk loading permits a more compact aircraft, but it increases hover power, downwash, noise, and installed power requirements. Therefore, the choice of rotor disk area is one of the first and most consequential decisions in helicopter design.
Rotor Sizing
For a single lifting rotor, the required rotor radius follows directly from the selected disk loading, i.e.,
(75) 
For configurations with multiple lifting rotors, such as tandem, coaxial, intermeshing, or distributed-rotor arrangements, is the total effective lifting disk area. However, the rotor radius is rarely selected based on disk loading alone. It may be limited by ground clearance, hangarage, shipboard storage, blade structural weight, tip speed, autorotation requirements, vibration, noise, and the overall configuration layout. Therefore, the selected rotor radius represents a compromise between hover efficiency, aircraft size, structural weight, dynamics, and operational constraints.
After the rotor radius has been selected, the blade number, chord, solidity, twist, airfoil sections, and tip speed must be chosen to provide the required thrust with acceptable blade loading and control margins. The rotor solidity is commonly written as
(76) 
where  is the number of blades and is a representative blade chord. The rotor thrust coefficient is
(77) 
and the ratio  provides a useful measure of blade loading. Excessive blade loading leads to high blade pitch angles, increased profile losses, reduced stall margin, higher vibration, and poorer control authority. Increasing solidity can reduce blade loading, but it also increases blade weight, profile power, hub loads, and cost.
The rotor tip speed,  , is another critical early design choice. A higher tip speed reduces the blade loading required for a given thrust, but it increases compressibility effects, profile power, noise, and centrifugal stresses. A lower tip speed can reduce noise and compressibility losses, but it usually requires larger blade area, higher blade pitch, or a larger rotor. Therefore, tip speed is not merely an aerodynamic variable; it affects acoustics, structural design, rotor dynamics, hub loads, and transmission requirements.
In forward flight, the helicopter rotor operates in a highly nonuniform aerodynamic environment. The advancing blade experiences a higher relative velocity, while the retreating blade experiences a lower relative velocity. The advancing-tip Mach number may be estimated as
(78) 
where is the speed of sound. At the same time, the retreating blade must generate lift at lower dynamic pressure and may approach stall. These opposing limits, advancing-blade compressibility and retreating-blade stall, are fundamental reasons why conventional helicopters have restricted maximum speeds compared with fixed-wing airplanes. They also explain why high-speed rotorcraft often require compound configurations, auxiliary propulsion, slowed rotors, wings, or other design features to unload the rotor in forward flight.
Power & Weight
Rotorcraft design is also strongly affected by weight-power feedback. Increasing gross weight requires more rotor thrust, which increases hover and climb power. The higher power requirement increases the engine, motor, transmission, cooling, and fuel or battery weights, further increasing gross weight. This feedback loop is especially severe for helicopters because hover power is often a primary sizing condition. A first-order power breakdown for a helicopter in forward flight may be written as
(79) 
where  is the induced power,
 is the rotor profile power,
 is the parasite power associated with fuselage and external drag, and
 is the climb power. The parasite power increases rapidly with airspeed, i.e.,
(80) 
where  is the equivalent flat-plate area of the helicopter. Because helicopters typically have a higher parasitic drag area than an airplane of the same or similar gross weight, their parasitic power increases rapidly with airspeed.
For a conventional single-main-rotor helicopter, the anti-torque system introduces another coupled design requirement. The main-rotor torque is approximately  , where
 is the main-rotor shaft power, so the tail rotor must generate a side force of approximately
(81) 
where  is the tail rotor moment arm. The tail rotor consumes power, adds weight, produces noise, and affects handling qualities. It also imposes additional design requirements for yaw-control authority, crosswind operation, sideward flight, and low-speed maneuvering. Alternative rotorcraft configurations, including coaxial, tandem, intermeshing, compound, and tiltrotor arrangements, either redistribute or eliminate the conventional tail rotor requirement, but they introduce their own structural, mechanical, aerodynamic, and control-system penalties.
Other Design Issues
Autorotation is another design requirement that distinguishes helicopters from most other powered-lift aircraft. In autorotation, the rotor continues to turn because of the upward flow through the rotor disk during descent, allowing the pilot or control system to manage rotor speed and produce lift without engine power. The ability to autorotate depends on rotor inertia, blade aerodynamic characteristics, rotor speed limits, disk loading, control response, and aircraft operating conditions. Low disk loading and sufficient rotor inertia generally improve autorotative capability, whereas very high disk loading and low-inertia rotors can make safe autorotation more difficult. For this reason, autorotation must be considered early in helicopter design rather than treated only as an operational procedure.
Rotorcraft must also be designed for stability, control, vibration, fatigue, and aeroelastic safety from the beginning of the design process. The rotor is a rotating, flexible, highly loaded structure, and its dynamics are coupled to the fuselage, control system, transmission, and landing gear. Important design considerations include flap and lag motion, blade torsion, hub loads, mast bending, ground resonance, yaw-control authority, center-of-gravity range, and handling qualities. These issues cannot be postponed until detailed design because they are directly affected by early choices of rotor size, blade loading, tip speed, hub type, transmission rating, and control-system architecture.
Vibration and fatigue are especially important because the rotor system produces periodic aerodynamic and inertial loads. These loads are transmitted through the hub, mast, gearbox, airframe, and controls. Even when the average rotor thrust is steady, the individual blade loads vary with azimuth, forward speed, inflow, blade motion, and control inputs. The resulting vibratory loads affect passenger comfort, avionics reliability, structural fatigue life, maintenance cost, and airframe durability. Therefore, rotorcraft design requires careful attention to dynamic tuning, hub design, blade structural properties, damping, and fatigue-resistant construction.
For these reasons, successful rotorcraft design requires early attention to hover capability, disk loading, installed power, rotor radius, blade loading, tip speed, transmission rating, control authority, autorotation, vibration, and fatigue life. These requirements aren’t late-stage refinements. A rotorcraft with excessive disk loading, inadequate power margin, poor yaw-control authority, unacceptable vibration, insufficient autorotative capability, or inadequate fatigue life will usually require a fundamental redesign rather than a minor correction. Therefore, rotorcraft provide one of the clearest examples of why flight-vehicle design is a multidisciplinary synthesis problem rather than the sequential application of isolated aerodynamic, structural, or propulsion analyses.
Lessons Learned #7 – Lockheed AH-56 Cheyenne
The Lockheed AH-56 Cheyenne was one of the most ambitious attempts to extend helicopter performance beyond the limits of a conventional single-main-rotor configuration. Developed for the U.S. Army’s Advanced Aerial Fire Support System program, the Cheyenne was configured as a compound helicopter with a rigid main rotor, low-mounted wings, and a tail-mounted pusher propeller. The design goal was to combine the vertical-flight capability of a helicopter with much higher forward speed and improved armed-escort performance.
The Cheyenne demonstrated that simply adding wings and auxiliary propulsion to a helicopter does not remove the fundamental rotorcraft design problem. Instead, it redistributes the problem among the rotor, wing, propeller, controls, structure, and propulsion system. The rigid rotor, compound layout, high-speed requirement, and weapons mission produced strong couplings among rotor dynamics, vibration, stability and control, structural loads, and handling qualities. Although the aircraft was technically innovative, its complexity, development difficulties, and changing operational requirements ultimately prevented it from entering production.
Lesson learned: Compound helicopters can improve forward-flight performance only by introducing new system-level compromises. Wings and auxiliary propulsion may unload the rotor and increase speed, but they also add weight, drag, mechanical complexity, control interactions, and dynamic problems. A successful rotorcraft design must be judged not only by hover capability or maximum speed, but by the integrated behavior of the rotor, propulsion system, controls, structure, vibration environment, and mission requirements.
Spacecraft Design Principles
Spacecraft design differs from airplane design primarily in the way feasibility is constrained. For aircraft, performance emerges from the continuous balance of lift, drag, thrust, and weight, and shortfalls can often be mitigated through aerodynamic refinement, power upgrades, or operational adjustments. However, for spacecraft, feasibility is set almost entirely by the total mass, propellant fraction, and the velocity change achievable by the propulsion system, i.e.,  , which is dictated by the rocket equation and the laws of orbital mechanics. Once these quantities are fixed, the attainable mission is effectively determined, and later design refinement offers little opportunity to recover any shortfall in capability.
From a physical standpoint, this difference between the two types of flight vehicles arises because spacecraft propulsion changes the orbital state through discrete velocity increments, which directly modify orbital energy and angular momentum. An orbit is a dynamical free-fall trajectory governed by gravity and inertia, not a controllable trimmed equilibrium in the same sense as steady atmospheric flight. Consequently, spacecraft design is governed primarily by mass and energy accounting, while force and moment balances play their main role during powered maneuvers, attitude control, docking, landing, or atmospheric entry.
The Tyranny of the Rocket Equation
The central constraint in spacecraft design is not a particular technology per se, but the inescapable coupling between vehicle mass and the achievable mission. This coupling is expressed by the rocket equation, which was derived in another chapter of this eBook, i.e.,
(82) 
Here, is the achievable velocity change,  is the specific impulse of the propulsion system,
 is the standard gravitational acceleration at mean sea level,
 is the initial mass of the spacecraft, and
 is its final mass after the expenditure of propellant. Notice that the specific impulse is closely related to the reciprocal of thrust-specific fuel consumption, but the relationship depends on how TSFC is defined. If TSFC is defined on a fuel-weight-flow basis, i.e., fuel weight flow per unit thrust, then
(83) 
whereas if TSFC is defined on a fuel-mass-flow basis, i.e., fuel mass flow per unit thrust, then
(84) 
The rocket equation captures an immutable physical constraint on rocket performance and is analogous to the Bréguet range equation for airplanes. Its variables are the mass ratio and the effective exhaust velocity, which set the fundamental limits on attainable mission and vehicle sizing for rocket propulsion. These relationships remain the primary physical constraints on both launch and in-space vehicle performance. From a design standpoint, the rocket equation is dominated by its logarithmic dependence on mass ratio, i.e., relatively small increases in required can require large increases in propellant fraction, while reductions in dry mass directly improve the attainable payload or mission margin. This sensitivity makes mass control the dominant driver for spacecraft design.
The specific impulse, , in the rocket equation is a measure of how effectively a propulsion system converts propellant mass flow into thrust and is directly proportional to the effective exhaust velocity. Typical values for commonly used spacecraft propellants are summarized in the table below; the propellant type is part of the design choice. The units of are seconds, which is a direct consequence of its definition. A higher value of corresponds to a higher effective exhaust velocity,  , for a given mass flow rate,
 , and more efficient use of propellant, i.e.,
 , where
 .
| Propulsion class | Representative examples | Typical |
|---|---|---|
| Monopropellant chemical | Hydrazine thrusters | 210–230 s |
| Bipropellant chemical | NTO/MMH, LOX/LH |
300–340 s (storable) 430–455 s (LOX/LH ) |
| Solid rocket motors | Upper stages, kick motors | 260–290 s |
| Electric propulsion | Ion and Hall thrusters | 1,500–4,000 s |
| Nuclear thermal (conceptual) | Hydrogen nuclear thermal rockets | 800–950 s |
In practice, propulsion systems capable of very high values of are power-limited and operate at extremely low mass flow rates. Consequently, electric propulsion systems produce very low thrust despite their excellent propellant efficiency. In contrast, chemical propulsion systems operate at much larger mass flow rates and so generate high thrust at comparatively low values of . The wide spread in achievable values of illustrates why propulsion class selection is a fundamental configuration decision, not a tuning parameter; chemical systems provide high thrust at relatively low specific impulse, electric systems achieve extremely high specific impulse at very low thrust levels, and nuclear thermal propulsion (if realized operationally), would occupy an intermediate region of the configuration space.
The design consequence is that improvements in propulsion performance and reductions in dry (structural) mass are not equivalent trade variables. Meaningful increases in the value of generally require changes in propulsion technology, power generation, thermal management, and operational complexity. In contrast, any increase in dry mass directly reduces the attainable velocity increment for a fixed launch mass. Spacecraft design reduces primarily to the disciplined allocation of a tightly constrained dry-mass budget among structure, thermal control, power, avionics, and payload. The required propellant fraction follows from the rocket equation through
(85) 
so that
(86) 
where is the final mass after the propellant required for the maneuver has been expended. For typical orbital launch vehicles, the required implies that a very large propellant mass fraction is needed, leaving only a small remaining fraction to accommodate all of the structure, subsystems, and delivered payload. Payload fractions to orbit are typically low, often only a few percent of the launch mass, which is much lower than for many transport airplanes, where the useful payload fraction may be on the order of 20–30%.
Concepts such as staging, in-space refueling, and high-energy upper stages are used to reset the mass ratio by discarding inert mass or replenishing propellant. In this sense, the “tyranny” of the rocket equation must not be interpreted as a propulsion limitation. Instead, it provides a basis for implementing a hierarchy of design priorities in which early decisions on configuration and subsystem mass allocation dominate feasibility considerations long before detailed component design begins. Once these configurational commitments are made, the subsequent optimization and high-fidelity analysis can only refine a solution that is already tightly constrained by mass ratio.
Mass Fractions
The rocket equation shows that the achievable mission velocity depends on the mass ratio. For design work, however, it is more useful to express this relationship directly in terms of how the vehicle’s mass is partitioned among propellant, structure and systems, and payload, as is also done for an aircraft. For a single-stage vehicle, let
(87) 
where is the initial wet mass,  is the propellant mass,
 is the dry structural and systems mass, and
 is the payload mass. It is convenient to write these masses in terms of the corresponding mass fractions, i.e.,
(88) 
such that
(89) 
From a design perspective, these three fractions have different meanings. The propellant fraction represents the mass available to produce impulse and velocity increment, the structural fraction represents the technological and configurational burden of sustaining the stage, and the payload fraction represents the useful mission value.
For a single-stage vehicle, or for an isolated stage in which the carried upper-stage stack is treated as the payload, the final mass after the propellant is depleted is
(90) 
where denotes the payload or carried upper-stage stack for that stage. Therefore,
(91) 
This form highlights that the achievable velocity increment depends on the sum of the structural and payload fractions. The propellant fraction enters implicitly through the identity  . For a prescribed mission requirement and propulsion system,
(92) 
Therefore, the maximum payload fraction that a single stage can deliver is
(93) 
This expression makes the dominant design constraint explicit. For a fixed exhaust velocity, every increase in structural mass fraction directly reduces the available payload fraction. Improvements in propulsion performance enter through in the exponential term, whereas reductions in structural mass fraction enter directly into the payload allowance.
For a launch vehicle, it is common to characterize a stage by a structural mass coefficient, i.e.,
(94) 
which measures the structural and systems mass as a fraction of the stage mass excluding payload. Configurational and technological choices, such as tank type, materials, pressurization method, engine cycle, reusability hardware, thermal protection, and system architecture, largely determine this quantity.
Because
(95) 
the structural mass fraction may be written as
(96) 
The final-to-initial mass ratio is then
(97) 
and so
(98) 
This relationship shows how the stage structural coefficient and payload fraction jointly determine the mass ratio available to produce the required velocity increment.
In early design studies,  is best treated as a configuration parameter rather than as a freely tunable performance variable. As illustrated in Figure 33, historical data for operational launch-vehicle stages show that the stage structural coefficient, i.e.,
(99)
does not follow a simple monotonic trend with stage size, but instead generally occupies a fairly narrow band between about 0.05 and 0.15, with some reusable booster stages reaching values approaching 0.18. This outcome reflects that the stage structural coefficient is governed mainly by configuration, materials, propulsion system, reusability requirements, and stage role rather than by size alone.
 versus stage wet mass
 for operational launch-vehicle stages.
Expendable stages lie predominantly in the range 0.05–0.10, while reusable stages typically fall in the range 0.10–0.15. The corresponding payload fraction for complete launch vehicles to low Earth orbit (LEO) is typically only 2-5%. The stage structural coefficient serves as the direct launcher analog of the classical aircraft empty-weight fraction charts. Typical values of for various launch vehicles are listed in the table below.
| Vehicle Type | Typical Structural Mass Coefficient (ε) |
|---|---|
| Solid rocket stages | 0.09–0.12 |
| Liquid rocket stages (expendable) | 0.07–0.10 |
| Liquid rocket stages (reusable) | 0.10–0.15 |
| Upper stages (lightweight) | 0.04–0.08 |
| Heavy-lift first stages | 0.08–0.12 |
| Reusable boosters (e.g., Falcon 9 first stage) | 0.12–0.18 |
For LEO missions, the effective velocity requirement, including losses, is on the order of  . For representative chemical propulsion systems, the resulting exponential term
 is typically only about 0.06 to 0.12. Consequently, the sum
 must be very small. In practical terms, once a realistic structural fraction is allocated to tanks, engines, avionics, thermal protection, and recovery hardware, the remaining payload fraction for a single stage is only a few percent. This is the fundamental reason single-stage-to-orbit concepts are primarily limited by the achievable structural mass fraction rather than by propulsive efficiency.
Taken together, the stage-level and vehicle-level mass-fraction data show that launch-vehicle performance is governed primarily by configuration rather than by scale. The corresponding system-level outcome is shown in Figure 34, which plots the payload fraction to LEO,  , as a function of vehicle liftoff mass. As with the stage structural fraction, no clear dependence on vehicle size is observed. Instead, operational launch vehicles occupy a narrow envelope, with typical payload fractions to LEO of only a few percent, most commonly in the range
 2–5%. Nevertheless, larger and heavier launch vehicles can deliver larger absolute payload masses, even though their payload fractions do not necessarily increase with vehicle size.

 , against vehicle liftoff mass,
Together, Figures 33 and 34 demonstrate that neither increasing vehicle size nor incremental improvements in component performance fundamentally change the achievable payload fraction. Feasibility is primarily determined by the configuration, staging strategy, propulsion class, and the configurational burden of the structure and recovery systems, rather than by scale. In this sense, these mass-fraction data play the same role for launch vehicles as classical empty-weight and payload-fraction charts do in airplane design. However, unlike for airplanes, they define historical feasibility bounds, and do not establish predictive scaling laws.
Staging, Configuration, & Irreversibility
Because of the exponential penalty on imposed by the rocket equation, staging is a primary means of managing the mass ratio of launch vehicles. By discarding the remaining inert structure, such as a burned-out first stage or solid rocket boosters, staging enables a substantially larger mission value, , than propulsion performance improvements alone. However, this capability comes at the cost of additional structural interfaces, separation systems, guidance and control complexity, and operational risk.
Launchers
From a design principles perspective, staging represents one of the most irreversible configuration commitments in launch-vehicle design. The number of stages, their engine and propellant combinations, and their sequencing fix overall vehicle geometry, load paths, tank and engine integration, guidance and navigation systems, ground operations, and mission design. These choices rapidly become embedded across multiple subsystems and interfaces. The Space Shuttle, as shown in the cutaway drawing in Figure 35, used a three-element launch stack consisting of the reusable Orbiter, the expendable external cryogenic tank, and two recoverable solid-rocket boosters. The solid-rocket boosters separated during ascent, and the external tank was jettisoned later, while the Orbiter continued to orbit and returned for reuse. This configuration fixed the vehicle’s structural load paths, propulsion integration, ascent guidance strategy, launch infrastructure, and refurbishment processes. It was a highly constrained design solution shaped by the mission requirements, reusability goals, payload requirements, cross-range requirements, budget limits, and available technology.

For a multistage launcher, the total velocity increment is the sum of the contributions from the individual stages, i.e.,
(100) 
The crucial effect of staging is the removal of inert mass after each stage has completed its work. When a stage is separated, its tanks, engines, structure, and associated systems are no longer carried by the remaining stages, so the continuing vehicle begins the next stage with a newly established mass ratio. Staging is therefore a configurational mechanism for repeatedly discarding inert mass rather than carrying it throughout the entire mission.
For an isolated stage assigned a velocity increment , let  be the structural and systems mass of that stage divided by its initial mass, and let
 be the mass fraction of the payload or upper-stage stack carried above it. At burnout,
(101) 
Therefore, the maximum carried-mass fraction is
(102) 
This relation provides a direct stage-level feasibility check. If the structural fraction implied by the selected configuration exceeds the mass allowance established by the mission velocity requirement and propulsion system, no amount of detailed optimization can recover the desired carried mass. In launch-vehicle design, structural mass fraction is a primary configurational limiter, and staging is the principal means of reducing the inert mass carried through the complete ascent.
In-Space Spacecraft
For spacecraft operating beyond the launch phase, an analogous configuration commitment arises in selecting the primary propulsion system. High-thrust chemical propulsion, electric propulsion, and hybrid configurations occupy fundamentally different regions of the configuration space. High-specific-impulse systems reduce propellant mass, but require long thrust durations and impose significant power, thermal, and operational constraints. These trade-offs cannot be resolved through parameter optimization alone and must be aligned with mission objectives, timelines, and operational concepts at the outset of the design process.
A mission to Mars illustrates how a small number of early decisions determine whether a spacecraft concept is feasible. The total mission must be allocated to Earth departure, mid-course corrections, and Mars arrival, either by propulsive capture or by atmospheric entry. For a minimum-energy transfer, the departure burn from low Earth orbit is on the order of 3.5–3.8 km/s, while Mars orbit insertion may require approximately 1 km/s if performed propulsively. Because the required mass ratio scales exponentially with through the rocket equation, even modest changes in the allocation can produce large increases in  and, for a fixed delivered mass, in the launch mass. This allocation immediately determines the staging approach and the propulsion architecture, whether based on high-thrust chemical propulsion, low-thrust electric propulsion, or a hybrid of the two. Those choices, in turn, set the required thrust level, electrical power system size, thermal-control capability, transfer time, and operational concept long before detailed subsystem design begins.

A solar electric propulsion transfer can achieve specific impulses several times higher than those of conventional chemical systems, commonly ranging from roughly three to more than ten times higher depending on the propulsion systems being compared, thereby substantially reducing the required propellant mass for a specified ideal velocity increment. However, the thrust levels are very low, which extends transfer times to many months and requires very large solar arrays, power-processing units, and radiator systems to reject waste heat. Longer transit times increase life-support mass and crew radiation exposure approximately in proportion to mission duration. In contrast, a high-thrust chemical transfer permits shorter travel times, reducing consumables and radiation dose, but only at the cost of very large propellant fractions, cryogenic tankage, boil-off management, and often multiple heavy-lift launches with on-orbit assembly. Once a Mars transfer approach is selected, the overall spacecraft layout, structural arrangement, shielding strategy, and mission timeline are largely fixed because these systems scale directly with propulsion architecture and trip duration.
The key design lesson is that missions of this type are governed primarily by mass fraction and energy requirements, not by incremental subsystem refinement. Because drives the mass ratio exponentially and transfer time drives life-support and radiation mass approximately linearly with duration, feasibility is established at the mission concept stage. Small improvements in propulsion efficiency or structural weight cannot compensate for a poorly chosen architecture. Mars missions, therefore, provide a clear example of a general spacecraft design principle, i.e., the dominant constraints are set by early decisions about propulsion type, staging, and mission profile, long before detailed optimization begins.
Design Task: Sizing of a small spacecraft for a LEO mission
Consider a small spacecraft intended for a low Earth orbit (LEO) mission. The spacecraft is assumed to be injected directly into its operational circular orbit by the launch vehicle at an altitude of 500 km. Only the spacecraft’s on-orbit propulsion system is sized in what follows. All masses and the budget are defined at the start of on-orbit operations, immediately after separation from the launcher and before any onboard propellant is used. A workable set of day-one requirements is a payload mass of 20 kg, a mission budget of 350 m/s (for orbit maintenance, collision avoidance, attitude management, and contingencies), and a minimum average on-orbit electrical power of 150 W. A conventional pressure-fed monopropellant propulsion system is selected for simplicity and robustness, with an effective specific impulse of 220 s.
A first-cut mass budget can be constructed immediately because spacecraft feasibility is dominated by mass allocation and by how the propellant fraction propagates through the rocket equation. Let the spacecraft mass at the start of on-orbit operations be  and
 where is the onboard propellant mass and
 includes all non-propellant items. Representative day-one estimates for a small LEO spacecraft might be a bus mass of 25 kg (power, avionics, harness, thermal) and a structural mass of 15 kg (primary structure, mechanisms, margins). Then
 kg. The propellant mass required to meet the budget is obtained from the rocket equation, i.e.,

leading to

with = 9.81 m/s2. For = 350 m/s and = 220 s, then

Therefore,  = 70.6 kg and
 10.6 kg. This closes a first-cut in-orbit wet-mass estimate of roughly 71 kg with about 11 kg of propellant.
Now consider a common design failure mode. Suppose late payload growth and “small” subsystem additions increase the dry mass by only 8 kg (for example, more capable payload electronics, added shielding, a larger antenna, and additional harness), so that the dry mass becomes 68 kg. If the mission requirement remains unchanged, the rocket equation forces the same mass ratio, i.e.,  80.0 kg and
 12.0 kg. Even though the dry mass grew by 8 kg, the wet mass grew by about 9.4 kg, and the propellant grew as well. If, as often happens, the budget also increases late (for example, because of more frequent collision-avoidance maneuvers, tighter pointing requirements, or a longer operational life), the mass growth accelerates. For example, if increases from 350 m/s to 500 m/s with a dry mass of 68 kg, then

and  85.8 kg and 17.8 kg. A seemingly modest increase in the requirement has driven a large increase in propellant, which in turn propagates into tank volume, structure, thermal control, and launch constraints.
Design outcome notes:
- For spacecraft, the achievable value of drives the propellant mass requirement through an exponential mass-ratio relationship rather than a linear energy balance.
- Dry-mass growth is positively harmful: it increases total mass directly and also increases required propellant for the same .
- Early commitments to the mission , propulsion type (), and margin policy strongly determine feasibility long before a high-fidelity analysis becomes warranted.
Structural & Thermal Constraints
Unlike aircraft, which experience sustained aerodynamic loads during flight, spacecraft structures are subjected to extreme launch environments and long-duration thermal effects in orbit. Launch imposes high axial and lateral accelerations, acoustic loading, and vibration, while on-orbit operation introduces large thermal gradients driven by solar illumination and internal heat dissipation. These conditions will dominate the structural sizing and material selection for the spacecraft.

Consequently, spacecraft structures often appear inefficient when judged by aircraft standards. Structural mass is allocated primarily to stiffness, dimensional stability, thermal isolation, robust load paths, and the support and restraint of spacecraft components during launch and on-orbit operation. From a design perspective, this apparent inefficiency is a direct consequence of operating in an environment where inspection, repair, modification, and rescue are either extremely limited or impossible.
For spacecraft that must return to Earth or otherwise fly through an atmosphere of another planet, thermal constraints are further dominated by atmospheric reentry. Aerodynamic heating during entry and descent imposes extremely high transient heat fluxes and surface temperatures that far exceed those encountered in on-orbit thermal control. The resulting requirement for a dedicated thermal protection system strongly influences external geometry, structural integration, allowable load paths, and material selection. Reentry protection is a major subsystem that must be integrated with the primary structure and with guidance and trajectory design from the earliest stages of configuration development. New protection systems continue to be developed that are thermally effective and also lightweight.
Therefore, thermal control becomes a first-order design driver for a spacecraft. Surface coatings, insulation strategies, and component placement strongly influence the vehicle’s geometry, mass distribution, and structural layout. As with propulsion integration and reentry protection, thermal design decisions will affect multiple subsystems and are difficult to change late in development, reinforcing the need for early, system-level consideration.
Spacecraft Testing & Verification
Unlike aircraft, which can be progressively refined through flight testing and operational envelope growth, spacecraft must be verified largely before launch. Once in orbit, hardware cannot normally be physically accessed, repaired, reconfigured, or re-instrumented for detailed fault isolation. Consequently, spacecraft testing is fundamentally oriented toward verification and risk reduction. Ground test programs are dominated by qualification and acceptance testing, including structural load testing, vibration and acoustic environments, thermal-vacuum cycling, electromagnetic compatibility testing, and end-to-end functional verification. These tests are intended to demonstrate functional integrity under expected and off-nominal environments, not to refine or optimize performance.
A central design concern is that no combination of ground tests can fully reproduce the coupled mechanical, thermal, electrical, and operational environment experienced during spaceflight. Interactions among subsystems, deployment mechanisms, avionics and software, and power and thermal control are only partially exercised in isolation. Therefore, verification must rely on a combination of analysis, subsystem testing, integrated system testing, and conservative margin policies. Testing reduces uncertainty, but it cannot compensate for configurational weaknesses or incorrect early assumptions about mass, power, thermal balance, or operational concept. From a design-principles perspective, spacecraft testing primarily serves to confirm that a fundamentally sound spacecraft, considered as an integrated system, will survive its harsh environment. It cannot rescue a design that only marginally meets the requirements, reinforcing the need for conservative design decisions from the outset and disciplined system-level verification planning.

For some classes of spacecraft, particularly reusable launch systems, a significant portion of the remaining system-level risk can only be mitigated through integrated full-scale testing, which necessarily includes flight testing. While SpaceX makes the recovery of its Falcon 9 booster look easy, it is far from it, and many test launches were needed to make it work. Another example is SpaceX’s Starship development program. Because the fully coupled flight environment of a reusable, super-heavy launch system cannot be replicated on the ground, the program deliberately relies on integrated flight testing to expose interactions among structures, propulsion, guidance and control, thermal protection, and ground systems. Ground testing remains essential for qualifying individual components and subsystems, but only integrated flight testing can reveal the coupled configurational weaknesses. Even in this highly iterative and hugely expensive approach, flight testing does not replace disciplined early configurational design decisions; its primary role is to uncover and retire system-level integration risks that cannot be eliminated analytically or with ground-based facilities.
Design Failure Modes
Although modern spacecraft are designed and verified by using mature analysis methods and extensive ground testing, experience shows that failures in spacecraft programs still occur and are most often driven by a small number of recurring system-level weaknesses. In practice, designs most commonly fail because of violations of fundamental constraints established early in the design process. Because spacecraft operate with narrow mass, power, and thermal margins and offer limited opportunities for in-flight correction, these failure modes are rarely correctable without major redesign. A notable exception was the Hubble Space Telescope in which the optical flaw could be remedied only because the observatory was deliberately designed for on-orbit servicing and a human spaceflight capability with the Space Shuttle existed to support multiple repair missions. This combination, however, is highly unusual. For most spacecraft, no comparable access, tooling, or operational infrastructure exists, and design deficiencies discovered after launch will become permanent limitations rather than recoverable faults.
From a design principles perspective, successful spacecraft are characterized by early design decisions that explicitly acknowledge irreversibility. Detailed analysis refines and validates a viable concept, but it cannot rescue a fundamentally flawed system configuration. The most common spacecraft failure modes to be aware of include:
- Underestimation of dry mass. Structural mass, harnessing, avionics, thermal hardware, mechanisms, and shielding are routinely underestimated in early concepts. Because spacecraft performance is strongly coupled to launch mass and propellant fraction, even modest dry mass growth can quickly render launch, orbit, or mission-duration requirements infeasible.
- Overly optimistic assumptions about propulsion performance and launch payload. Early designs frequently rely on best-case values for specific impulse, thruster efficiency, duty cycle, and available launch capability. When realistic off-nominal performance, degradation, and operational constraints are introduced, the resulting
 or payload shortfall can invalidate the mission configuration.
- Insufficient margin for thermal or power systems. Spacecraft frequently fail to allocate adequate margin for eclipse duration, seasonal beta-angle effects, component aging, and contingency operating modes. Thermal control and electrical power systems are tightly coupled to mass, surface area, and configuration, and deficiencies in these subsystems are often difficult to correct once the external geometry and layout are fixed.
- Configurational choices misaligned with mission timelines. Decisions such as orbit selection, communication geometry, autonomy level, redundancy philosophy, and servicing assumptions can be incompatible with the actual mission duration, operational concept, or development schedule. These mismatches are fundamentally configurational and typically emerge only when operations and lifecycle scenarios are examined in detail.
Lessons Learned #8 – Apollo 13 service module oxygen tank failure
The Apollo 13 mission exposed the consequences of latent design vulnerabilities embedded through incremental changes, incomplete systems understanding, and insufficient consideration of off-nominal operating conditions. Modifications to the service module oxygen tanks, including changes in materials, internal components, and ground-handling procedures, introduced failure modes that were not fully re-evaluated at the system level. A seemingly routine in-flight operation triggered a cascade of failures, causing the loss of service-module oxygen and fuel-cell electrical power, forcing the crew to power down the command module and rely on the lunar module for life support and trajectory correction. Although the crew survived thanks to exceptional engineering ingenuity and coordination, the Apollo 13 accident was rooted in engineering decisions that allowed latent design vulnerabilities to persist. Incremental hardware modifications, inadequate reassessment of off-nominal operating conditions, and incomplete system-level validation meant that tightly coupled spacecraft subsystems could amplify a seemingly minor design oversight into a mission-threatening failure.
Lesson learned: In tightly integrated spacecraft systems, engineering decisions that defer or fragment system-level revalidation can embed latent hazards. Operational skill may mitigate the consequences, but it cannot substitute for disciplined systems engineering and comprehensive verification of coupled subsystems.
Contrasts with Airplane Design
The contrast between airplane and spacecraft design is clearest when examining how performance responds to design errors and the extent of operational flexibility. An airplane operates in an atmosphere and continuously generates lift. If weight or drag is higher than anticipated, the penalties typically appear as increased fuel burn, reduced climb margin, or reduced payload or range. In many cases, however, the aircraft can remain operable by adjusting operating altitude, speed, range, or payload. In this sense, airplane design permits continuous adjustment, and modest design errors can sometimes be mitigated operationally.
By contrast, spacecraft performance is governed by the rocket equation, which imposes a strict exponential dependence on mass fraction. Any increase in inert mass directly reduces the achievable velocity increment. Unlike an airplane, a spacecraft has relatively little operational flexibility to compensate for excess mass after launch. If the available is insufficient for the specified mission, feasibility can be recovered only by changing the mission itself, such as reducing payload, lowering the required , changing the target orbit or trajectory, or reducing maneuver reserves. Consequently, spacecraft design operates in a regime of discrete commitment, in which early mass allocation decisions dominate outcomes. This difference explains why experience gained in atmospheric flight does not transfer directly to spaceflight. Once propellant fractions and inert mass are fixed, subsequent refinements offer only limited opportunities for recovery.
Cross-Regime Design Lessons
Despite the obvious differences between airplanes and spacecraft, a small set of design lessons applies across essentially all flight regimes and vehicle classes.
- Early commitments dominate outcomes. Configuration, materials, propulsion concept, and basic operational assumptions fix most of the achievable performance, cost, risk, and development difficulty long before detailed analysis or optimization is undertaken.
- Weight growth is the most common failure mechanism. Underestimation of structural, systems, and integration mass leads directly to reduced payload, degraded performance, eroded margins, and higher cost, and frequently forces late and disruptive design changes in both aircraft and spacecraft programs.
- Subsystem coupling is unavoidable. Aerodynamics, structures, propulsion, power, thermal control, avionics, and operations are tightly linked, and improvements in one area almost always introduce constraints or penalties elsewhere.
- Margins enable successful design. Mass, power, and performance margins protect against modeling uncertainty, manufacturing variability, operational growth, and evolving mission requirements, and are a practical prerequisite for successful development and long-term viability.
These lessons are not tied to any specific technology or era. They reflect persistent physical, organizational, and operational realities that govern the design, development, and operation of complex aerospace systems. They apply equally to conventional aircraft, electric and hybrid vehicles, spacecraft, and future concepts whose detailed technologies may evolve, but whose fundamental constraints and interdisciplinary nature do not. Ignoring these realities usually shifts risk rather than eliminating it, and delays its discovery to the most expensive and least correctable stages of a program.
eVTOL Design Considerations
Electric vertical takeoff and landing (eVTOL) aircraft are a specialized class of powered-lift vehicle. Therefore, the general design principles associated with disk loading, wing loading, hover power, transition, control authority, downwash, noise, and failure tolerance developed previously also apply. The distinguishing design issues for eVTOL aircraft arise primarily from the use of batteries, electric motors, inverters, high-voltage distribution systems, distributed propulsion, and electrically mediated control allocation.
Many eVTOL concepts must transition between rotor-borne and wing-borne flight. The aerodynamic and control challenges of this transition have already been discussed, but electric propulsion introduces additional constraints associated with transient power demand, voltage sag, motor and inverter limits, thermal loading, and fault-tolerant distribution of electrical power. Consequently, an eVTOL aircraft must be designed as an integrated aerodynamic, propulsion, electrical, thermal, and control system.

A central distinction in eVTOL design is the difference between power and energy. Hover and transition are usually power-critical, requiring large short-duration electrical power output. Range and endurance are energy-critical, requiring sufficient stored battery energy. These two requirements do not scale in the same way. A battery system may contain enough energy for the mission but still be unable to deliver the required peak power without excessive voltage sag, heating, or degradation. Conversely, a battery sized for high peak power may carry more mass than is justified by the cruise energy requirement. Therefore, eVTOL feasibility depends on both battery specific energy and specific power, as well as the thermal and electrical limits of the complete propulsion system.
The installed electrical power must exceed the shaft power required by the propulsors. Electrical losses occur in the battery, cabling, contactors, power-distribution units, inverters, motors, and gearboxes, if used. Therefore, the battery power required may be written schematically as
(103) 
where  is the total shaft power delivered to the propulsors and
 is the combined efficiency of the electrical powertrain between the battery and the propulsor shafts. If the aerodynamic efficiency of the lifting propulsors is represented separately by their figure of merit, then it should not also be included in .
During hover and transition, the electrical power demand and associated waste heat can be substantial. Thermal management is therefore a first-order design requirement rather than a secondary installation detail. Battery temperature, motor and inverter temperature, cooling-system capacity, and allowable component duty cycles can directly constrain hover time, vertical climb, repeated operations, and turnaround time. A vehicle may have sufficient nominal installed power but still be unable to sustain the required mission profile because of thermal limitations.
Battery sizing must account for usable energy rather than nominal stored energy. If  is the nominal battery energy and is the usable fraction after accounting for state-of-charge limits and reserves, then
(104) 
The usable fraction is less than unity because deep discharge accelerates battery degradation and because a reserve must be retained for contingencies, diversion, repeated landing attempts, or degraded-system operation. The battery must also satisfy the peak-power requirement, which may be written as
(105) 
where  is the maximum electrical power required during hover, transition, vertical climb, control transients, or failure conditions.
The distinction between battery specific energy and specific power is central to eVTOL sizing. Specific energy determines the battery mass required to store the mission energy, whereas specific power determines whether the battery can supply the required peak power without excessive voltage sag, heating, or loss of life. A battery optimized for high specific energy may have insufficient power capability, while one optimized for high specific power may carry more mass than is justified by the mission energy requirement. Consequently, the battery is sized by the more restrictive of the energy and power conditions.
Transient operating conditions can be more restrictive than steady hover or cruise. During transition, the aircraft may require substantial rotor-borne lift while simultaneously accelerating, maintaining attitude, and overcoming increased aerodynamic interference. The electrical system must supply this power without violating battery-current, voltage, motor, inverter, or thermal limits. The duration and sequence of these transients must be included in the mission power profile rather than represented by a single steady power value.
Distributed electric propulsion can provide useful control moments, packaging flexibility, and redundancy, but it also introduces substantial integration penalties. Multiple propulsors require motors, inverters, wiring, structural supports, cooling paths, sensors, fault-detection logic, and control allocation. The resulting system must be treated as an integrated propulsion-control-airframe architecture rather than as a collection of independent propellers attached to an airframe.
A larger number of propulsors does not automatically provide fault tolerance. The loss of a motor, propeller, inverter, battery module, power bus, actuator, or control channel can produce both a reduction in lift and a large unbalanced moment. The remaining propulsors must provide sufficient total thrust and sufficient roll, pitch, and yaw moments while remaining within their individual power, thermal, and structural limits. In many eVTOL configurations, the degraded or propulsor-out condition determines the required maximum rating of each remaining propulsor rather than the nominal hover condition.
The electrical architecture must prevent a single failure from disabling an unacceptable fraction of the propulsion system. Battery modules, buses, contactors, inverters, and control channels may therefore require physical and electrical segregation. However, redundancy increases mass, wiring complexity, cooling requirements, part count, inspection burden, and certification effort. True redundancy requires independent failure paths, not merely multiple components connected to a common battery, bus, cooling loop, or control computer.
Control allocation is also a central design issue. At low airspeed, conventional aerodynamic control surfaces may be ineffective, so the flight-control system must generate moments through differential thrust, thrust vectoring, rotor cyclic control, blown surfaces, or combinations of these methods. The available force and moment set depends on propulsor placement, thrust margin, moment arms, center-of-gravity location, actuator limits, and system failures. A configuration may have sufficient total thrust to hover but still lack adequate control authority throughout the transition corridor or after a propulsor failure.
The high-voltage electrical system introduces hazards that are not present in conventional mechanically driven propulsion systems. The design must address electrical isolation, insulation breakdown, arcing, electromagnetic compatibility, lightning effects, thermal runaway, crash damage, and safe shutdown. Batteries and high-voltage components must be located, restrained, cooled, monitored, and protected so that a local failure does not propagate through the aircraft or compromise occupied and mission-critical volumes.
Battery thermal runaway is especially important because the stored energy remains onboard throughout the mission. Unlike fuel, battery mass does not decrease during flight, and damaged cells may continue to generate heat after electrical isolation. Battery containment, venting, separation, fire resistance, and post-crash accessibility must therefore be considered during configuration development. These requirements can impose significant mass and volume penalties that should not be deferred until detailed design.
The structural and integration penalties of eVTOL configurations can be substantial. Lift propulsors, booms, pylons, tilting mechanisms, ducts, batteries, high-voltage wiring, cooling systems, inverters, and redundant control paths add mass and complexity. These components must carry concentrated loads during hover, transition, gusts, landing, and failure cases. They must also satisfy vibration, fatigue, crashworthiness, maintainability, electromagnetic-compatibility, and certification requirements. A configuration that appears feasible from a simple hover-power calculation may become unattractive after these integration penalties are included.
Noise remains an important design constraint, but electrically driven propulsors are not inherently quiet. The absence of combustion and mechanical transmission noise does not eliminate rotor or propeller noise. Tip speed, blade loading, blade number, inflow distortion, wake interaction, and propulsor-airframe interference remain important. Distributed propulsion may reduce the loading on each propulsor, but it can also create multiple tonal sources and complex acoustic interactions. The electrical propulsion architecture must therefore be evaluated for its system-level acoustic consequences rather than assumed to provide an automatic noise benefit.
A further difficulty in the eVTOL sector is the widespread “build-and-fly” mentality rather than a disciplined design-build-fly process. Early flight demonstrations are sometimes used to justify configuration choices before coherent analyses of performance, loads, controllability, thermal limits, noise, and failure cases have been completed across the operating envelope. Flight testing is valuable for risk reduction, but it cannot substitute for systematic configuration definition, interface control, and regime-by-regime sizing. Delaying the discovery of fundamental integration or transition-flight limitations until hardware has been committed makes corrective action expensive, schedule-critical, or infeasible.
Lessons Learned #9 – Distributed propulsion in eVTOL concepts
Distributed propulsion has become one of the defining features of many eVTOL concepts. It can provide useful design freedoms, including compact packaging, differential-thrust control, redundancy, and lower individual propulsor loading. However, it also replaces a mature single- or dual-rotor lifting system with a tightly coupled network of propulsors, power electronics, structural supports, thermal paths, fault-detection logic, and control allocation. The resulting integration problem can become the dominant design driver.
The Wisk Cora, originally developed by Kitty Hawk Corporation, provides a useful example. The aircraft used multiple electrically driven lift propellers together with a separate cruise propulsor. Although the concept demonstrated vertical takeoff, transition, and wing-borne flight, it also illustrates the broader challenge of certifying and operating a distributed-propulsion aircraft as a robust transportation system rather than as a demonstrator. The technical burden lies not only in making the aircraft fly, but in proving that its propulsion, electrical-power, control, redundancy, thermal-management, and failure-management architecture can meet operational and certification requirements.

Lesson learned: Distributed electric propulsion should not be adopted as a default strategy for vertical-lift aircraft. Unless it provides a clear system-level benefit, such as improved safety, reduced noise, greater control authority, or an operational capability that cannot be achieved more simply, it primarily increases mass, integration complexity, and verification burden compared with more established vertical-lift solutions.
For these reasons, eVTOL design is best understood as a simultaneous problem in power, energy, thermal management, electrical architecture, control authority, redundancy, acoustics, structural integration, and certification. The key early choices include the battery technology, usable energy fraction, installed electrical power, propulsion architecture, bus topology, cooling concept, propulsor placement, control-allocation strategy, and failure-tolerance requirements. An eVTOL aircraft with inadequate peak power, insufficient usable energy, weak thermal capacity, poor electrical segregation, inadequate control authority, or unacceptable integration penalties will usually require fundamental redesign rather than minor refinement.
Common Design Fallacies
Across both airplane and spacecraft design, history shows that certain misconceptions recur with remarkable persistence, even with established aerospace companies. These fallacies are rarely the result of poor analytical skills. More often, they arise from misinterpreting what a given analysis method can and cannot reveal once irreversible configuration commitments have already been made. Among these, the rampant misuse and over-interpretation of CFD is the most common and most damaging. High-fidelity CFD can refine local flow predictions and support detailed design. Still, it cannot rescue a fundamentally poor configuration, compensate for inappropriate early assumptions, or substitute for sound low-order modeling during conceptual design. Identifying such errors explicitly provides a useful perspective for interpreting the preceding material and offers durable guidance that extends beyond any particular vehicle class.
“Higher fidelity models will solve the problems”
Improved modeling fidelity can reduce prediction uncertainty, but it does not eliminate design uncertainty. High-fidelity simulations often reveal previously hidden sensitivities, increasing perceived risk. Design judgment lies not in producing the most detailed model but in knowing which effects must be modeled accurately and which can be conservatively bounded. Many unsuccessful designs fail not because the models were inaccurate, but because the designers used them to answer the wrong questions.
Conceptually, CFD misuse is analogous to other cases in which engineers relied on analytical or computational assumptions without sufficient validation against reality. For example, the Boeing 737 MAX MCAS logic contributed to fatal accidents after the aircraft encountered conditions and combinations of failures that were not adequately accounted for in the system design, validation, training, and certification processes. Similarly, the Ariane 5 maiden flight failure resulted from the reuse of software assumptions that were not valid in the new vehicle’s operating regime. These cases underscore that any computational or automated system must be applied within its validated domain and coupled with empirical evidence and disciplined system-level verification.
“More power will fix it”
One of the most common design fallacies is the belief that inadequate performance can be corrected by increasing installed power or thrust. While additional propulsion capability may improve specific metrics such as climb rate or acceleration, it rarely rescues a fundamentally flawed configuration. For airplanes, increased power almost always leads to greater weight, higher fuel consumption, and increased parasitic drag, eroding the very margins it is intended to restore. For spacecraft, additional propulsion capability is constrained primarily by mass-fraction limits and launch-vehicle capacity, leaving little room for corrective action. In both cases, propulsion adjustments can compensate for small design deficiencies, but they cannot reverse poor early commitments in weight, drag, or overall system configuration.
A well-known example is the early development of the F-35B short-takeoff and vertical-landing variant. As weight growth during detailed design accumulated, the available thrust and lift margins for vertical operations eroded rapidly. The resulting shortfall could not be solved simply by adding more engine power, because higher thrust would have required larger inlets, additional structural reinforcement, and further increases in mass, compounding the original problem. Restoring feasibility ultimately required substantial airframe and system redesign to reduce weight and rebalance the configuration, rather than relying on additional propulsion capability. The episode illustrates that propulsion upgrades can recover small margins, but they cannot compensate for fundamental configuration and weight-growth errors introduced earlier in the design process.
“Optimization will find the best design”
Optimization is often invoked to address design uncertainty. In practice, optimization operates only within a predefined configuration space and with respect to a chosen objective function. If the underlying commitments that define that space are poorly chosen, optimization merely identifies the best solution from an unacceptable set of options. Successful designs are rarely the global optimum of a mathematical objective function. They are robust solutions that tolerate uncertainty, accommodate growth, and perform acceptably across a wide range of operating conditions. In aerospace systems, margin and adaptability often outweigh nominal optimality.
One example is the distributed electric propulsion research program that ultimately led to the X-57 Maxwell demonstrator. In the early studies that preceded X-57, the dominant performance gains did not come from optimizing conventional design variables such as wing area, aspect ratio, or power-to-weight ratio within a single-propeller configuration, but from changing the propulsion-wing integration strategy by using distributed propulsors. An optimizer restricted to a design box defined around a traditional single-propeller airframe may converge cleanly and appear well behaved, but, by construction, cannot reveal a distributed-propulsion solution because the decisive design freedoms are configurational. This program clearly illustrates that optimization can refine a chosen concept, but it cannot discover a better one if the configuration itself is excluded from the configuration space.
“This can be fixed later”
Many design failures stem from the assumption that unresolved issues can be addressed later in development. While some refinements are possible, early commitments, such as wing loading, propulsion integration, staging configuration, or thermal layout, are effectively irreversible once geometry and primary structure are established. For airplanes, late fixes often lead to weight growth, drag penalties, or operational restrictions. For spacecraft, late fixes are frequently impossible without major redesign. Designs that depend on future corrections to justify present feasibility are rarely viable.
A well-known example is NASA’s X-33/VentureStar technology demonstrator. The program relied on a highly integrated lifting-body configuration with non-cylindrical composite cryogenic hydrogen tanks embedded within the primary structure. When the composite tank concept proved unable to meet strength, damage tolerance, and thermal-cycling requirements, the problem could not be corrected by incremental redesign. The tank geometry, load paths, and thermal protection layout were already fundamental to the vehicle’s configuration. Any viable fix required a wholesale reconfiguration of the airframe and structural concept, eliminating the mass and performance assumptions on which the vehicle had been sized. The program was ultimately canceled because the core configurational commitments could not be repaired after the fact.
“Nature has already solved this problem”
Biological inspiration and historical precedent can provide valuable insight, but they do not constitute engineering solutions. Natural systems evolve under constraints fundamentally different from those governing engineered vehicles, and historical designs reflect the technologies and materials of their time. Borrowing concepts without understanding the constraints that shaped them often leads to misplaced confidence. Engineering practice requires deliberate alignment among physics, materials, manufacturing, and mission, not merely analogy. Nature can inspire, but it is not a substitute for engineering analysis and design.
A classic example is the recurring claim that biomimetic flapping-wing vehicles are inherently more aerodynamically efficient than rotor- or propeller-based systems. While flapping flight can be highly effective for small animals operating at very low Reynolds numbers and under severe biological constraints, it does not follow that the same mechanisms provide superior propulsive efficiency for engineered aircraft. When analyzed consistently using thrust and power definitions, flapping systems generally exhibit no fundamental efficiency advantage over well-designed rotating propulsors and often incur additional structural, control, and mechanical penalties. The persistence of this myth reflects an appeal to visual similarity rather than a careful comparison of aerodynamic performance and system-level efficiency.
“We can make it work — it’s just software”
Another persistent fallacy is the belief that deficiencies in system performance, handling qualities, or robustness can be corrected late in development solely through software. While control laws, scheduling logic, and fault-management software can improve behavior within a limited envelope, they cannot remove fundamental physical limitations imposed by aerodynamics, mass properties, stability and control, aeroelasticity, etc. Software can shape how a system responds to the physics it is given, but it cannot change the physics themselves. Designs that rely on future control-law refinements or automation to compensate for inadequate control authority, poor stability margins, or unfavorable couplings are especially fragile. In practice, attempts to “fix it in software” often lead to increasing system complexity, tighter operating limits, and reduced tolerance to failures.
Summary & Closure
This chapter of the eBook has not attempted to teach aircraft or spacecraft design as a fixed procedure, nor to prescribe a single design methodology. Instead, its purpose has been to introduce how designers of aerospace flight vehicles reason about feasibility, commitment, coupling, and risk when working with limited information and making decisions that may be difficult or impossible to reverse. In the early stages of design, a small number of choices dominate the eventual success or failure of a flight vehicle.
Historical experience shows that many design failures in aerospace systems arise from predictable causes, such as uncontrolled weight growth, neglected system couplings, premature optimization, misuse of high-fidelity tools, such as CFD, and overconfidence in analytical predictions. Successful flight vehicles are rarely locally optimal in a narrow sense. Instead, they are designs that remain physically consistent, controllable, and robust across the full range of operating conditions, with adequate margins.
The analytical methods developed throughout this eBook remain essential to this process. Their primary value lies not in producing precise numbers, but in identifying dominant effects, exposing violated constraints, and supporting sound engineering judgment. Therefore, aerospace design is the context in which analysis is interpreted and used, not the final stage of analysis. In the end, the quality of a flight vehicle depends less on the sophistication of the tools employed than on the judgment with which they are applied.
5-Question Self-Assessment Quickquiz
For Further Thought or Discussion
- Which early configuration choice in an aircraft design is the most difficult to reverse later, and why?
- In what ways can a propulsion system that performs well in isolation lead to poor overall aircraft performance when installed?
- How should a designer decide where to place weight margins, and what are the consequences of placing them incorrectly?
- When should a designer accept lower peak performance in exchange for better operability or robustness?
- How should the trade-off between static stability and maneuverability be managed in a practical aircraft design?
- Which mission segment usually dominates energy consumption, and how should that influence configuration choices?
- Why is the lightest theoretical structure often not the best structural design in practice?
- Can you give an example where optimizing one subsystem degrades overall system performance, and explain why?
- How should a designer decide what level of modeling fidelity is appropriate at a given stage of the design process?
- When is it worth building and flying a subscale demonstrator instead of relying on analysis and simulation?
- How do certification requirements alter what would otherwise be an optimal technical design?
- How should a design team decide whether a new technology is worth the additional development risk?
Other Useful Online Resources
Visit the following websites to learn more about the design of aircraft and spacecraft:
- Aircraft design case studies, trade studies, and historical NASA design reports: NASA Technical Reports Server
- Current flight research programs and experimental airplanes: NASA Armstrong – Aeronautics and Flight Research
- University-level lecture notes and full courses on aircraft and spacecraft design: MIT OpenCourseWare – Aircraft and Spacecraft Design Courses
- Research on conceptual and preliminary aircraft design methods: Stanford Aeronautics and Astronautics – Aircraft Design Group
- Multidisciplinary aircraft and space systems design research: Georgia Tech ASDL – Aerospace Systems Design Laboratory
- Student design competitions, professional activities, and educational resources: AIAA – Student Resources and Design Competitions
- Peer-reviewed aerospace journal articles and conference papers: AIAA Aerospace Research Central (Journal Archive)
- Regulatory guidance on aircraft design, certification, and compliance: FAA – Aircraft Certification and Design Guidance
- European certification standards and design requirements: EASA – Certification Specifications
- Spacecraft systems engineering and enabling technologies: ESA – Spacecraft Systems and Engineering Technology
- Mission design concepts and spacecraft project descriptions: NASA JPL – Spacecraft and Mission Design Concepts
- Formal systems engineering processes and lifecycle guidance: NASA – Systems Engineering Handbook (PDF)
- Fundamental and applied research in aerodynamics and flight physics: ONERA – Aerodynamics and Flight Physics
- Academic programs and research in aerospace design and systems engineering: Cranfield University – Aerospace Design and Systems
- “How do you design an airplane?” the student asked. “Very carefully,” the engineer replied, “and with great respect for uncertainty.” ↵
- In aerospace engineering, the governing physical laws are unforgiving; conservation of mass, momentum, and energy, together with well-established material and aerodynamic limits, ultimately determine what is feasible. ↵
- All costs have been converted to 2020 constant U.S. dollars using CPI/GDP deflators. ↵
