58 Hypersonic Flight Vehicles
Introduction
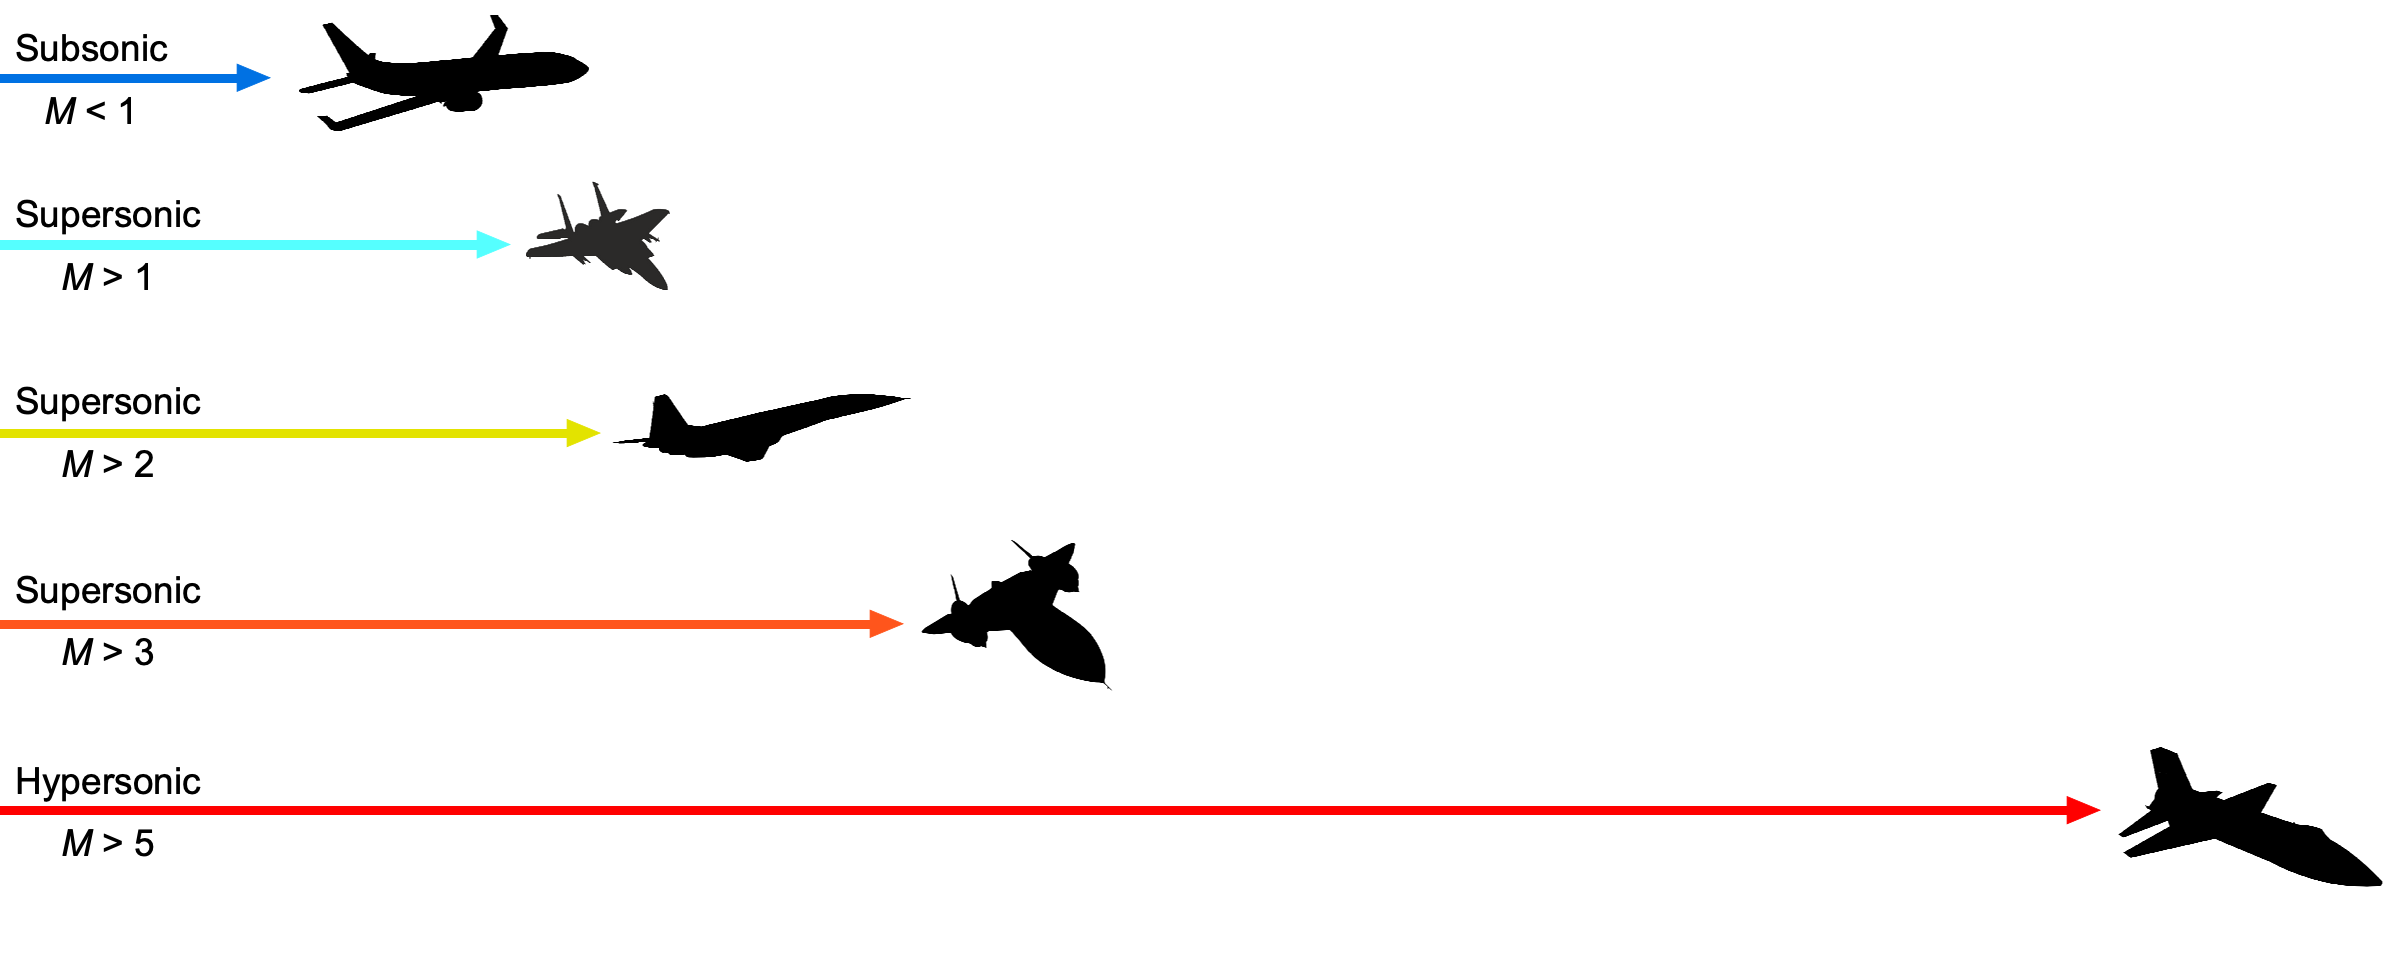
Hypersonic flight is generally defined as speeds at or beyond Mach 5; see Figure 1. However, unlike what happens as an aircraft approaches Mach 1, the flow characteristics do not undergo a single, discrete transition as the aircraft reaches hypersonic Mach numbers. Only rockets, re-entry spacecraft, and specialized high-altitude research aircraft have achieved such high Mach numbers. Indeed, every spacecraft that re-enters Earth’s atmosphere travels at hypersonic speeds. The proverbial image of a flaming spacecraft streaking through the upper atmosphere at Mach 20 is no exaggeration; it reflects the aerodynamic and thermal environment. Theodore von Kármán was one of the first to analyze the problems of hypersonic flight, stating: “At such speeds, even in rarefied air, the surface will be heated to the temperatures none of the known materials can withstand. The problem of the thermal barrier is much more complicated than the problem of the sound barrier.”
From an engineering perspective, hypersonics is best understood as a multidisciplinary regime in which fluid mechanics, thermodynamics, and chemistry are tightly coupled. As vehicles reach hypersonic Mach numbers, new aerodynamic and technical challenges emerge. As shown in the schematic in Figure 2, these include strong shock waves near the surface, extreme aerodynamic heating, complex airframe-engine interactions, strong viscous effects, high-temperature chemical reactions, and material erosion. These conditions require specialized design strategies, particularly airframe shaping to dissipate heat and maintain control. Hypersonic vehicles often feature blended bodies with tightly integrated propulsion systems, in stark contrast to the separate airframe-and-engine architectures of subsonic and supersonic aircraft.

Hypersonic flow is typically considered to begin around Mach 5, but this threshold is not sharply defined. Hypersonic effects include thin shock layers and strong viscous interactions, while high-temperature thermochemical effects depend on the flow’s total enthalpy and local conditions. As a vehicle travels faster, the kinetic energy of the incoming air becomes high enough that, upon deceleration near the body, it converts into internal energy, dramatically increasing the gas’s thermal and chemical activity. In more detail, the effects encountered at hypersonic Mach numbers include, but are not limited to, the following:
- The Mach angle decreases as Mach number increases. Over slender bodies, attached shock waves generally lie closer to the surface at higher Mach numbers, although their inclination also depends on the flow-deflection angle. These shocks can interact with the surface boundary layers, often triggering flow separation. Boundary layers at hypersonic speeds may be laminar but relatively thick; consequently, shock-boundary-layer interactions make the flow field highly complex.
- Shocks near the surface and viscous boundary layers cause intense aerodynamic heating. Even high-temperature materials commonly used in supersonic aircraft, such as aluminum and titanium, cannot withstand hypersonic environments without protection.
- The surface boundary layers are relatively thick, introducing significant viscous interactions with the predominantly outer inviscid flow. This viscous/inviscid interaction effectively displaces the outer streamlines, causing the vehicle to appear aerodynamically larger or differently shaped than its actual geometry.
- For air-breathing hypersonic vehicles, the external flow is strongly coupled to the propulsion system. The forebody can be shaped to precompress incoming air before it reaches the engine inlet, leading to highly integrated airframe-propulsion configurations.
- Shock waves at hypersonic speeds can produce substantial temperature increases, particularly near stagnation regions or where the flow undergoes large compression turns. These high temperatures can initiate chemical reactions in the air, including dissociation and ionization, necessitating thermochemical models to accurately predict aerodynamic behavior.
- Sonic booms from hypersonic vehicles can be severe, especially for large vehicles flying at relatively low altitudes or along sustained atmospheric cruise trajectories. Their ground-level impact depends strongly on vehicle size, altitude, lift, flight path, and atmospheric propagation. For this reason, boom mitigation and overpressure limits are major constraints on any future civil hypersonic aircraft.
These challenges define the physical boundaries within which hypersonic vehicles must be designed, tested, and operated. Overcoming them requires a multidisciplinary approach that spans aerodynamics, thermodynamics, materials science, and flight control systems.
Hypersonic technologies may also have significant implications for military systems by enabling vehicles that travel at speeds exceeding Mach 5 and, in some cases, maneuver within the atmosphere. Their high speed, maneuverability, thermal environment, and compressed engagement timelines make detection, tracking, and interception especially challenging. Platforms such as hypersonic glide vehicles and cruise missiles offer rapid global-strike capabilities but pose significant challenges for thermal protection, guidance, and propulsion. Several countries are investing heavily in these systems, leading to corresponding investments in counter-hypersonic defense capabilities based on advanced sensing and interceptor technologies.
On the civil side, hypersonic flight remains a long-term ambition, with research targeting Mach 5 passenger aircraft that could significantly reduce intercontinental travel times. However, significant hurdles remain in developing propulsion systems, managing heat, and obtaining regulatory approval. Sonic booms from future civil hypersonic vehicles could limit operations over populated areas. Their intensity and public acceptability would depend on the vehicle design, flight conditions, and atmospheric propagation, making sonic boom mitigation an additional design consideration.
Learning Objectives
- Appreciate the unique aerodynamic and thermal challenges faced by aircraft operating at hypersonic speeds, including strong shock interactions, high aerodynamic heating, and high-temperature “real gas” effects.
- Know how to apply analytical techniques, such as Newtonian and shock-expansion theories, to determine the aerodynamic properties of bodies in hypersonic flow.
- Understand the roles of high-temperature gas dynamics, boundary-layer behavior, thermal protection strategies, and air-breathing engine concepts, such as scramjets, in the design and analysis of hypersonic vehicles.
History of Hypersonic Flight Vehicles
The challenges associated with hypersonic flight first became evident during the early Cold War, when post-WWII ballistic missile development pushed vehicles into Mach 5 and higher regimes. To achieve intercontinental range, these missiles had to exit the atmosphere and re-enter it near the target. Building on wartime ballistic-missile experience, including the highly pointed nose of the German V-2 configuration, engineers soon recognized that long-range ballistic reentry vehicles would encounter severe aerodynamic heating and shock-wave compression during atmospheric reentry. For slender, pointed shapes, the shock remained close to the surface, producing intense heating and making conventional sharp-nosed designs unsuitable for high-speed reentry. These events highlighted the extreme aerodynamic and thermal loads encountered in hypersonic flight, which have since become the subject of extensive research.
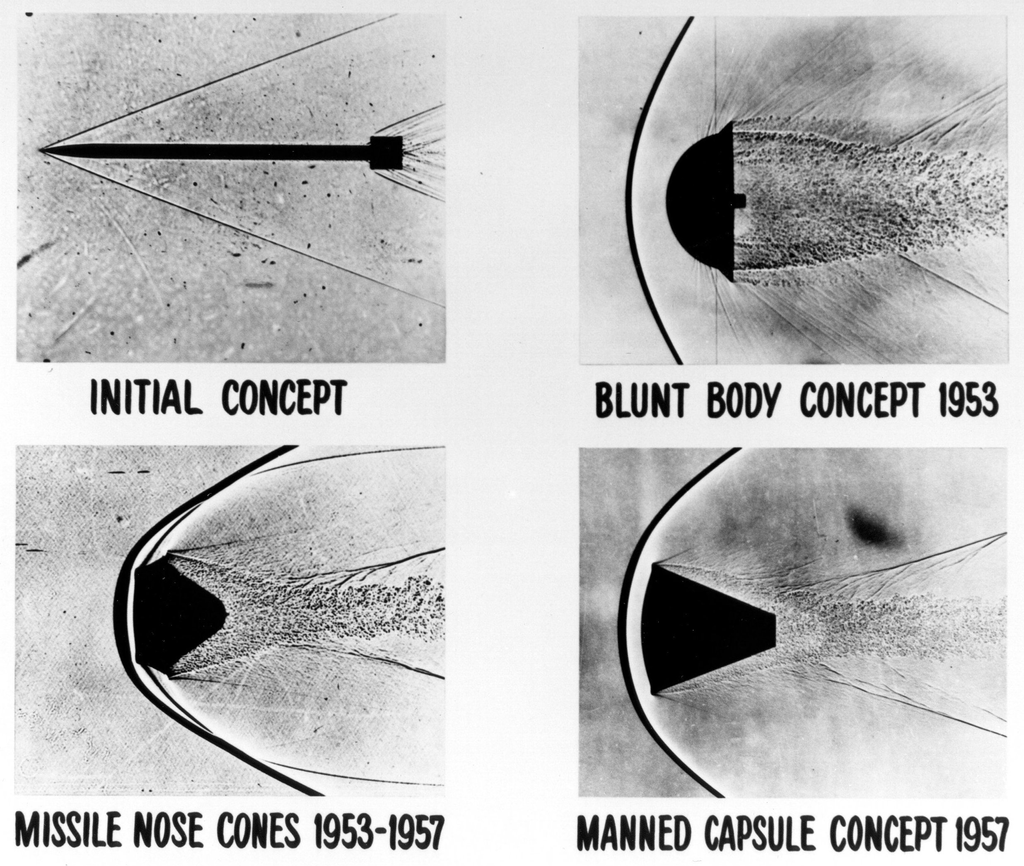
The solution to this aerodynamic heating problem, based on NACA research by H. Julian Allen and Alfred Eggers, was the opposite of conventional aerodynamic wisdom: making the missile nose much blunter and rounder, as shown in the schlieren images in Figure 3. This “blunt body” design generated a detached shock wave that stood off the nose, moving much of the intense shock heating away from the surface. The larger nose radius also reduced the stagnation-point heat-transfer rate and distributed the thermal load over a broader area. For the same freestream and wall conditions, a smaller nose radius generally produces a higher stagnation-point heat-transfer rate because of the steeper velocity and temperature gradients in the boundary layer near the nose. Tests with the modified missiles confirmed the validity of this method, although the nose still required high-temperature-resistant materials.
The information gained from wind tunnel and flight tests of high-speed and hypersonic flight significantly contributed to the development of the Mercury, Gemini, and Apollo spaceflight programs. The U.S. Air Force and NASA first conducted flight testing of hypersonic systems during the 1950s. The X-15 research aircraft flew for nearly 10 years, starting in 1959. During a series of flights that investigated many aspects of piloted hypersonic flight, the program set unofficial speed and altitude records of 4,520 mph (Mach 6.7) and 354,200 feet.
The X-17 was a research program that used a three-stage rocket to accelerate test nose cones to approximately Mach 11 to 14.5 during atmospheric descent. The nose cones survived briefly before vaporizing, but long enough to make valuable measurements. Ultimately, the solution to minimizing kinetic heating effects on re-entry vehicles was to use ablative materials to shed heat buildup.
During the 1980s, NASA began considering a single-stage hypersonic flight vehicle to replace the Space Shuttle. As Figure 4 illustrates, the National Aerospace Plane (NASP) was intended to take off from a standard airliner runway. Once the aircraft had reached sufficient airspeed, the scramjet engines would power it into hypersonic flight. Finally, a rocket system would take the NASP into orbit. The NASP program eventually led to the proposed Rockwell X-30 research vehicle, but NASA never built or flew the X-30. Later, NASA pursued related research into hypersonic air-breathing propulsion through the X-43A Hyper-X program, and built three small uncrewed X-43A vehicles. The first was lost after a launch-vehicle malfunction, but the other two flew successfully in 2004, with the scramjet operating for approximately 10 seconds.

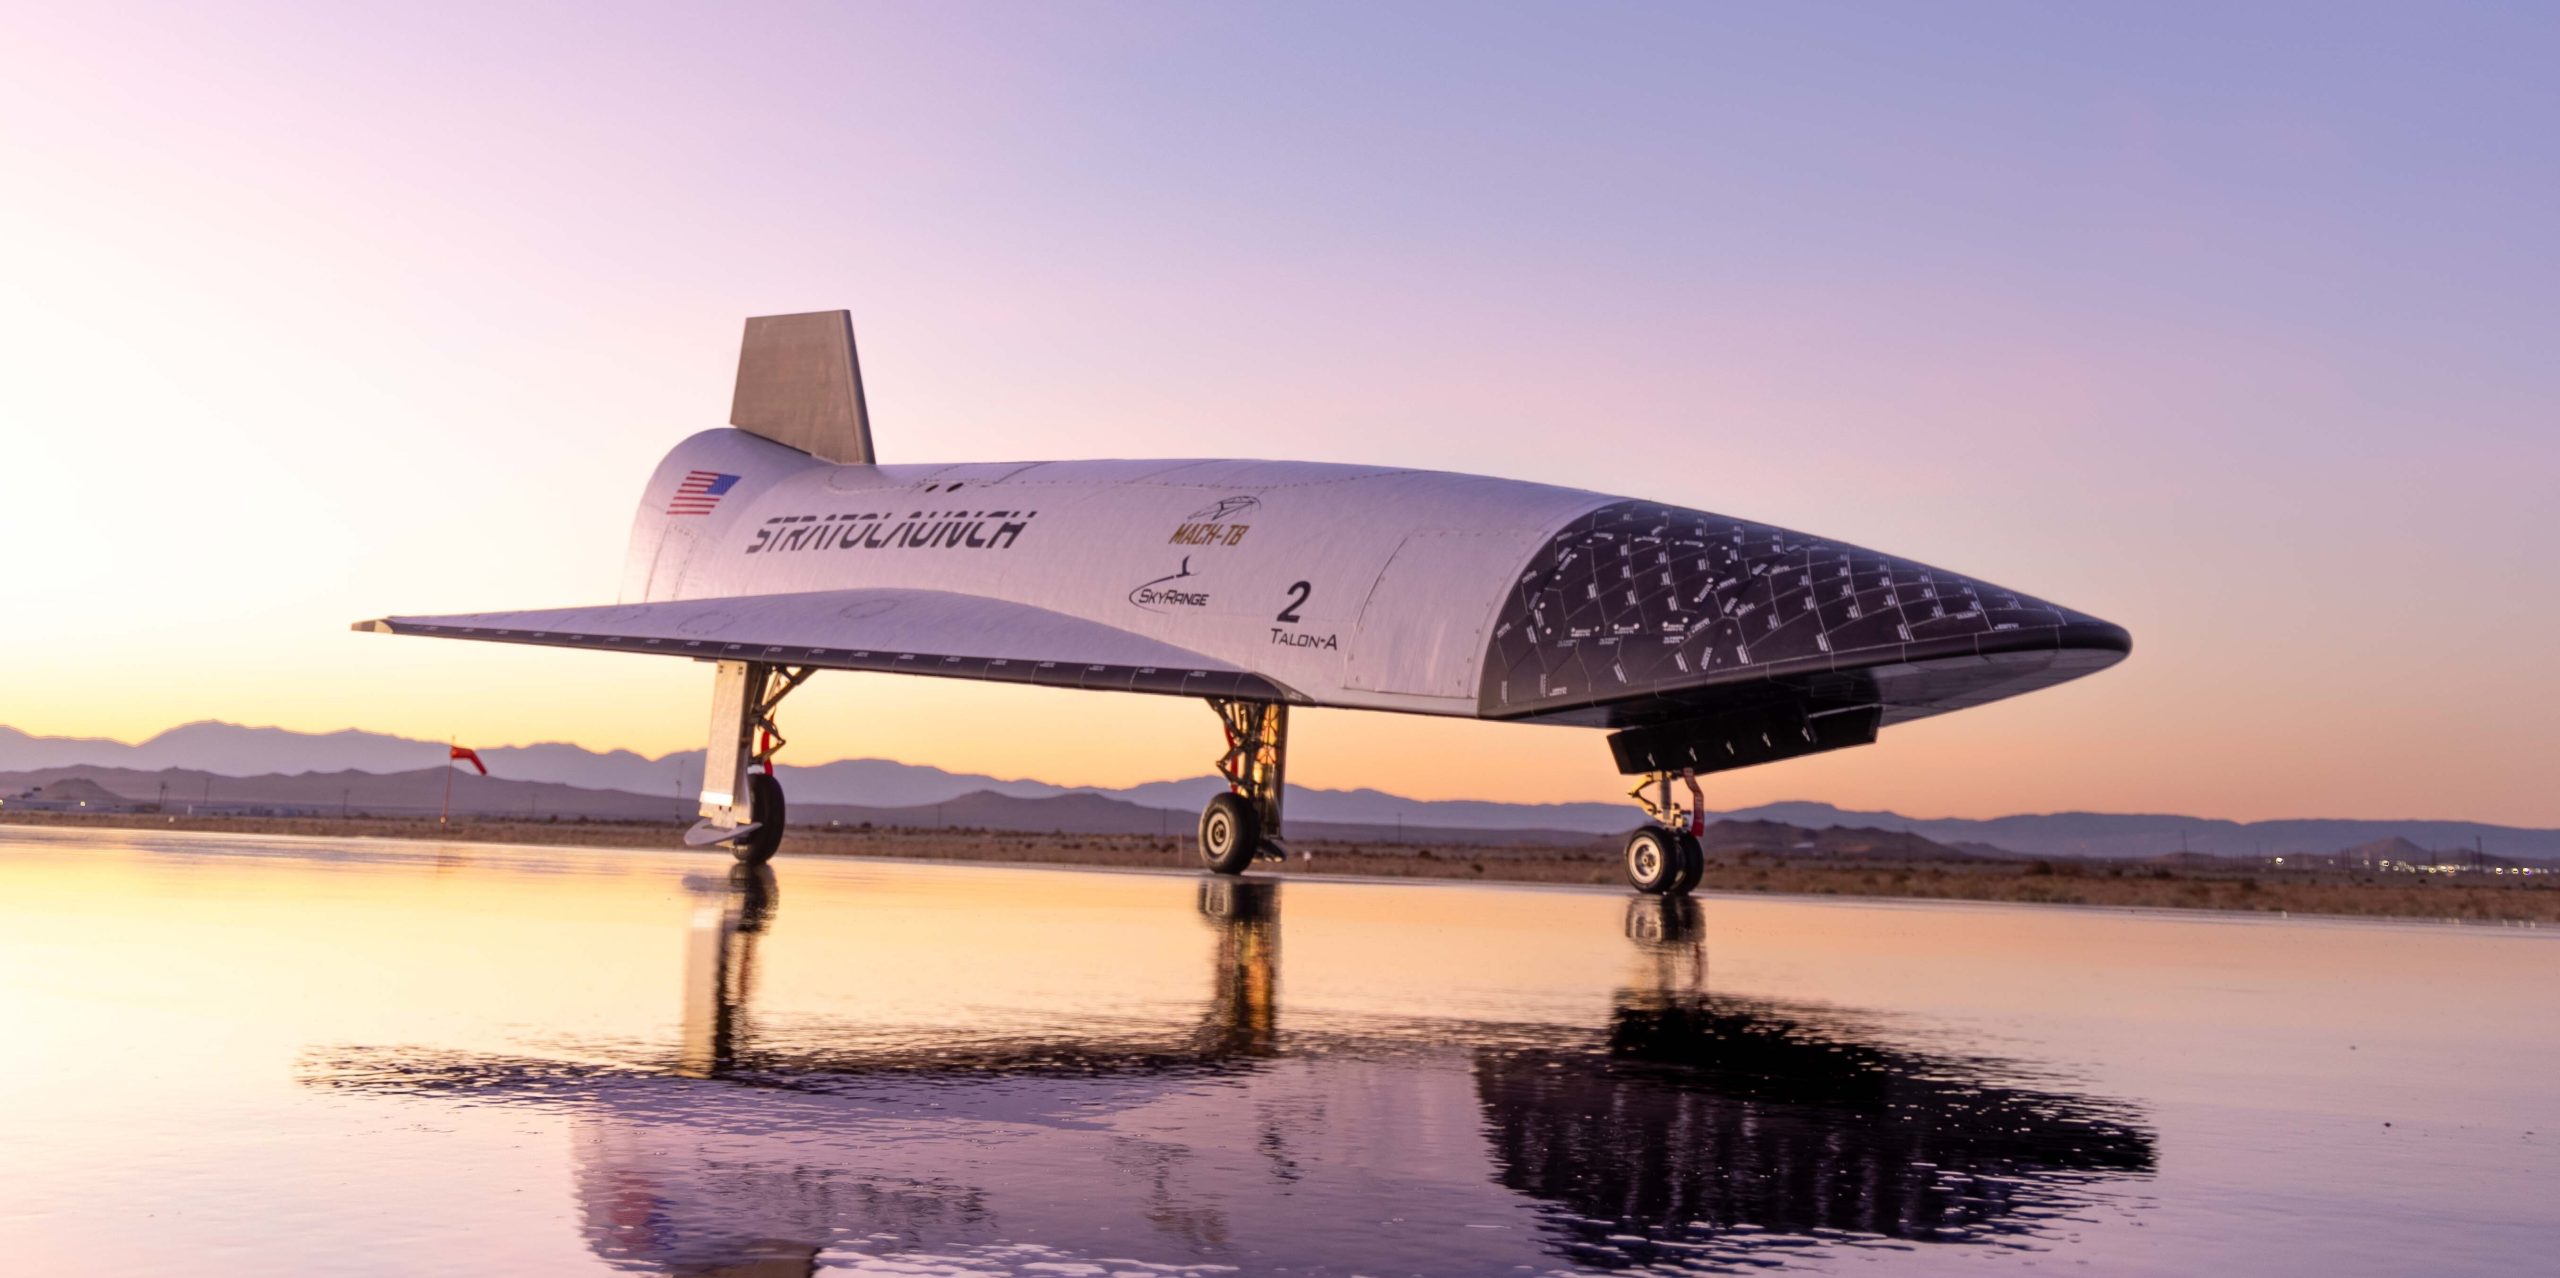
Since the X-43A’s flights in the early 2000s, hypersonic development has seen further, albeit limited, worldwide progress. The U.S. X-51A Waverider achieved sustained scramjet-powered flight at Mach 5.1 for over 200 seconds, while Stratolaunch’s reusable Talon-A vehicle reached hypersonic speeds and completed recovery missions by 2025; see Figure 5. Venus Aerospace demonstrated a rotating detonation rocket engine for its Mach 9-capable Stargazer platform. Australia’s Hypersonix has developed the hydrogen-fueled SPARTAN scramjet for the Delta-Velos vehicle, which is designed to reach speeds up to Mach 12. Meanwhile, Switzerland’s Destinus and China’s hypersonic aircraft efforts target commercial applications, while India has also entered the arena through successful hypersonic missile tests. These advances signal growing global investment in reusable, high-speed flight technologies across defense, research, and future commercial transport.
Hypersonic Flow Modeling
Hypersonic aerodynamics entails physical effects distinct from those encountered in subsonic or supersonic regimes. As flight speeds exceed Mach 5, strong shock waves, extreme post-shock temperatures, thicker boundary layers, and significant thermal loads increasingly dominate the flow. The physical complexity of hypersonic flow makes a detailed fluid mechanics analysis challenging, especially in early-stage design or conceptual studies. Strong shocks, entropy[1] gradients, viscous interactions, and chemical effects contribute to this difficulty. To this end, engineers often rely on simplified models that approximate surface pressures and aerodynamic forces without the computational expense of solving the governing flow equations numerically.
Shocks at High Mach Numbers
In supersonic flow, a wedge-shaped body generates an oblique shock wave at its leading edge, as shown in Figure 6. Unlike a normal shock, which stands perpendicular to the upstream flow, an oblique shock is inclined to it. The downstream flow usually remains supersonic for the weak-shock solution, but it can become subsonic. As the freestream Mach number increases, the shock angle decreases, bringing the shock closer to the surface.
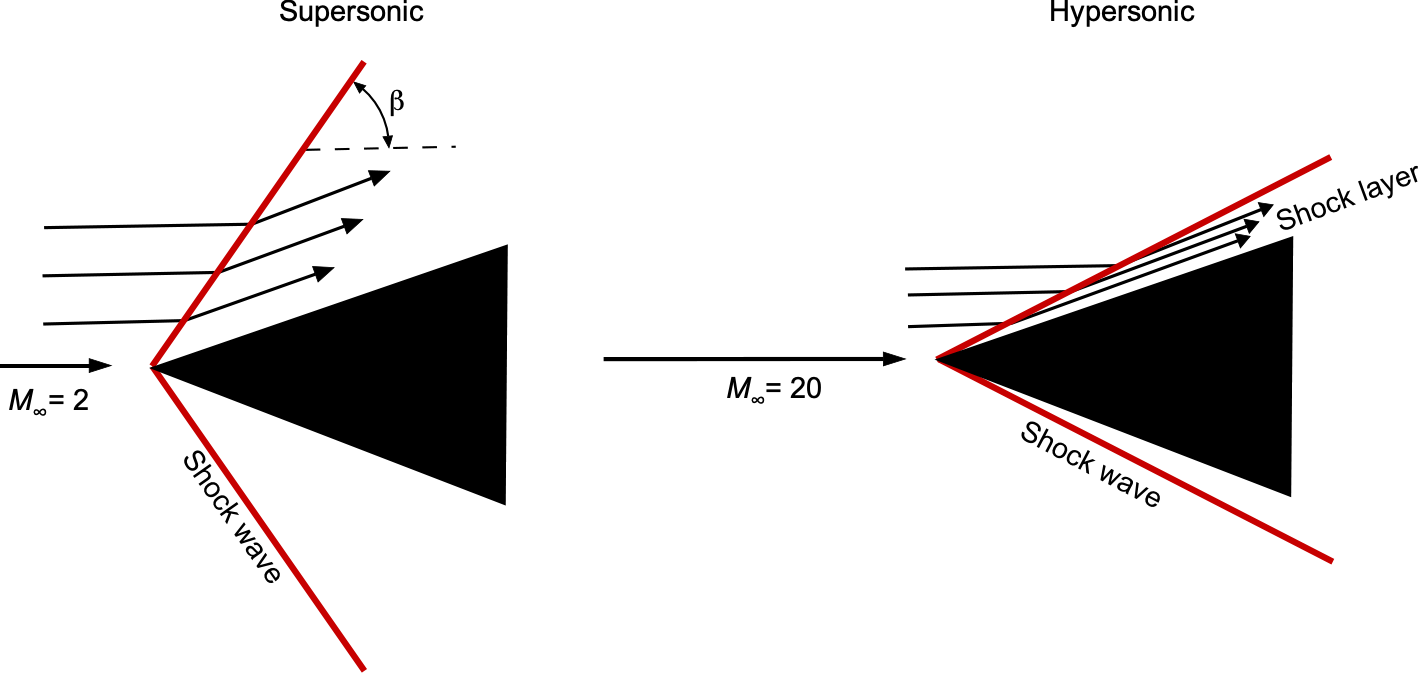
At hypersonic speeds, the distance between the attached shock and the body surface can become very small, and the region between them is often referred to as a shock layer. This shock layer can be extremely thin over slender bodies at high Mach numbers. At high altitudes, however, the lower Reynolds number increases the relative importance and thickness of the viscous boundary layer, which may occupy a substantial portion of the shock layer. Under such conditions, the shock layer may interact with or merge into the boundary layer, forming a fully viscous shock layer. This complex regime significantly influences heat transfer, surface pressures, and overall aerodynamic characteristics.
Slender Bodies
When a supersonic flow encounters a sharp compression surface, such as a wedge or ramp, the flow is deflected through an angle  relative to the incoming stream, as shown in Figure 7. In response, an oblique shock forms at an angle
 with respect to the upstream flow direction. The relationship between the deflection angle , the shock angle , and the upstream Mach number
 is described by the
 ––
 relation, a fundamental expression in compressible flow theory. As discussed in the previous chapter, this relationship is given by
(1) 
where  is the ratio of specific heats, taken here as 1.4 under the calorically perfect-gas approximation for air.

For a given Mach number and deflection angle, two shock solutions exist: a weak shock and a strong shock. The weak solution is typically observed in external aerodynamic flows because it produces smaller increases in pressure and temperature and usually maintains supersonic flow downstream of the shock. Although mathematically valid, the strong-shock solution is generally not selected for an attached shock in an unconfined external flow because the weak-shock solution satisfies the downstream conditions and yields a smaller entropy increase. The strong-shock solution may occur when imposed downstream pressure conditions require subsonic flow behind an attached shock. If the required flow deflection exceeds the maximum value for attachment, a detached bow shock forms instead.
At high Mach numbers, when the small flow-deflection angle is nevertheless large compared with the Mach angle, the attached shock lies close to the body surface. For much smaller deflections, the shock angle approaches the Mach angle instead. However, as the deflection angle approaches a critical value, the oblique shock becomes increasingly intense and eventually separates from the surface. Beyond this point, the shock detaches, forming a curved bow shock ahead of the body. This shock detachment phenomenon is particularly significant in hypersonic flow, where even slight changes in body geometry can dramatically alter surface pressure and thermal loads.
The onset of shock detachment can be examined using the –– relation, which links the upstream Mach number  , the flow deflection angle , and the shock angle . For a given , a maximum allowable deflection angle
 exists beyond which no attached oblique shock solution exists. This critical angle depends on the Mach number and the specific heat ratio , and it marks the transition from an attached oblique shock to a detached bow shock. To maintain shock attachment and predictable pressure distributions, designers must keep surface deflections below this threshold. For blunt geometries or large deflection angles, detached shocks and intense local heating are unavoidable and must be accounted for in the design of the thermal protection system.
Hypersonic Similarity
For slender bodies at high Mach numbers, the aerodynamic behavior depends not only on the Mach number or body angle separately, but also on their combined effect. Consider a slender wedge or cone with a characteristic surface inclination angle . In the hypersonic small-disturbance limit, the governing parameter is
(2) 
where is expressed in radians. This quantity is commonly called the hypersonic similarity parameter. This result means that flows with different Mach numbers and body angles may exhibit similar pressure distributions when  is the same. For example, a very slender body at a high Mach number may produce a flow field similar to that of a less slender body at a lower Mach number, provided that their hypersonic similarity parameters are equal.
For slender bodies, the surface pressure coefficient can be expressed in the general similarity form
(3) 
where  is a function determined from the hypersonic flow solution. Therefore, the pressure coefficient scales approximately with the square of the body inclination angle, while the detailed pressure behavior depends on the combined parameter .
Hypersonic similarity is useful because it reduces the number of independent variables needed to characterize a family of slender-body flows. It also provides a basis for comparing wind-tunnel tests, analytical solutions, and flight conditions having different Mach numbers and geometric scales. However, the similarity principle applies best to slender bodies with small surface inclinations and attached shock waves. It becomes less accurate for blunt bodies, large deflection angles, strong viscous interaction, or flows dominated by high-temperature chemistry.
Blunt Bodies
Unlike slender bodies that produce attached oblique shocks, blunt bodies generate detached bow shocks. The bow shock is normal to the freestream only near the stagnation streamline and becomes increasingly oblique away from the centerline. This behavior occurs, for instance, at the nose of a reentry vehicle, as shown in Figure 8, where the flow cannot turn smoothly around the body as it does over a wedge. Instead, the air must decelerate to near-zero velocity over a very short distance. In supersonic or hypersonic regimes, the only physically admissible way for this to occur is through the formation of a detached bow shock standing off from the surface. This strong bow shock causes a sudden rise in pressure and temperature, initiating a highly energetic shock layer that envelops the front of the vehicle. The compression is strongest near the stagnation streamline, where the shock is locally normal.
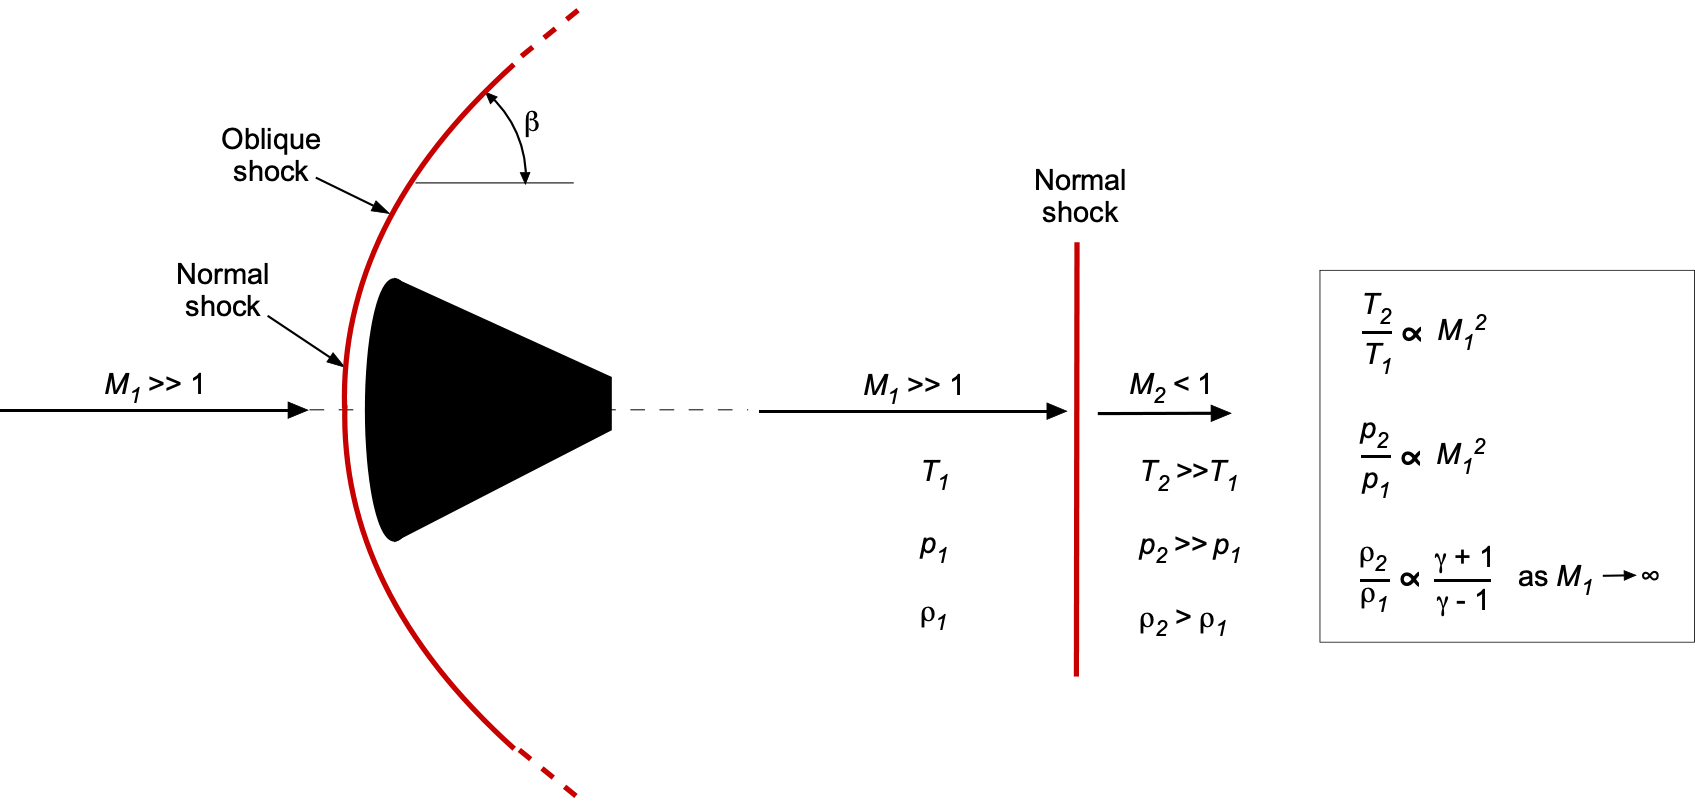
Notice that the shock is normal only along the centerline, where the freestream stagnates; elsewhere, it is oblique, wrapping around the body and becoming more inclined as it moves farther from the centerline. Across an oblique shock, only the velocity component normal to the shock is compressed, while the tangential component remains unchanged. The governing equations for pressure, temperature, and density changes are still those of a normal shock, but they apply to the normal component of the upstream Mach number, i.e.,
(4) 
where is the freestream Mach number and is the local shock angle between the flow and the shock front. The downstream Mach number is computed from the turned flow, accounting for both components. The downstream flow is usually supersonic for a weak oblique shock, although it can become subsonic as the deflection angle approaches the maximum value for shock attachment. The strong-shock solution produces subsonic downstream flow.
A normal shock wave abruptly increases pressure, temperature, and density while sharply reducing the Mach number. As the upstream Mach number increases, these thermodynamic changes become more pronounced. In the strong-shock limit ( ), the post-shock pressure and temperature scale approximately with
 . For a calorically perfect gas in the strong-shock limit, the leading-order approximations for the temperature and pressure ratios across a normal shock are
(5) 
where is the ratio of specific heats, which is 1.4 for air at normal temperatures and pressures. These relations assume constant specific heats. As the post-shock temperature rises, vibrational excitation causes the specific heats to vary, and at still higher temperatures, dissociation can also become important. The accuracy of the calorically perfect-gas approximation must be assessed for the conditions considered.
These expressions highlight how sensitive post-shock conditions are to the freestream Mach number. Even moderate increases in can significantly increase downstream pressure and temperature. In hypersonic flow, where Mach numbers are incredibly high, normal shocks produce steep thermal gradients that significantly affect boundary-layer behavior and surface heating. A key consequence of this heating is the dramatic increase in convective heat flux at the surface of a hypersonic vehicle. A commonly used stagnation-point heating correlation has the approximate scaling
(6) 
The velocity is related to the Mach number by
(7) 
where the local speed of sound is
(8) 
If ambient density, ambient temperature, nose radius, gas composition, and the applicable stagnation-point heating correlation are all held fixed, then  and the approximate scaling becomes
(9) 
Under these restricted assumptions, doubling the Mach number would increase the predicted stagnation-point convective heat flux by a factor of eight. This is not a general flight-to-flight relationship because density, temperature, altitude, nose radius, boundary-layer state, and high-temperature gas behavior may also change substantially with Mach number.
Several important limiting cases can help illustrate this behavior. At the stagnation streamline,  , so
 , and the result is a full normal shock. As the shock angle decreases with increasing distance from the centerline,
 becomes smaller, and the shock weakens. In the limit as
 approaches the Mach angle,
 , the shock becomes an infinitesimally weak Mach wave. Consequently, shock strength, heating, and pressure rise vary continuously over the body’s surface. The highest heating and pressure occur near the nose, where the shock is nearly normal, and the freestream kinetic energy is most effectively converted into internal energy. This has direct consequences for aerodynamic loading and the design of thermal protection systems.
Shock Layers & Boundary Layer Behavior
At hypersonic speeds, a blunt body produces a detached bow shock, enclosing a region of compressed, decelerated gas known as the shock layer, as shown in Figure 9. Near the stagnation streamline, the shock is nearly normal to the incoming flow, producing a large rise in pressure and temperature. The gas decelerates sharply across the shock and then slows further as it approaches the stagnation point. Farther from this region, the shock becomes increasingly oblique and produces less flow deceleration. The thickness of the shock layer depends on the body geometry and flow conditions and does not necessarily decrease downstream.
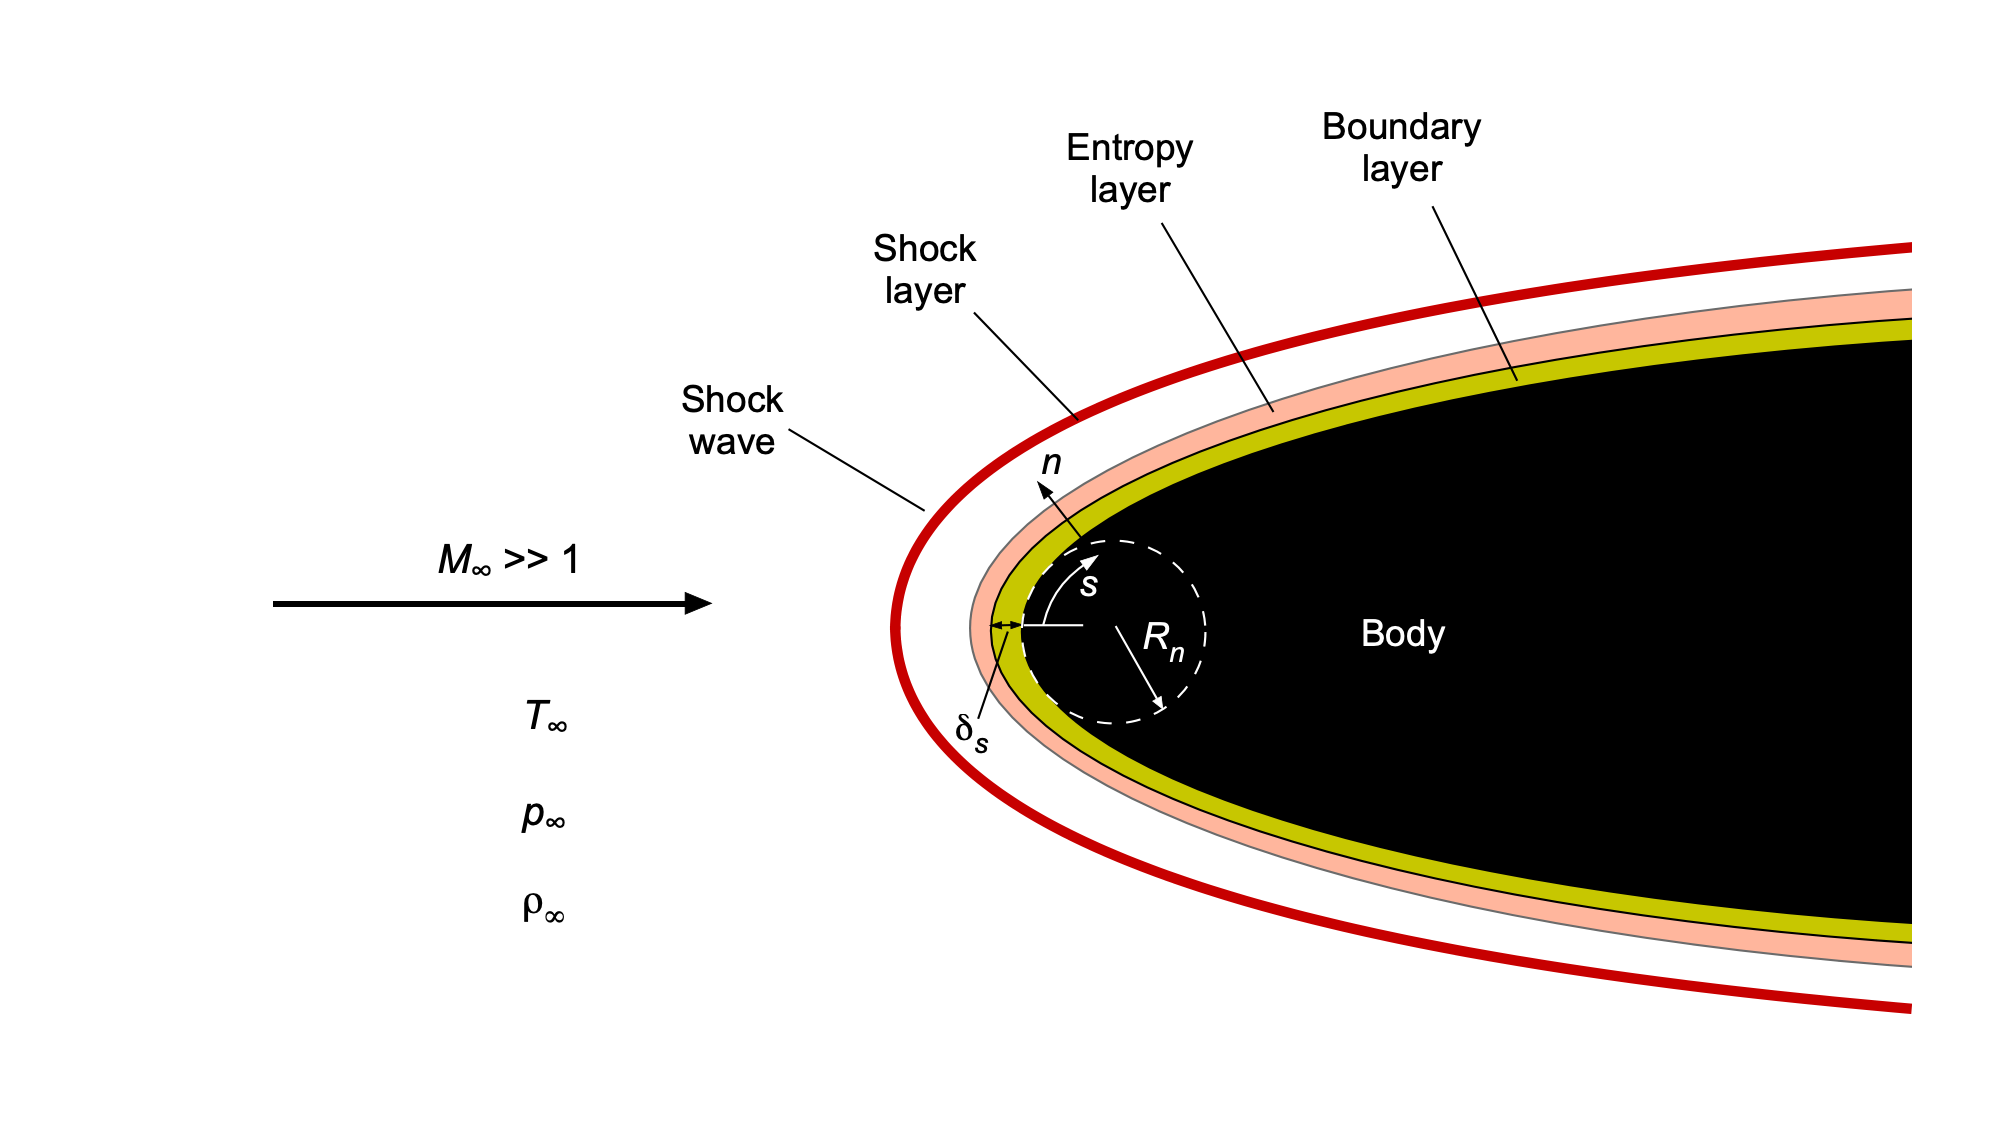
Near the stagnation point, the bow-shock standoff distance depends strongly on the nose radius and the density increase across the shock. Body shape, Reynolds number, wall temperature, and high-temperature gas behavior also influence this distance. For a specified body shape, the dependence may be written qualitatively as
(10) 
where  is the shock standoff distance and
 is the nose radius. Appropriate blunt-body correlations, CFD, or experimental data are needed to evaluate this dependence. When the shock layer is thin compared with the characteristic body dimensions, thin shock-layer theory can simplify the governing flow equations and provide approximate pressure distributions.
The resulting surface pressure is commonly expressed using the pressure coefficient, i.e.,
(11) 
where  is the wall pressure and
 is the freestream dynamic pressure. At the stagnation point, the pressure coefficient reaches its maximum value, denoted
 . For a calorically perfect gas, this value can be estimated using the normal shock relations followed by isentropic deceleration of the post-shock flow to obtain the stagnation pressure
 .
An approximate pressure distribution over the windward surface of a blunt body can then be obtained using modified Newtonian theory, which is developed later in this chapter. This model combines the stagnation-point pressure coefficient with the local surface orientation according to
(12) 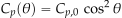
where is the angle between the freestream direction and the surface normal. The model provides a useful preliminary estimate of pressure loads, but it does not determine skin friction or heat transfer. These require consideration of the viscous and thermal boundary layers adjacent to the surface.
Within the shock layer, the boundary layer develops as viscosity brings the gas velocity to zero at the stationary body surface. Its thickness and displacement effect depend on the local flow conditions, pressure gradient, wall temperature, and temperature-dependent gas properties. At hypersonic speeds, the boundary layer can occupy a substantial fraction of the shock layer, particularly at low Reynolds numbers. Its displacement of the outer flow can then alter the surface pressure and shock position, creating a coupled viscous-inviscid interaction.
For a laminar boundary layer over a flat plate with negligible pressure gradient, the familiar streamwise scaling remains
(13) 
when the edge-flow conditions, wall-temperature ratio, and gas model are held fixed. Here,  is the distance from the leading edge, and
 is based on and the conditions at the boundary-layer edge. The proportionality factor depends on compressibility, wall temperature, and the variation of gas properties through the layer. A universal Mach-number multiplier cannot describe both cold-wall and adiabatic-wall conditions without additional assumptions.
Whether the boundary layer remains laminar or becomes turbulent is an important design consideration. A turbulent boundary layer generally produces much higher surface heat-transfer rates and skin-friction drag than a laminar boundary layer under comparable conditions. Transition depends on Reynolds number, Mach number, wall temperature, pressure gradients, freestream disturbances, and surface roughness. Protrusions, gaps, damaged thermal-protection tiles, or manufacturing irregularities can trigger premature transition and create localized regions of intense heating. Consequently, uncertainty in the transition location must be considered when sizing the thermal protection system.
Check Your Understanding #1 – Analysis of the nose of a reentry vehicle
Consider a reentry vehicle traveling at a freestream Mach number of  through the upper atmosphere at an altitude of approximately 40 km. The vehicle has a hemispherical nose with a radius of curvature = 0.5 m. At this altitude, the freestream conditions are:
 = 0.003996 kg/m
 ,
 = 250 K, and
 = 287 Pa. Assume the gas behaves as a perfect gas with a specific heat ratio of = 1.4 and gas constant
 = 287 J/(kg K).
Show solution/hide solution.
This example focuses on the vehicle’s leading-nose geometry, where hypersonic compression effects and shock-layer behavior are most pronounced. The surface pressure and pressure coefficients can be estimated at key locations along the nose using a simple pressure-coefficient approximation for blunt hypersonic flow. The freestream velocity follows from the Mach-number definition and the speed of sound, i.e.,
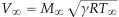
Substituting the values gives

The dynamic pressure is calculated using

To estimate the pressure at the stagnation point, the normal shock relation is first used to estimate the static pressure immediately behind the shock, i.e.,

The downstream Mach number behind the normal shock is

The flow then decelerates approximately isentropically from state 2 to the stagnation point, so that

Therefore,

The stagnation-point pressure coefficient is then

To estimate the pressure at an off-stagnation location, say  , a simple blunt-body pressure approximation can be used, i.e.,

where is measured between the freestream direction and the local surface normal. Therefore,

The local surface pressure is
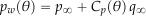
so that

Finally, the bow-shock standoff distance near the stagnation region is expected to scale with the nose radius and shock compression, but the Mach number alone cannot determine it accurately. A reliable value would require an appropriate blunt-body shock-standoff correlation, CFD, or experimental data. These results demonstrate key features of hypersonic flow over blunt reentry geometries, including strong compression, high stagnation pressure, and a detached bow shock.
Entropy Gradients & Flow Interactions
An increase in entropy means irreversible processes, such as shock compression and viscous dissipation, have degraded the flow’s ability to do useful work. Across a shock wave, entropy always increases because the compression process is irreversible. Across a curved bow shock, the entropy rise is not uniform; it is largest near the stagnation streamline, where the shock is nearly normal, and smaller away from the centerline, where the shock becomes increasingly oblique. This creates an entropy layer in the shock layer that can distort the outer flow and interact with the surface boundary layer.
The boundary layer in hypersonic flow can become thick enough to exert a significant displacement effect on the inviscid flow outside it. In this sense, the body can appear aerodynamically thicker than its actual geometric shape. This coupling between the viscous boundary layer and the outer inviscid flow is known as viscous interaction. A commonly used approximate form of the hypersonic viscous-interaction parameter is
(14) 
where  is the freestream Mach number and
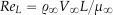 is the Reynolds number based on a characteristic length
 and freestream viscosity
 . Variants of this parameter include additional property-ratio and wall-temperature corrections, but the essential scaling is that viscous interaction increases rapidly with Mach number and decreases with increasing Reynolds number.
Values of  less than 1 indicate relatively weak viscous interaction, values near 1 indicate moderate interaction, and values greater than about 3 indicate strong interaction. In the strong-interaction regime, the boundary layer can significantly affect shock shape, boundary-layer growth, pressure gradients, lift, drag, and heat transfer. The nondimensional ratio
 may still be useful as a heat-transfer scaling because
 represents the order of the incoming kinetic-energy flux, but it should not be identified as the viscous-interaction parameter.
Boundary Layer Scaling & Surface Heating
A dominant effect of high temperatures in hypersonic flow about a body is the high rate of heat transfer to the exposed surfaces. Thermal loads are a primary design constraint in hypersonic vehicles, as expected. Friction dissipates the kinetic energy of a high-speed flow and converts it into internal energy within the boundary layer. Extreme viscous dissipation within hypersonic boundary layers can generate very high temperatures. As discussed above, boundary-layer growth depends on compressibility, wall temperature, and temperature-dependent gas properties. Surface heating depends more directly on the temperature gradient at the wall and the gas thermal conductivity. A thick boundary layer does not, by itself, imply a high heat-transfer rate.
Near the stagnation point, the freestream kinetic energy is converted into internal energy, resulting in intense surface heating. A representative scaling law for the stagnation-point heat flux is
(15) 
which highlights the strong cubic dependence on velocity. Even modest increases in velocity can lead to substantial increases in heat flux, necessitating more robust thermal protection. For an adiabatic surface, there is no net heat transfer through the wall. The recovery temperature is the adiabatic wall temperature. For a calorically perfect gas, it can be estimated from
(16) 
where  and
 are the temperature and Mach number at the boundary-layer edge, and
 is the recovery factor. For a laminar boundary layer over a flat plate,
 , where
 is the Prandtl number. Convective heat transfer is directed into the surface when the wall temperature is below the recovery temperature.
The resulting kinetic heating on a hypersonic flight vehicle can raise its surface temperature to several thousand degrees Kelvin, particularly at stagnation points and along the leading edges. These extreme thermal loads severely constrain materials selection, structural design, and aerodynamic shaping. Conventional metals such as aluminum and titanium rapidly lose strength or melt at such temperatures, making them unsuitable for exposed surfaces. This means that hypersonic vehicles must incorporate specialized thermal protection systems (TPS) and high-temperature structural materials to withstand these conditions. Extensive studies were conducted to measure the Orbiter’s temperatures during re-entry, as shown in Figure 10. The highest temperatures [2] reached 1,544 oC (2,811 oF) on the reinforced carbon-carbon TPS surfaces in the nose area and along the leading edges of the wings.
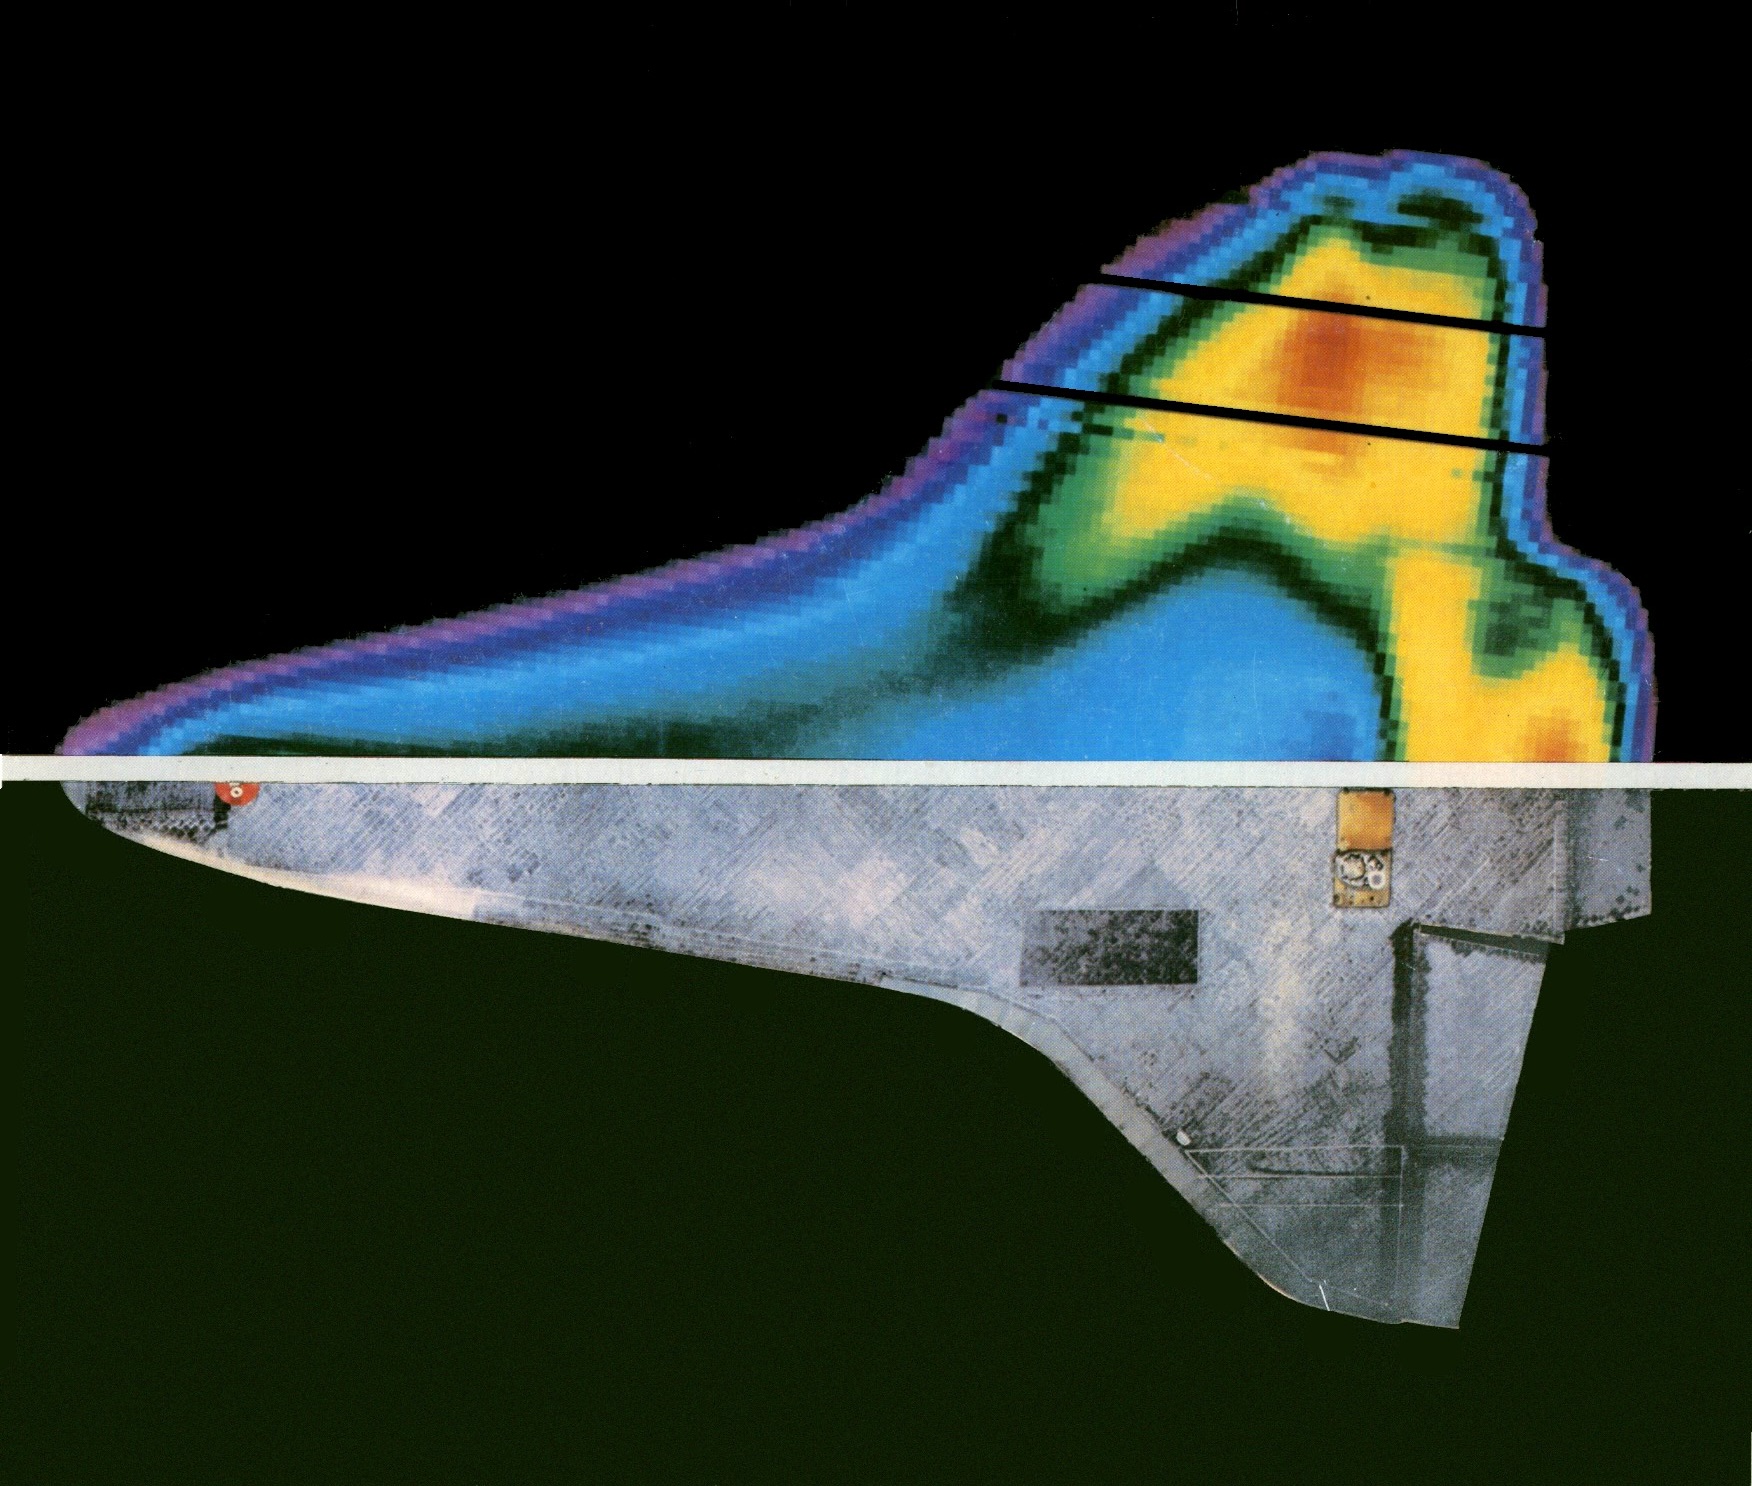
Depending on the size, shape, and mission profile of a hypersonic flight vehicle, several TPS strategies may be employed:
- Insulating tiles and blankets, such as those used on the Space Shuttle, provide reusable protection for areas with lower heating. These materials rely on low thermal conductivity and bulk insulation rather than surface ablation.
- Ablative coatings, such as phenolic-impregnated carbon or silicone-based materials, are used in short-duration, high-heat-flux scenarios (e.g., atmospheric reentry). These materials absorb heat through chemical decomposition and erosion, carrying energy away from the surface.
- Refractory composites, including carbon-carbon and carbon-silicon carbide composites, are often used for leading edges and nosecones. These materials retain mechanical integrity at extremely high temperatures and suit repeated heating cycles.
- Actively cooled structures, though more complex, may be necessary for sustained hypersonic cruise vehicles. These involve circulating coolants through internal channels to remove heat from critical components.
High-Temperature Gas Behavior
As hypersonic conditions are approached, air initially behaves as a compressible but still ideal gas. In this regime, many classical thermodynamic tools remain applicable. However, at post-shock temperatures exceeding approximately 2,000 K, the gas exhibits high-temperature, so-called “real gas” behavior because of the activation of internal molecular energy modes and chemical transformations, as illustrated in Figure 11.
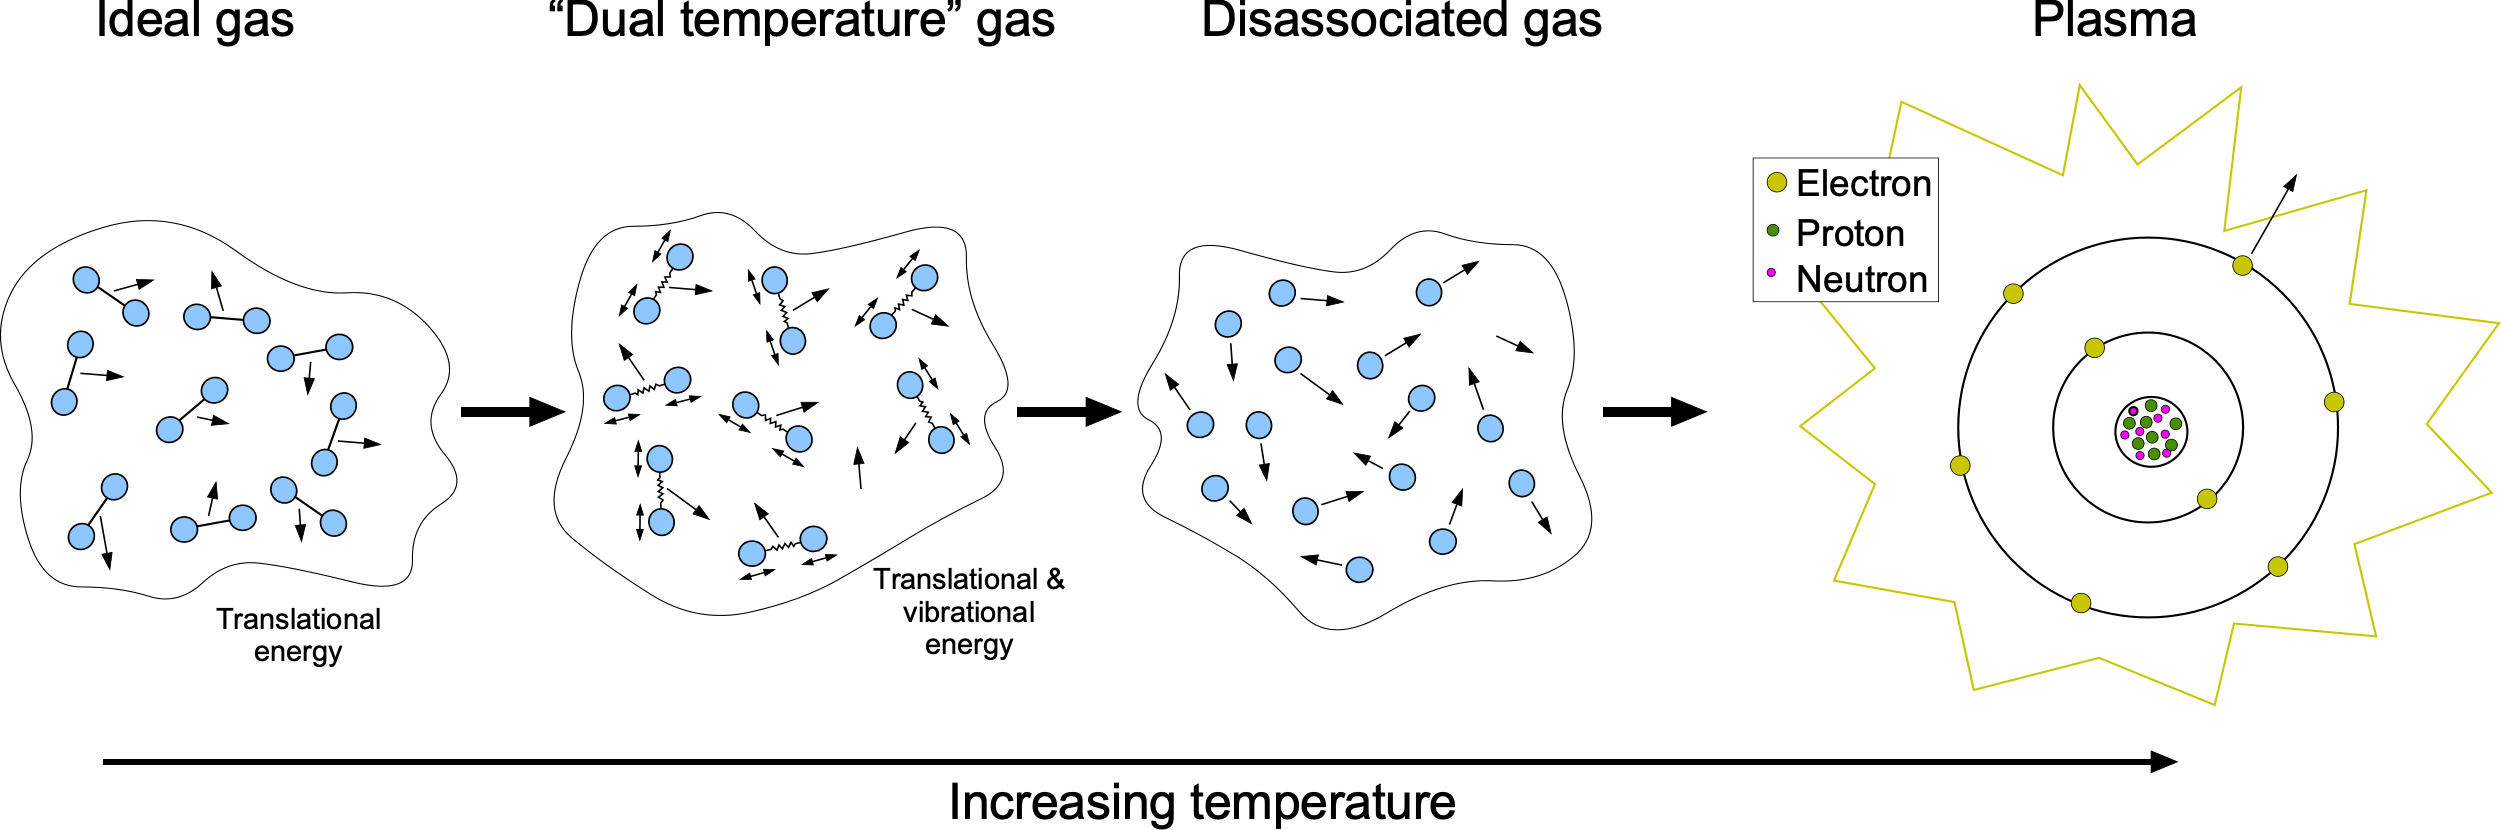
This transition unfolds in stages, each corresponding to increasing levels of kinetic energy in the flow:
- Ideal gas: At thermal equilibrium, the equipartition theorem assigns an average energy of
 per mole to each active quadratic degree of freedom, where
 is the universal gas constant. For a diatomic gas at room temperature, three translational and two rotational degrees of freedom contribute to the internal energy, while vibrational excitation is negligible.
- Vibrational Excitation: Diatomic molecules such as
 and
 store more internal energy in their vibrational modes as temperature rises. This effect is not represented by the calorically perfect-gas assumption with constant specific heats, so
 and
 become temperature-dependent.
- Dissociation: At higher temperatures, molecular bonds begin to break. Oxygen generally undergoes appreciable dissociation at lower temperatures than nitrogen. The extent of dissociation depends on temperature, pressure, and the time available for chemical reactions. This bond-breaking process consumes energy and alters the air’s thermodynamic properties.
- Ionization: With even more energy input, atoms begin to lose electrons, producing plasma, a partially ionized gas containing free electrons and ions. For instance, a typical oxygen atom with 8 protons, 8 neutrons, and 8 electrons may lose one electron, yielding a charged species.
- Radiative Heat Transfer: At sufficiently high post-shock temperatures, the shock layer can emit significant thermal radiation. Radiative heating becomes especially important during very high-speed atmospheric entry, although convective heating remains dominant for many hypersonic flight conditions. This regime marks the most severe thermal environment currently encountered in aerospace applications.
These thermochemical processes increase the gas’s internal energy storage capacity and alter its specific heat capacities ( and  ), which become temperature-dependent. Consequently, the calorically perfect-gas assumption breaks down. The ideal-gas equation of state can still describe a dilute reacting mixture, provided that changes in composition and the mixture gas constant are included. In some cases, chemical equilibrium can be assumed; in others, nonequilibrium models are required, especially near shock layers and within high-temperature boundary layers where finite-rate chemistry is significant. Therefore, understanding these real-gas effects is critical for predicting heat-transfer rates, boundary-layer behavior, and surface-pressure distributions. They become crucial in atmospheric reentry systems where post-shock temperatures generally exceed several thousand Kelvin.
Rarefied-Gas & Continuum Effects
Hypersonic vehicles often operate at very high altitudes, where atmospheric density is low, and the average distance a molecule travels between collisions may no longer be negligible. This distance is called the mean free path,  . The importance of molecular-scale effects is measured by the Knudsen number, defined as
(17) 
where is a characteristic dimension of the vehicle or flow field. Rarefied-gas effects depend primarily on atmospheric density, molecular mean free path, and vehicle size, rather than Mach number alone. Therefore, a hypersonic vehicle may experience continuum flow at lower altitudes and rarefied flow at higher altitudes during the same trajectory, requiring different physical models over different portions of the flight.
When  is very small, molecular collisions occur frequently compared with the characteristic length scale, and the gas can be treated as a continuous medium. In this continuum regime, the Navier-Stokes equations with conventional no-slip and thermal boundary conditions are appropriate. However, as altitude increases and the mean free path grows, the continuum assumption begins to break down.
The principal flow regimes are commonly classified approximately as follows:
- For
 , the flow is generally considered a continuum.
- For
 , the flow is in the slip regime, where finite-velocity slip and a temperature jump may occur at the surface.
- For
 , the flow is transitional, and continuum equations may no longer provide reliable predictions.
- For
 , the flow approaches the free-molecular regime, where intermolecular collisions are relatively infrequent compared with molecule-surface interactions.
In the slip and transitional regimes, the gas velocity at the wall may differ from the wall velocity, and the gas temperature immediately adjacent to the surface may differ from the wall temperature. These effects alter the aerodynamic forces and heat-transfer rates and cannot be represented accurately using conventional no-slip continuum boundary conditions.
When continuum methods are no longer valid, molecular simulation techniques are required. One widely used approach is the Direct Simulation Monte Carlo method, or DSMC, in which representative particles are tracked statistically as they move, collide, and interact with the vehicle surface. DSMC is particularly useful for modeling atmospheric entry at very high altitudes, where the flow transitions from free molecular to continuum behavior as the vehicle descends.
Hypersonic “Newtonian” Theory
As with all aspects of flight vehicle design, the ability to quantitatively predict aerodynamic forces, and for the right physical reasons, is fundamental. To this end, a relatively parsimonious but validated method must often be used, providing the necessary focus to establish initial designs from which more detailed analysis can follow. A widely used approximation in hypersonic aerodynamics is Newtonian impact theory. Although it does not account for boundary layer effects, viscous heating, or “real gas” (high-temperature) behavior, it can effectively estimate surface pressures based on local flow deflection. The core idea is geometric and kinematic, i.e., the freestream flow is treated as a stream of particles that transfer momentum normal to the surface upon impact. This leads to a pressure distribution that depends only on the local surface inclination angle relative to the freestream.
Isaac Newton was unaware of shock waves, supersonic flow, or hypersonic flow. Still, in his 1687 Principia, he hypothesized several simple hydrodynamic principles that have been applied to hypersonic flows in recent decades. Newton proposed that fluid flow forces exerted on a surface by a uniform stream of “particles” would transfer to the plate the time rate of change of each particle’s normal component of momentum, whereas the tangential component would be conserved. He assumed the upper surface always remains in the freestream’s “shadow” and is uninfluenced by it.
Newtonian Flow on a Slender Body
Figure 12 illustrates hypersonic flow impinging on a thin body, producing a shock wave near the surface and a thin shock layer. In supersonic flow, disturbances cannot propagate upstream, so the flow approaches the wing without any streamline curvature. Indeed, the resulting flow field bears a remarkable resemblance to what Newton proposed more than three centuries ago, despite the physical differences in detail. Although the so-called Newtonian aerodynamics theory is flawed for several reasons, it remains a reasonably good model for describing the lift and drag of bodies in hypersonic flows.
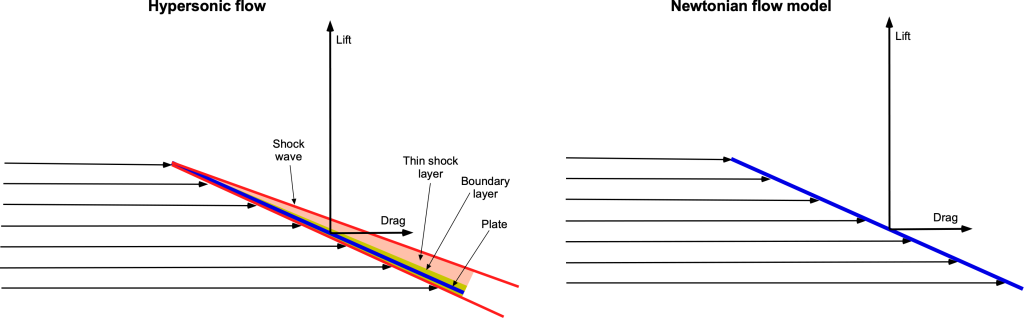
For hypersonic lift and drag estimation, Newtonian theory can be applied to flat plates, wedges, and other shapes at an angle of attack. Surface elements directly exposed to the freestream are assigned a pressure based on their local inclination, whereas surfaces in the aerodynamic shadow are typically assigned the freestream pressure. For a symmetric wedge, both forward-facing surfaces may produce compression and contribute to the aerodynamic forces, depending on the wedge angle and angle of attack. The surface pressure coefficient is given by
(18) 
where is the angle between the local surface tangent and the freestream direction. This expression represents the pressure increment above freestream pressure, i.e.,  , and approximates the pressure coefficient defined in Eq. 11 based on Newtonian impact theory.
Consider a symmetric wedge of half-angle  flying at an angle of attack
 . Newtonian theory can provide an approximate method for estimating the aerodynamic pressure distribution in hypersonic flow. The inclination angles of the upper and lower surfaces relative to the freestream are
 and
 , respectively. For
 , both surfaces face the incoming flow, and their Newtonian pressure coefficients are
(19) 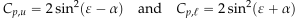
For  , the upper surface lies in the aerodynamic shadow and is assigned
 . Similarly, for
 , the lower surface is assigned
 .
These pressure forces act normal to the wedge surfaces and must be resolved into components perpendicular and parallel to the freestream. Assuming unit span and using the surface area of one side of the wedge as the reference area, the approximate lift and drag coefficients are
(20) 
and
(21) 
These expressions highlight the nonlinear dependence of aerodynamic forces on both the angle of attack and the wedge geometry. They also show that a symmetric wedge has pressure drag even at zero angle of attack. The theory is most accurate for blunt bodies and surfaces with relatively large flow-deflection angles at high Mach numbers. Its accuracy generally deteriorates for slender bodies with small surface inclinations. Despite its simplicity, the Newtonian theory remains useful for preliminary estimates of aerodynamic loads in hypersonic design.
Consider a flat plate at angle of attack , with the surface uniformly inclined at  . Applying Newtonian theory and resolving the normal pressure force into freestream-aligned components, the resulting aerodynamic coefficients are
(22) 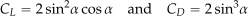
The corresponding lift-to-drag ratio is
(23) 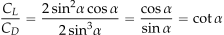
Validation
While Newtonian hypersonic theory is elementary, it can provide useful estimates of surface pressures, lift, and drag for suitable body shapes at high Mach numbers. Its validity should be judged by its assumptions and by comparison with experimental measurements, not dismissed categorically because of its simplicity. To this end, Figure 13 compares Newtonian theory with NASA wind-tunnel measurements of a hypersonic body at Mach numbers 6 and 10. Measurements are available for angles of attack of -5.5o to 35o at Mach numbers from 1.5 to 10.
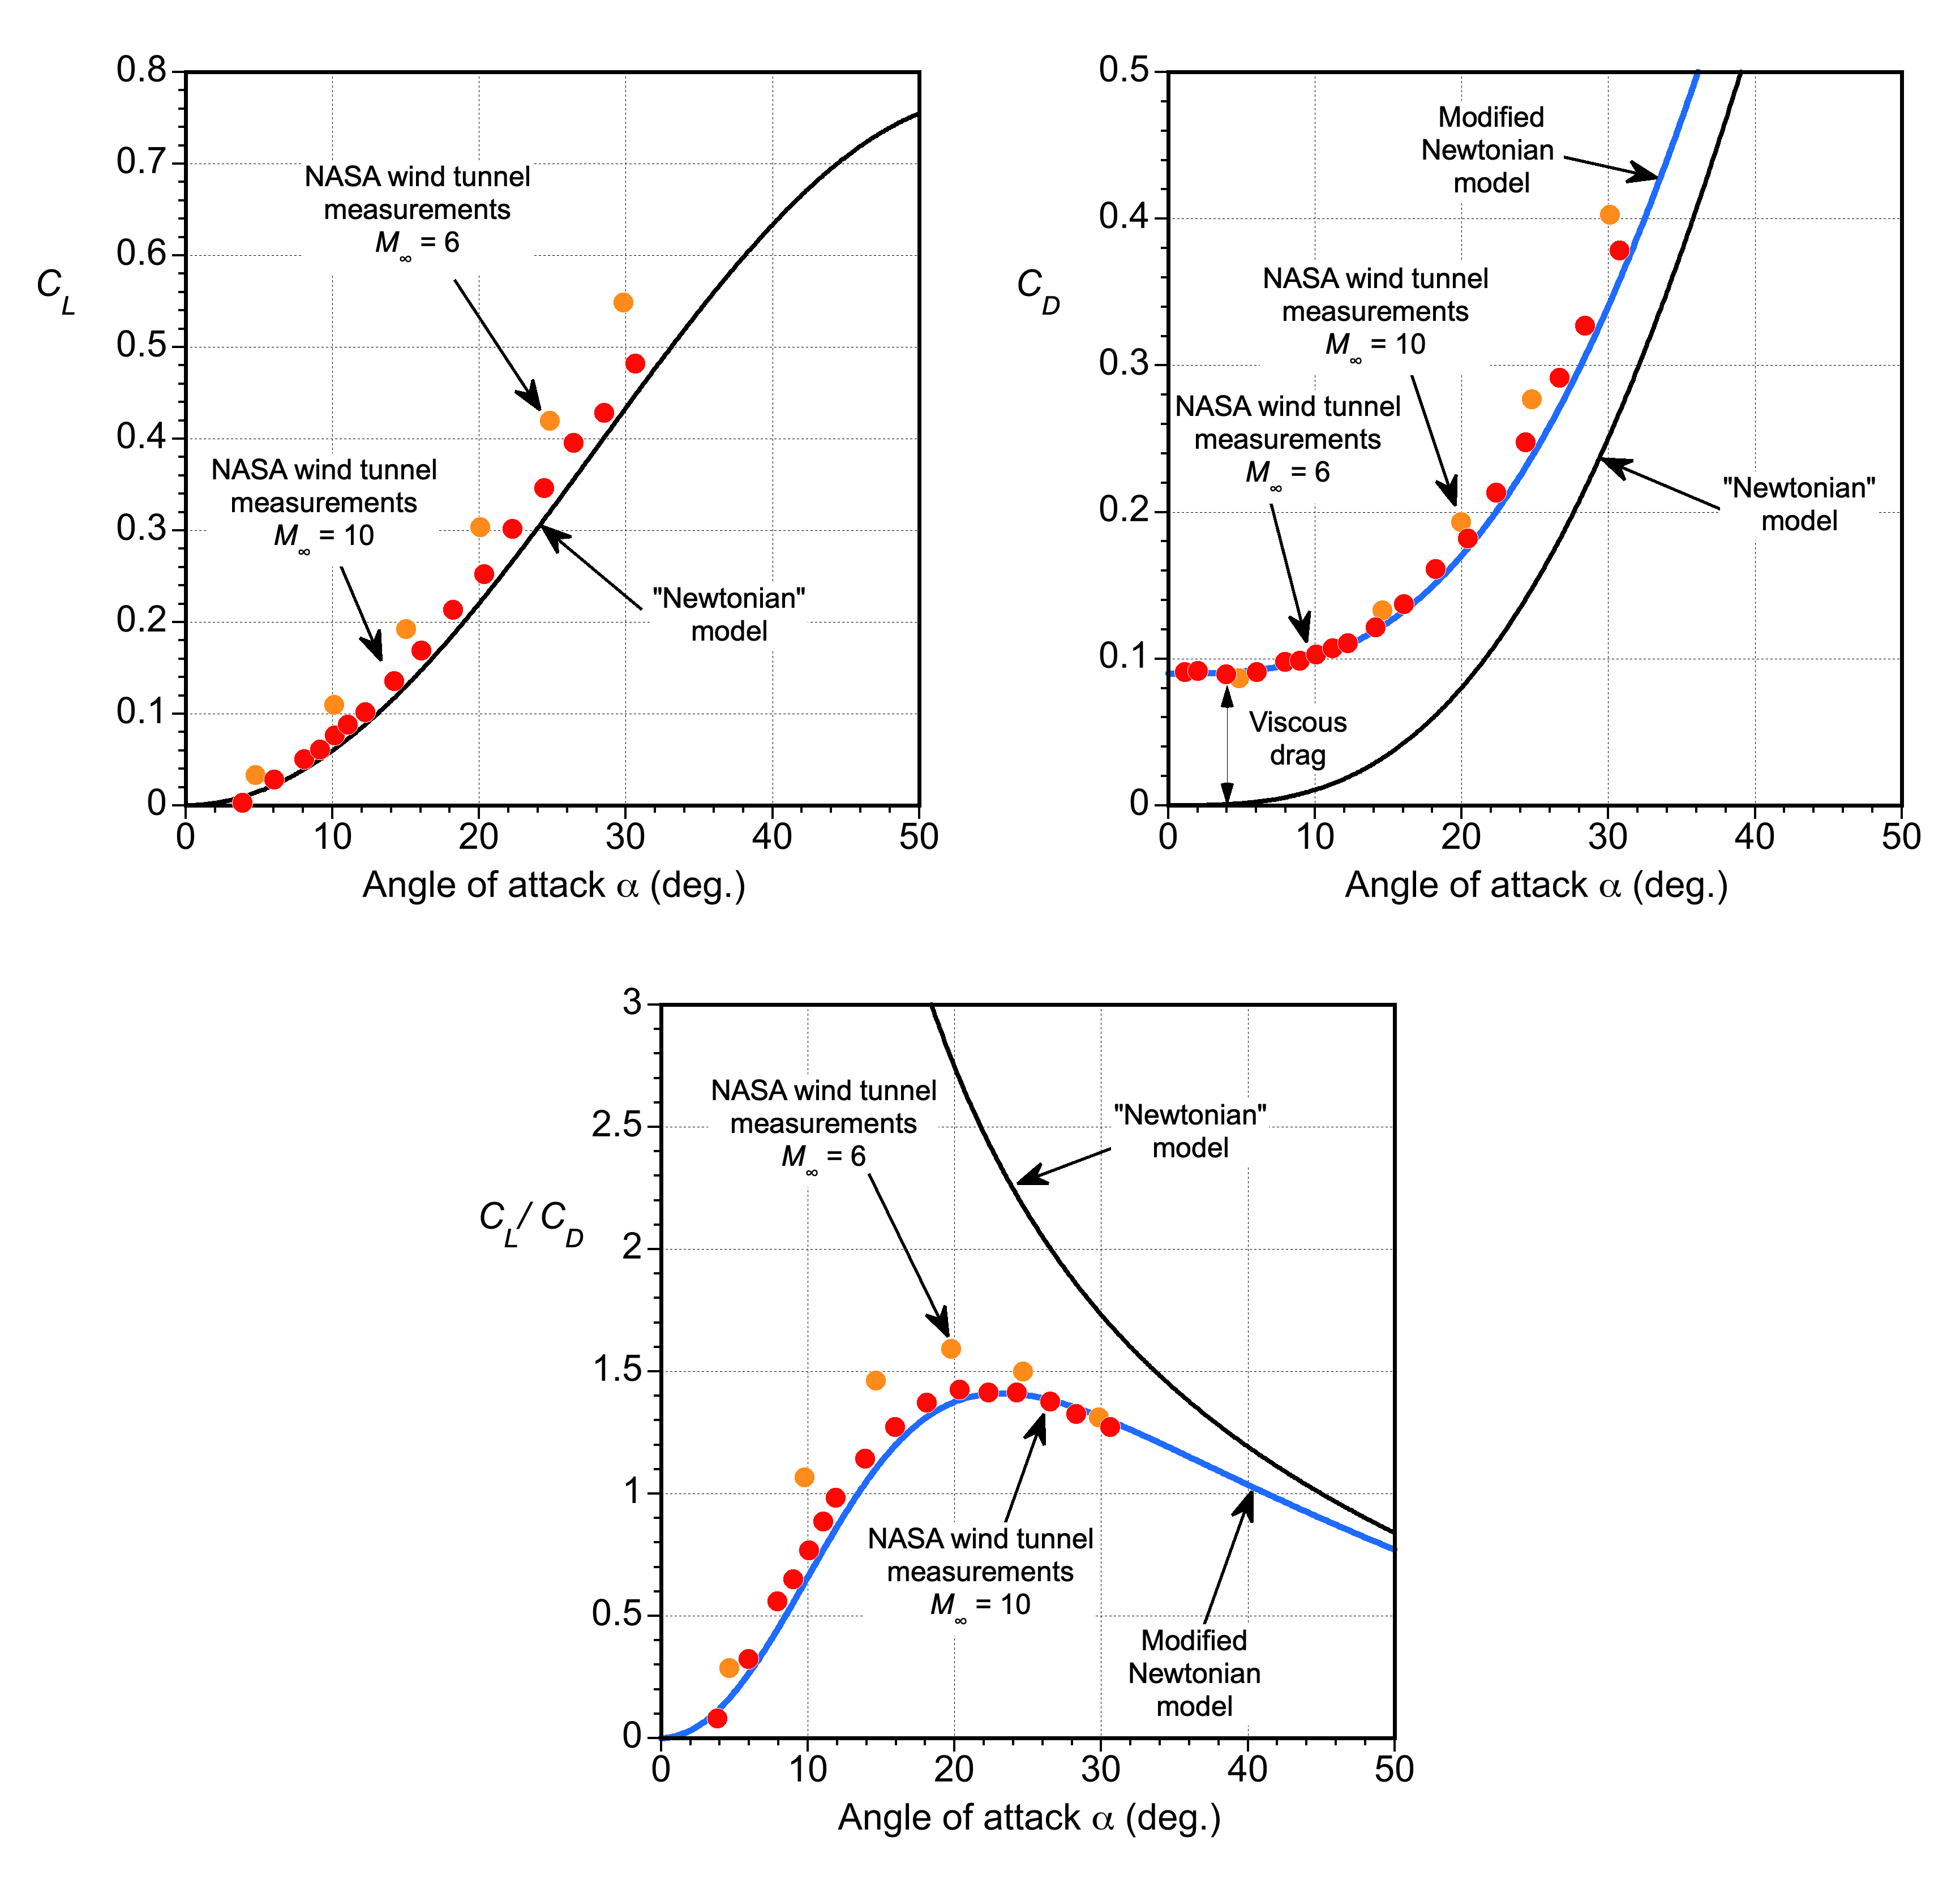
Despite its simplicity, Newtonian theory captures the main trends in the measurements shown in Figure 13. Differences in drag can reflect errors in the approximate pressure distribution, base-pressure effects, and the omission of skin-friction drag. An empirical correction to the flat-plate result can be written as
(24) 
where  represents the pressure-drag correction beyond the Newtonian estimate and
 represents skin-friction drag. All coefficients must use the same reference area. These corrections depend on the body geometry and flow conditions and should not be interpreted as universal constants.
For example, a body with a blunt base can experience additional drag because the base pressure,  , is below the freestream pressure. For a base perpendicular to the freestream, its contribution is
(25) 
where  is the base area and
 is the reference area. In the limiting approximation of zero base pressure,
(26) 
For  and
 , this gives
 only when
 . This expression estimates a base-drag contribution, not the total wave drag.
Skin-friction drag can be estimated using a mean skin-friction coefficient and the wetted area. A simple engineering approximation for a smooth, fully turbulent flat plate is
(27) 
where  is based on the plate length and freestream conditions. This empirical compressibility correction is suitable only for preliminary estimates. At hypersonic speeds, wall temperature, transition, pressure gradients, and temperature-dependent gas properties may require a more detailed boundary-layer calculation.
If the surface shear acts approximately parallel to the freestream, the corresponding drag coefficient is
(28) 
For a thin plate at small incidence, with similar mean skin-friction coefficients on both sides and the planform area used as the reference area,  , giving
 . For other geometries or larger surface inclinations, the shear forces must be resolved in the drag direction.
For the comparison shown in Figure 13, a combined correction of  provides an empirical fit to the measured drag. This value represents the combined effects omitted from the simple model and does not establish their individual contributions. Retaining the Newtonian lift estimate, the corresponding lift-to-drag ratio becomes
(29) 
The corrected model gives a finite drag coefficient at zero incidence. In contrast, the ideal Newtonian flat-plate model predicts zero lift and zero drag there, making its lift-to-drag ratio undefined at that point.
Modified Newtonian Theory
A useful refinement of Newtonian hypersonic theory is the so-called modified Newtonian theory. In many presentations of Newtonian impact theory, the pressure coefficient is written as
(30) 
where  is the angle between the local surface tangent and the freestream direction. However, for blunt bodies, it is often more convenient to define the local inclination angle with respect to the surface normal. If
 is the angle between the freestream direction and the local surface normal, then
 , and the same result can be written as
(31) 
This latter form is convenient because  at the stagnation point, where
 reaches its maximum value.
The classical Newtonian expression assumes that the maximum pressure coefficient at a stagnation point equals 2. However, in a real hypersonic flow, the stagnation-point pressure is determined by compression through the bow shock and the subsequent deceleration of the flow to rest. Therefore, the maximum pressure coefficient is not exactly 2, but depends on the freestream Mach number and the ratio of specific heats.
In the modified Newtonian theory, the same geometric dependence on surface orientation is retained, but the stagnation-point pressure coefficient (i.e., the coefficient 2) is replaced.
(32) 
where is the maximum pressure coefficient at the stagnation point. For an ideal gas, this value comes from the Rayleigh Pitot formula, which accounts for the normal shock ahead of the stagnation point and the isentropic deceleration of the post-shock flow. Therefore,
(33) 
where is the stagnation pressure behind a normal shock and is the freestream static pressure.
The practical advantage of the modified Newtonian theory is that it preserves the simplicity of Newtonian impact theory while providing a more realistic pressure scale for blunt bodies. It is especially useful for estimating the pressure distribution on the windward side of blunt-nosed hypersonic vehicles, where a detached bow shock forms ahead of the body. However, like the original Newtonian theory, it does not predict viscous shear stress, heat transfer, flow separation, or the detailed shock-layer structure. Its primary value lies in providing a rapid engineering approximation of surface pressures and integrated aerodynamic forces during the preliminary design of hypersonic vehicles.
Hypersonic Forces on General Shapes
Understanding how aerodynamic forces act on different shapes at hypersonic speeds is crucial for reentry vehicle design. To this end, analytical results can be obtained for standard shapes, thereby helping to address specific design aspects. While slender bodies, such as cones, minimize drag, they suffer from intense surface heating. In contrast, blunt shapes, such as hemispheres, experience much higher drag but provide critical thermal shielding by keeping the shock layer detached from the surface. This trade-off between aerodynamic efficiency and thermal survivability defines much of modern hypersonic design practice.
Hypersonic Cone
Consider a slender flight vehicle modeled as a cone with half-angle , moving at hypersonic speed through the atmosphere. Using Newtonian impact theory, the pressure coefficient on the cone surface is approximated as
(34) 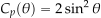
Therefore, the surface pressure increment above the freestream pressure is
(35) 
A differential ring element at axial position has radius  and surface area
(36) 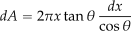
The axial, or drag, component of the pressure force is
(37) 
Substituting for  and
 gives
(38) 
or, equivalently,
(39) 
Integrating over the cone from  to
 , the total drag force is
(40) 
This result gives the Newtonian pressure drag of the conical forebody at zero angle of attack in terms of the dynamic pressure  , cone length , and cone half-angle . It excludes skin-friction drag and any additional drag caused by a base pressure below the freestream pressure.
The corresponding drag coefficient, based on the base area  , is
(41) 
Hypersonic Blunt Body
A useful comparison can be made with the drag on a blunt body, such as a hemispherical forebody, where the pressure distribution is stronger, and the shock layer is thicker from the detached bow shock. Using Newtonian impact theory, the pressure coefficient over a hemisphere varies with the local surface orientation according to
(42) 
where is measured from the stagnation point. Integrating the axial component of this pressure distribution over the hemispherical surface gives
(43) 
where  is the projected frontal area. Therefore, the Newtonian drag coefficient of a hemisphere, based on its projected frontal area, is
(44) 
To compare this result with that of the slender cone, express the cone’s drag in terms of its base radius. Because  , the cone base area is
 , and the cone drag can be written as
(45) 
Now consider the ratio of blunt-body drag to slender-cone drag, i.e.,
(46) 
The results show that the drag on a blunt hemisphere is significantly greater than that on a slender cone with the same base radius, especially for small , where  . The result quantitatively confirms the high aerodynamic drag associated with blunt reentry vehicles, which trade drag for reduced thermal loads.
Representative Drag Values in Hypersonic Flow
The table below summarizes approximate drag values for generic shapes in hypersonic flow, based on Newtonian or empirical formulations. Values are idealized and are intended for comparative purposes. The reference area must be interpreted consistently; for cones and blunt bodies, the projected frontal or base area is implied.
| Shape | Drag Coefficient,  |
Expression (if applicable) | Notes |
|---|---|---|---|
| Flat Plate (normal) | 2.0 |  |
Maximum Newtonian drag |
| Flat Plate (45o inclined) |  0.71 |
 o |
Resolved drag component |
Cone ( o) |
0.060 |
 |
Based on base area |
| Hemisphere | 1.0 |
Newtonian | Based on projected frontal area |
| Sphere | 1.1 |
Empirical | Typical high-Mach result |
Symmetric Wedge (half-angle  ) |
0.170 |
 |
Zero incidence, based on axial length times span, excluding base drag |
| Blunted Cone | 0.5–1.5 | — | Depends on bluntness ratio |
| Reentry Capsule (Apollo-type) | 1.5 |
Empirical | Highly blunt shape for thermal effectiveness |
Check Your Understanding #2 – Hypersonic flow over a slender cone
A sharp, slender cone with a half-angle of  is flying at Mach
 through the upper atmosphere. The freestream conditions are: air density = 0.0185 kg/m, static temperature = 270 K, ratio of specific heats = 1.4, and gas constant = 287 J/kg/K. The cone has a base diameter of
 = 0.5 m. Assume zero angle of attack, inviscid flow, and a base pressure equal to the freestream pressure. Use Newtonian impact theory to estimate the pressure on the conical surface. Using Newtonian theory:
- Derive an expression for the surface pressure distribution as a function of the cone angle.
- Integrate this distribution to find the total axial force (drag) in terms of , , and .
- Derive the corresponding drag coefficient
 using the base area as the reference.
- Evaluate the freestream velocity, dynamic pressure, cone length, total axial force, and drag coefficient for the given conditions.
Show solution/hide solution.
- The pressure coefficient on the surface of a slender cone using Newtonian theory is
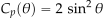
Therefore, the surface pressure increment above the freestream pressure is

- A differential ring element at axial position has radius
 and surface area
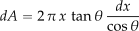
The axial component of the pressure force is

or

The total axial force is obtained by integration over the cone length, i.e.,

so that

- The reference area is the base area of the cone, i.e.,

Therefore, the drag coefficient, based on the base area of the cone, is

Substituting
gives 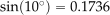 , so that

- The freestream speed of sound is

and so the freestream velocity is
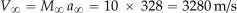
The dynamic pressure is
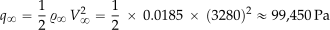
The base radius of the cone is

so the cone length is

Finally, the total drag force is

Other Methods
To obtain more accurate predictions of hypersonic flow over various bodies, researchers and engineers rely on advanced approaches, including shock-expansion theory, computational fluid dynamics (CFD), and wind tunnel testing. CFD methods account for the complexities and non-idealities of hypersonic flows, including shock-wave interactions, boundary-layer effects, chemical reactions, and high-temperature gas dynamics. When conducted properly, wind tunnel testing serves as the benchmark against which CFD and other methods can be validated.
Shock-Expansion Theory
Shock-expansion theory is another widely used method for modeling hypersonic flow. It is based on the observation that the pressure distribution on a slender body in high-speed flow can often be approximated by treating the surface as a series of compression and expansion segments. When the flow turns into the body, a shock wave forms, producing a sudden increase in pressure, temperature, and density. When the flow moves away from the body, an expansion fan forms, causing a smooth, continuous decrease in these properties.
In hypersonic flows, the analysis proceeds by treating each surface segment individually. Compression regions are analyzed using the oblique shock relations, and expansion regions are treated using the Prandtl-Meyer function. The local surface pressure can be computed by applying these relations to each surface segment. Once the pressure distribution over the body is known, the aerodynamic forces, such as lift and drag, can be obtained by integrating the pressure components over the body surface.
For compression regions, the pressure ratio across an oblique shock is given by
(47) 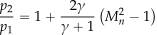
where  is the Mach number normal to the shock and is the shock angle. The pressure on the surface segment downstream of the shock is
(48) 
Here,  and
 refer to the flow immediately upstream of that shock. The substitution
 applies only when the shock encounters undisturbed freestream flow.
For expansion regions, the flow turning angle is related to the change in Mach number through the Prandtl-Meyer function  , i.e.,
(49) 
The downstream Mach number  is found by solving
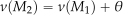 , and the pressure ratio is computed from
(50) 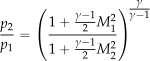
Shock-expansion theory applies particularly well to slender bodies at high Mach numbers, where the flow remains attached, and the interaction between the shock and expansion waves is weak. It is commonly applied to two-dimensional wedges and faceted airfoil sections where the flow can be treated as a sequence of planar compression and expansion regions. Conical flow requires an axisymmetric analysis, such as the Taylor-Maccoll solution, rather than direct application of the two-dimensional wedge relations. However, it does not account for viscous effects and viscous-inviscid interactions that characterize many hypersonic flows.
For example, consider a symmetric double-wedge profile with a half-angle of  at zero angle of attack in a hypersonic freestream of = 8. At the leading edge, the first surface segment deflects the flow by toward the body, producing an oblique shock. At the mid-chord corner, the surface inclination changes from
 to
 , so the flow turns away from the body through a
 expansion. At the trailing edge, the flow must turn an additional to return to the freestream direction. The steps are:
- Use shock relations for a compression turn. Compute shock angle from and
 using the –– relation (typically solved numerically or graphically).
- Use the Prandtl-Meyer function to determine the Mach number
 after the expansion at the mid-chord corner, i.e.,
(51)

- Compute the pressure ratios using
 from the shock and
 from expansion, giving
(52)

The net force on the surface can then be found by integrating the pressure distribution over the two segments. In this example, symmetry leads to zero net lift but a finite axial force (drag).
Two-Dimensional Flat-Plate Results
A flat plate at positive angle of attack provides a simple illustration of the lift and pressure drag predicted by shock-expansion theory. An attached oblique shock compresses the flow below the plate, while a Prandtl-Meyer expansion reduces the pressure above it. Under the inviscid, two-dimensional assumptions, the pressure is uniform on each side, and skin friction and boundary-layer separation are excluded. Using the plate chord times unit span as the reference area, the lift and pressure-drag coefficients are
(53) 
and
(54) 
where  and
 are the lower- and upper-surface pressure coefficients. The pressure difference acts normal to the plate, and its components give the lift and drag.
Figure 14 compares the calculated lift, pressure drag, and lift-to-drag ratio at freestream Mach numbers of 3, 5, 10, and 20 for a calorically perfect gas with , excluding high-temperature changes in gas properties. The solid curves use the oblique-shock and Prandtl-Meyer relations, with the zero-pressure limit used where the upper-surface expansion reaches its limiting turning angle. The dashed curves show the linear supersonic results given by
(55) 
where is in radians. Although this theory is based on a linearized flow solution, its pressure-drag prediction is quadratic in angle of attack because the pressure force must also be resolved in the freestream direction.

The lift and drag predictions agree closely near zero angle of attack, but the shock-expansion results increasingly exceed the linear-theory predictions as the angle of attack increases. This departure becomes more pronounced at higher Mach numbers and reflects the nonlinear pressure response to flow deflection. For example, at  and
 , shock-expansion theory gives
 and
 , compared with
 and
 from linear theory.
Despite these differences in lift and drag, the predicted lift-to-drag ratios are nearly identical. For the inviscid flat plate, dividing the force components gives
(56) 
while linear theory gives  , the small-angle approximation to
 . The pressure difference cancels from the ratio, so all four Mach-number curves coincide in Figure 14. This agreement does not imply that linear theory accurately predicts the individual forces. The ratio increases without bound as approaches zero from positive values, although it is undefined at zero incidence because both forces vanish. Including skin friction would reduce the lift-to-drag ratio, particularly at small angles of attack, and remove this unbounded increase.
Unsteady Aerodynamics
Piston theory is widely used to analyze unsteady aerodynamic loading in high-speed flows, especially where detailed solutions of the compressible flow equations are impractical.[3] Applications include predicting panel flutter on aircraft skins and missile bodies; aeroelastic modeling of slender wings and control surfaces at high Mach numbers; estimating unsteady pressures for dynamic stability analysis; and conducting preliminary design analysis for hypersonic vehicle concepts.
In supersonic and hypersonic flows, piston theory simplifies the problem by treating each surface element as a one-dimensional piston pushing into the flow, thereby generating pressure waves that propagate downstream. The approximation is valid when the Mach number is high, the flow remains attached, and the disturbances are small in amplitude.
Consider a thin surface immersed in a uniform supersonic flow of freestream Mach number , pressure , density , and sound speed  . Let
 denote the normal displacement of the surface at location and time
 , so that
 is the local normal velocity. For a surface whose local normal velocity relative to the flow is
 , the first-order piston-theory approximation is
(57) 
For a surface described by in a freestream of velocity  , the local normal velocity is approximately
(58) 
so that
(59) 
This expression shows that the unsteady pressure perturbation is proportional to the local normal velocity of the surface. This linear approximation requires  , together with the high-Mach-number and small-surface-slope assumptions of piston theory.
To account for weak nonlinear effects, a second-order piston-theory approximation can be written in terms of the local normal velocity as
(60) 
where, for a thin surface described by ,
(61) 
This second-order form captures weak nonlinear compressibility effects associated with the local surface motion and its inclination.
For a thin surface of chord  , the aerodynamic loading is determined from the pressure difference between its two sides. For pure plunging motion, take
 as positive downward and lift as positive upward. Define
 as lower-surface pressure minus upper-surface pressure. With
 and zero surface slope, the normal velocity into the gas on the lower side is
(62) 
The pressure perturbations on the two sides have equal magnitudes and opposite signs. Therefore, the pressure difference is
(63) 
and the lift per unit span is
(64) 
The corresponding sectional lift coefficient is
(65) 
For harmonic motion,
(66) 
so that
(67) 
Introducing the reduced frequency
(68) 
gives
(69) 
While piston theory provides a practical and computationally efficient tool for supersonic and hypersonic unsteady aerodynamics, it has significant limitations. It is valid only for small-amplitude surface motions, assumes attached flow and quasi-one-dimensional wave propagation, and neglects shock waves, separation, and complex three-dimensional effects. The accuracy decreases significantly at low Mach numbers or near flow discontinuities. Despite these limitations, piston theory remains a foundational tool for modeling high-speed unsteady flows and is frequently employed in aeroelastic simulations and conceptual vehicle design.
Hypersonic Aircraft Design
A thin flat plate provides a useful idealized reference for hypersonic aerodynamic efficiency. In the inviscid Newtonian model, its lift-to-drag ratio increases as the angle of attack decreases, but its lift also approaches zero. A practical flight vehicle must generate sufficient lift while accommodating engines, fuel, systems, and payload, so its design cannot be selected from the ideal flat-plate lift-to-drag ratio alone. A historical correlation used to characterize the maximum lift-to-drag ratios of conventional high-speed configurations is
(70) 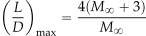
which is often referred to as Küchemann’s equation. This correlation predicts a decreasing maximum lift-to-drag ratio that approaches 4 as Mach number increases. It is a historical performance benchmark rather than a universal upper bound, and optimized waverider configurations have been predicted to exceed it.
To improve the aerodynamic efficiency of a hypersonic flight vehicle, the forebody, propulsion system, and afterbody should be designed as an integrated configuration. Such vehicles generally benefit from a small frontal area and a streamlined overall shape to reduce wave drag, while minimizing wetted area helps reduce skin-friction drag. A short-span, low-aspect-ratio wing may be combined with a fuselage shaped to generate lift (i.e., a lifting body). However, keeping the wing leading edge behind the freestream Mach cone requires extremely large sweep angles at hypersonic speeds. The propulsion system should integrate well with the vehicle’s overall shape to exploit beneficial flow interactions and avoid adverse shock interactions. These aerodynamic objectives must also be balanced against aerodynamic heating, structural requirements, and internal volume.
Waveriders
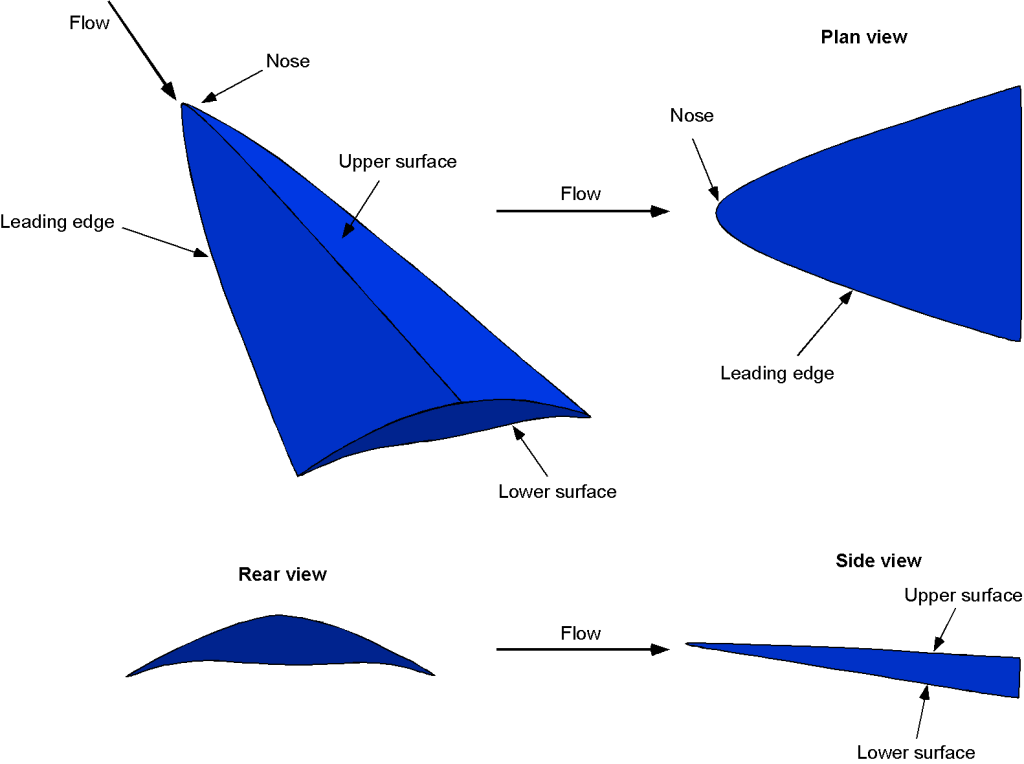
A waverider is another type of hypersonic wing design with a higher lift-to-drag ratio than other shapes. This goal is achieved by shaping the vehicle so that, at its design condition, the shock attaches along the leading edge and limits the lateral escape of high-pressure flow beneath the vehicle. The resulting pressure contributes to lift, a phenomenon known as compression lift. The waverider concept originated from Terence Nonweiler’s work on winged atmospheric re-entry vehicles in the 1950s. Some early waverider configurations used delta or caret-wing planforms with anhedral. With the advent of computational fluid dynamics (CFD) and advanced hypersonic prediction methods, various optimized waverider shapes have been developed, as shown in Figure 15. However, heat dissipation is challenging in these optimized designs because the shock waves are close to the surfaces.
Propulsion Issues
Achieving hypersonic combustion and propulsion is another major challenge, and the most likely candidate is a ramjet variant called a scramjet (supersonic combustion ramjet). As shown in the schematic in Figure 16, a scramjet operates on the principle that shock waves generated by the vehicle decelerate and compress the air, supporting combustion without reducing the airflow to subsonic speeds. This contrasts with a conventional ramjet, in which the incoming air is decelerated to subsonic speed before combustion. In a scramjet, the flow remains supersonic through the combustor, thereby avoiding the large total-pressure losses that would result from decelerating a hypersonic inlet flow to subsonic speed before combustion.
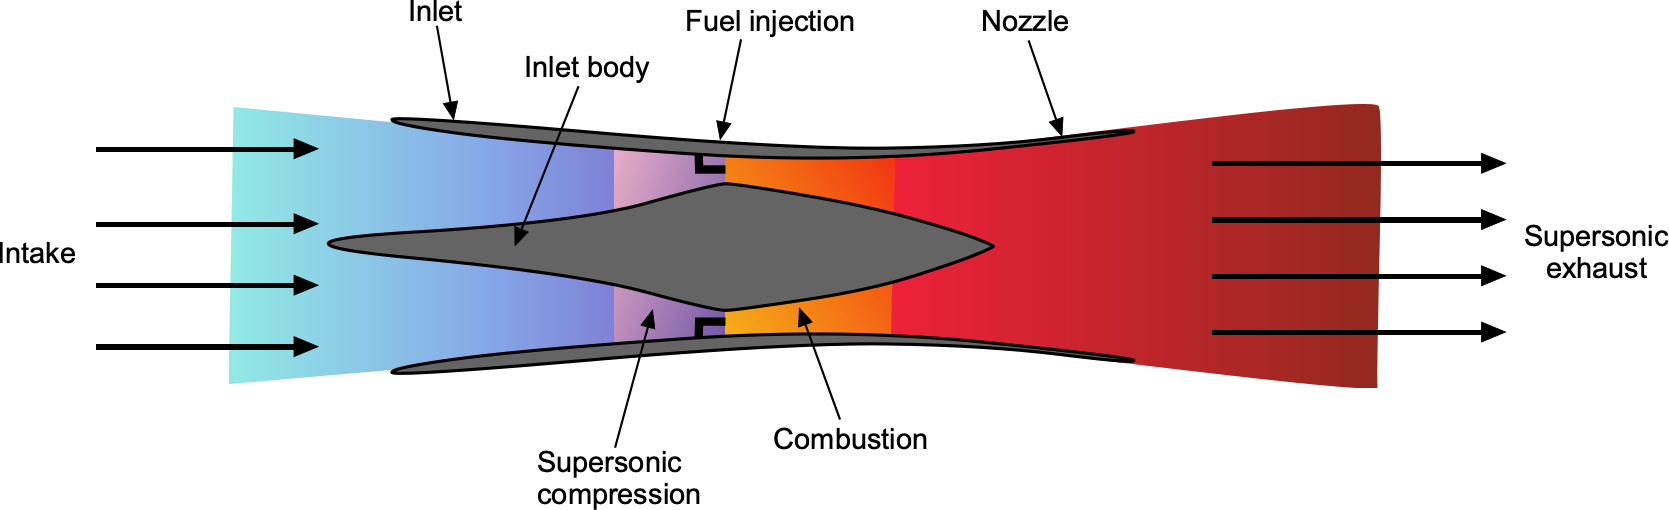
Scramjets can provide efficient, sustained propulsion in the Mach 5–10 regime. Their ability to use atmospheric oxygen to burn onboard fuel, without carrying an oxidizer, makes them attractive for sustained high-speed flight and the atmospheric portion of access-to-space missions. However, their dependence on high-speed entry, narrow operating envelope, and sensitivity to combustion stability and thermal limits remain open areas of research and development.
Combustion Process
The scramjet operates on the Brayton cycle and relies on the vehicle’s forward motion to compress the incoming flow through a system of oblique and bow shocks. These shocks raise the air temperature and pressure to levels sufficient for combustion, even though the air remains supersonic within the engine. As a result, a scramjet cannot start or operate at low airspeeds; it requires supersonic incoming air to ignite and sustain combustion. While it may operate inefficiently at lower Mach numbers, a scramjet typically requires another propulsion system, such as a rocket, turbojet, or ramjet, to accelerate to near Mach 4 speeds.
Maintaining continuous combustion in supersonic flow is very challenging. The fuel-air mixture has an extremely short residence time in the combustor, typically just a few milliseconds, before it exits the engine. This short time makes efficient mixing and complete combustion difficult. A rough estimate of the available combustion time is given by
(71) 
where is the length of the combustion chamber and  is the flow velocity, which remains supersonic. Shock waves within the engine and complex shock-boundary-layer interactions further complicate the challenge, as they can cause flow separation or instability and disrupt combustion. In addition, the high-speed flow produces severe aerodynamic heating, necessitating high-temperature materials and, in some cases, active cooling to manage thermal loads on engine components.
Thrust Production
Momentum and pressure differences between the inlet and exhaust determine the thrust,  , produced by a scramjet. A simplified thrust expression based on a control volume momentum balance is
(72) 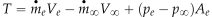
where  is the incoming air mass flow rate,
 is the exhaust mass flow rate,
 is the freestream velocity,
 is the exhaust velocity,
 and are the exhaust and ambient pressures, and
 is the nozzle exit area. The fuel mass flow rate is denoted
 , so the total exhaust mass flow rate is
(73) 
In the ideal case of perfect expansion, the exit static pressure matches the ambient pressure ( ), eliminating the pressure thrust term and reducing the thrust equation to
(74) 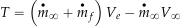
This form indicates that thrust arises from the net increase in streamwise momentum across the engine, with the added fuel mass contributing to the exhaust mass flow. Although small compared to the air mass, the added fuel mass carries significant chemical energy, allowing the exhaust velocity to exceed the freestream velocity . For good engine performance, the nozzle should be designed so that the exit pressure is reasonably matched to the ambient pressure at the principal design condition. If  , the nozzle is underexpanded or overexpanded, and the pressure-thrust term remains nonzero. The resulting thrust and efficiency depend on both the exit velocity and the pressure mismatch.
Specific Impulse
Unlike a rocket, which carries its oxidizer, a scramjet pulls in atmospheric air for combustion, making it more efficient in terms of specific impulse at high speeds. The specific impulse, defined as thrust per unit weight flow rate of fuel, is given by
(75) 
where  is the standard gravitational acceleration. For a scramjet, this definition uses only the onboard fuel flow, whereas rocket specific impulse is based on the combined fuel and oxidizer flow. By obtaining oxygen from the atmosphere, a scramjet can achieve substantially higher specific impulse than a rocket under suitable flight conditions. This advantage relates to thrust per unit weight flow of onboard propellant and does not, by itself, imply higher propulsive efficiency. Scramjet operation remains limited to the atmosphere and requires suitable inlet conditions, stable combustion, and effective integration with the vehicle.
Thermodynamics
From a thermodynamic standpoint, heat addition in a scramjet combustor can be approximated using Rayleigh flow, which models one-dimensional heat addition in a constant-area duct without friction. The simplified steady-flow energy equation can be written as
(76) 
where  and
 are the stagnation enthalpies before and after heat addition, respectively, and
 is the heat addition per unit mass from fuel combustion.[4] The flow gains total enthalpy from the fuel’s chemical energy but incurs stagnation pressure losses from shock interactions, heat addition, and viscous effects.
Heat addition is constrained by both the flow dynamics and the thermal capacity of the engine. In constant-area Rayleigh flow, adding heat to a supersonic stream drives its Mach number toward unity, imposing a thermal-choking limit for the specified inlet conditions. The high-speed flow within the scramjet generates intense aerodynamic heating, particularly in the combustor and inlet regions. Surface temperatures can exceed 1,500 K, depending on Mach number, altitude, and flight duration.
Material limits strongly constrain the maximum allowable wall temperature. Allowable temperatures depend on the alloy, applied stress, exposure duration, and oxidation environment. Titanium alloys generally have lower service-temperature limits than nickel-based superalloys, so a single temperature range is not appropriate for both material classes. Advanced ceramics, ultra-high-temperature composites, and refractory metals can tolerate higher temperatures, but are often brittle, expensive, or difficult to fabricate. Techniques such as regenerative cooling, thermal barrier coatings, or ablative surfaces may be employed to prevent thermal failure.
A useful reference for convective heating is the local adiabatic wall temperature. Under a calorically perfect-gas approximation, it can be estimated as
(77)
where and are the local boundary-layer-edge temperature and Mach number, and is the recovery factor. For air, approximate values are  for laminar flow and
 for turbulent flow. Inside a combustor, the edge conditions must include the effects of combustion, compression, and expansion. Reacting flows may require an enthalpy-based treatment with variable gas properties. The actual wall temperature follows from the balance of convective and radiative heating, conduction, and cooling. Ultimately, the amount of energy that can be safely injected into the flow is limited not only by fluid-dynamic choking effects but also by the capacity of engine walls to withstand thermal loads. These material constraints tightly couple thermodynamic performance to structural survivability in scramjet engine design.
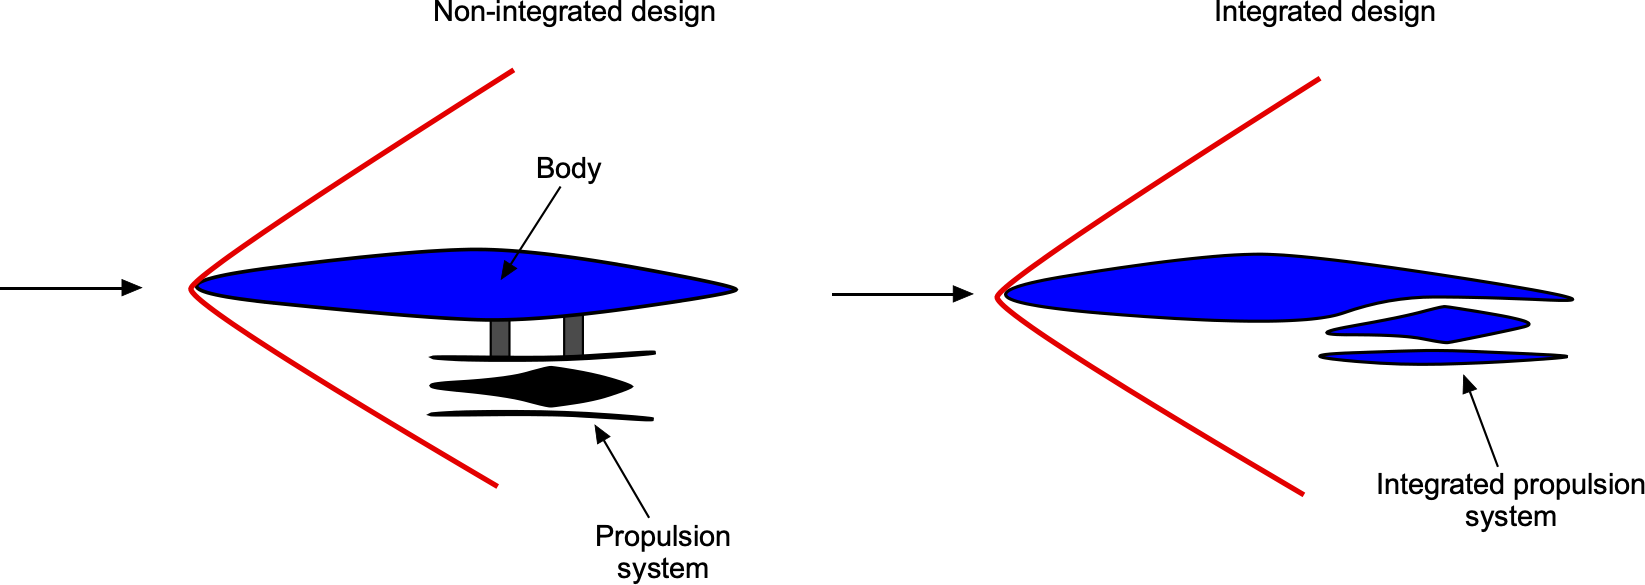
Airframe/Engine Integration
A key feature of a hypersonic aircraft is the need to carefully integrate all volume-providing components, such as payload and fuel, with propulsion components, such as an engine or a scramjet. Figure 17 illustrates the basic concept of a “two-dimensional” configuration. An externally mounted scramjet attached to the airframe (body) on a pylon would incur unacceptably high drag. However, proper integration of the body and propulsion system is expected to reduce wave drag on the body and a significant portion of external nacelle drag. The penalties for this achievement include a slight loss of useful volume and the ingestion of some boundary layers on the body surface. Studies have shown that careful aircraft and propulsion design can increase the maximum lift-to-drag ratio by approximately 1.5 times compared with a non-integrated design.
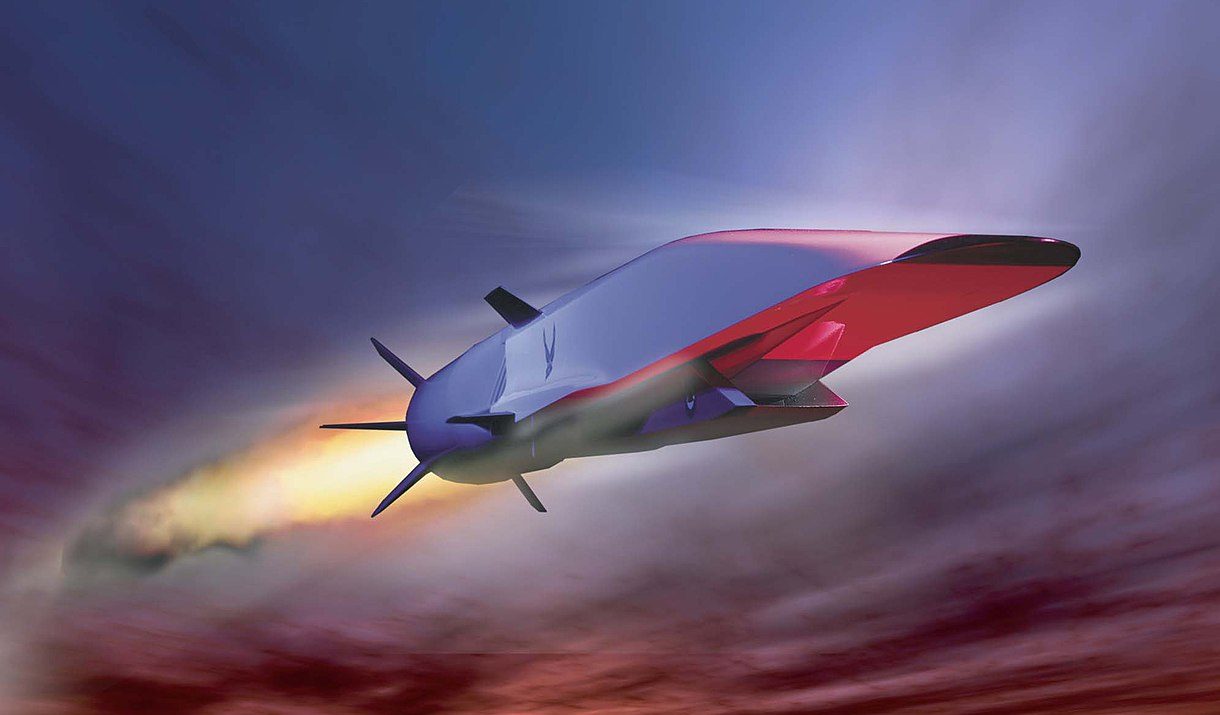
The X-51A demonstrated scramjet engine operation at hypersonic speeds and investigated other aspects of hypersonic flight. During its longest tests, the aircraft sustained Mach 5 flight for 200 seconds. Measurements obtained during these test flights have been compared with those from hypersonic wind tunnels and with predictions from computational fluid dynamics (CFD).
Sonic Booms in Hypersonic Flight
In hypersonic flight, the sonic boom is a major aerodynamic and environmental consequence. Shock waves are generated by the nose, lifting surfaces, control surfaces, propulsion system, and changes in cross-sectional area. These disturbances propagate outward and combine into a finite-amplitude pressure signature that reaches the ground as an intense boom. Because the shocks are generated continuously, sustained flight produces an extended ground footprint, often called a sonic-boom carpet.
Sonic-boom propagation is nonlinear. Higher-pressure portions of the waveform propagate slightly faster than lower-pressure portions, causing the signature to steepen into sharply defined shock fronts. The ground-level overpressure depends on vehicle geometry, length, weight, lift distribution, Mach number, altitude, trajectory, and atmospheric conditions. For a conventional far-field N-wave, the peak ground-level sonic-boom overpressure may be represented approximately by the scaling
(78) 
where  is the vehicle weight,
 is the propagation altitude, and
 is a characteristic vehicle length. This relation shows that the boom increases with vehicle weight, decreases with altitude, and decreases only slightly as the vehicle is lengthened. The direct dependence on Mach number is comparatively weak in the classical far-field N-wave regime, although Mach number still affects the shock geometry, propagation, ground footprint, and detailed pressure signature.[5]
Moderate overpressures produce intense indoor noise, vibration, rattling, and strong startle responses. Higher or locally focused overpressures can crack plaster, damage vulnerable windows, and affect other fragile structural elements. Increasing altitude reduces the nominal local overpressure but broadens the ground footprint, while atmospheric refraction can produce regions of increased pressure. Vehicle shaping can weaken individual shocks, but it cannot eliminate air displacement or the pressure field required to produce lift. A large hypersonic vehicle in sustained atmospheric flight can expose a broad ground area to sonic booms. The resulting noise and vibration could severely constrain operations over populated land, with acceptability depending on the pressure signature, exposure frequency, flight conditions, and applicable regulations.
Summary & Closure
Hypersonic flight vehicles operate in a regime where conventional aerodynamic assumptions no longer apply. At Mach numbers above 5, strong shock waves, high-temperature gas effects, and viscous-inviscid interactions dominate the flow field. The resulting kinetic heating can raise surface temperatures to thousands of degrees, imposing severe demands on materials and structural design. To withstand these conditions, hypersonic vehicles must incorporate specialized thermal protection systems and high-temperature materials, often involving ceramics, carbon-carbon composites, or ablative coatings. These constraints make thermal management central to vehicle design, tightly coupled to aerodynamic shaping and mission trajectory.
Propulsion remains one of the most challenging aspects of hypersonic flight. While scramjets (supersonic combustion ramjets) offer a promising solution for air-breathing propulsion in this regime, their operational stability, ignition, and integration with the airframe remain active research areas. One of the most promising aerodynamic configurations is the waverider, which generates lift by shaping its lower surface to retain the compressed, high-pressure flow behind the attached shock produced during flight. By effectively “riding” its own shock, the waverider minimizes wave drag while maximizing the lift-to-drag ratio, thereby improving efficiency at hypersonic speeds. The future of hypersonic flight will likely depend on continued advances in propulsion, high-temperature materials, and integrated vehicle design, culminating in systems capable of sustained, efficient, and reusable high-speed atmospheric flight.
5-Question Self-Assessment Quickquiz
For Further Thought or Discussion
- What defines hypersonic speed, and why is it different from just “very fast”?
- Why does aerodynamic heating become a significant issue at hypersonic speeds?
- What kinds of shapes work best for hypersonic vehicles, and why?
- Why can’t regular jet engines work at hypersonic speeds?
- How do shock waves form, and why are they stronger at higher Mach numbers?
- What challenges does a hypersonic vehicle face in maintaining stability in flight?
- Why do hypersonic vehicles fly high in the atmosphere?
- What kinds of materials are needed to survive the extreme heat of hypersonic flight?
- Why is ground testing of hypersonic vehicles so difficult?
- How might hypersonic vehicles be used in the future (e.g., for space, military, or travel)?
Other Useful Online Resources
For additional resources on hypersonic flight, follow up on some of these online resources:
- Hypersonic Waverider – How the USAF X-51A scramjet works – see the video here.
- Hypersonic Aerodynamics: Basic and Applied – start to watch the multi-part lecture here.
- 2025 AIAA Durand Lecture by Kevin Bowcutt – view the talk here.
- Testing and Analytical Challenges in Hypersonics – Dr. Mark Lewis – video available here.
- Hypersonic Flight Vehicle Design and Performance Analysis (AIAA short course) – see course info here.
- Hypersonic and High-Temperature Gas Dynamics by John D. Anderson – PDF available here.
- The Insane Engineering of Re-Entry – video available here.
- Entropy is a thermodynamic property that quantifies the dispersal of energy and increases when irreversible processes occur. ↵
- https://archive.org/details/nasa_techdoc_19930074866 ↵
- The classical aeroelastic formulation is generally attributed to Holt Ashley and Garabed Zartarian, “Piston Theory: A New Aerodynamic Tool for the Aeroelastician,” Journal of the Aeronautical Sciences, Vol. 23, No. 12, December 1956, pp. 1109–1118. Important earlier developments include M. J. Lighthill, “Oscillating Airfoils at High Mach Number,” Journal of the Aeronautical Sciences, Vol. 20, No. 6, 1953, pp. 402–406, and Milton D. Van Dyke, “Supersonic Flow Past Oscillating Airfoils Including Nonlinear Thickness Effects,” NACA Report 1183, 1954. ↵
- Enthalpy is a thermodynamic property defined as
 on a specific basis. It is especially useful in the energy analysis of flowing fluids. ↵
- Domenic J. Maglieri et al., “Sonic Boom,” in Aeroacoustics of Flight Vehicles: Theory and Practice, Volume 1, NASA Reference Publication 1258, 1991. ↵
